 |
Research Background
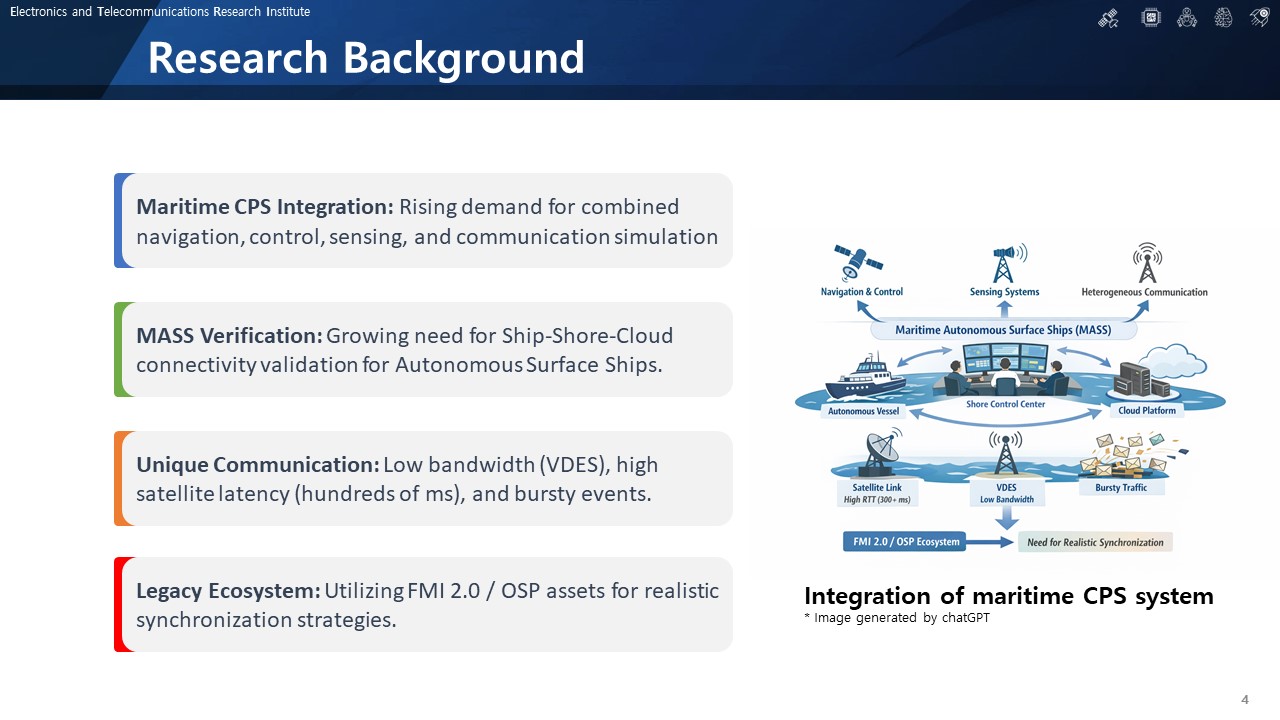
Maritime cyber–physical systems increasingly integrate navigation, control, sensing, and communication into a unified simulation environment.
In particular, with the growing interest in Maritime Autonomous Surface Ships, or MASS, there is a strong need to validate ship–shore–cloud connectivity before real deployment.
However, maritime communication environments are very unique.�They often rely on low-bandwidth systems such as VDES, experience satellite round-trip times of several hundred milliseconds, and show bursty, event-driven traffic patterns.
At the same time, most existing maritime simulation ecosystems are still based on FMI 2.0 and OSP, which motivates us to develop realistic synchronization strategies without discarding legacy assets.
|
 IEEE/ICACT20260349 Slide.04
[Big Slide]