 IEEE/ICACT20220030 Slide.05
[Big Slide]
Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20220030 Slide.05
[Big Slide]
| Oral Presentation |
|
|
|
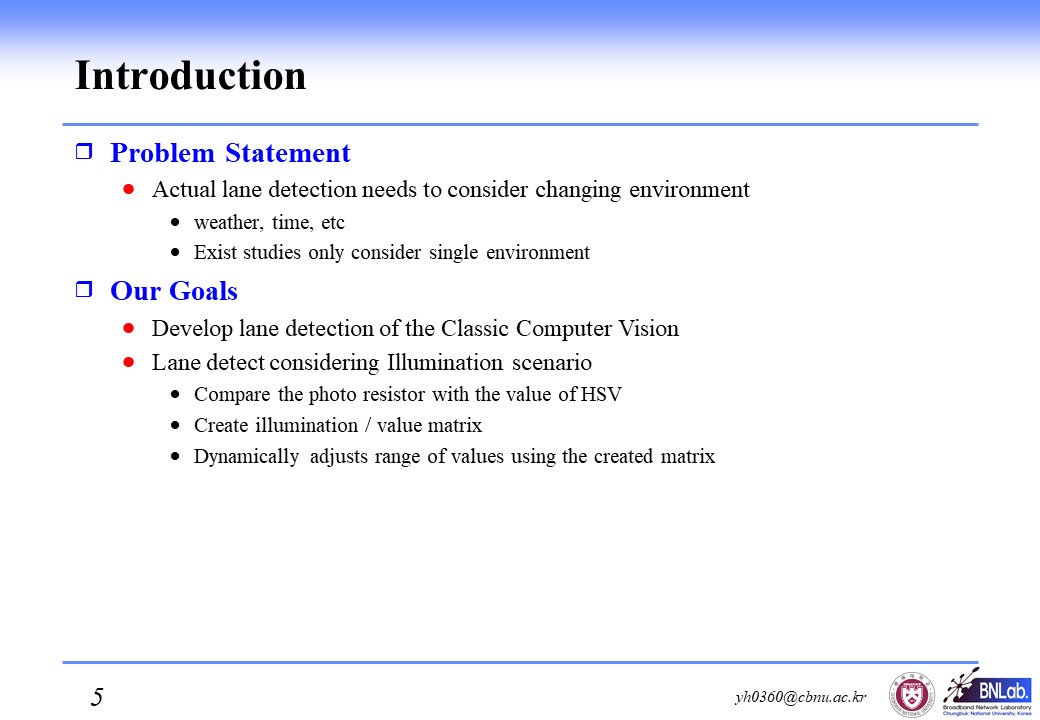
Actual lane detection needs to consider changing environment. For example, weather, time, etc. Exist studies only consider a single environment. Our goal is Lane detection concerning the Illumination scenario. To this end, line detection is developed in Classic Computer Vision. To do this, we Compare the photoresistor with the value of HSV. And we create an illumination/value matrix. We dynamically adjust a range of values using the created matrix utilize created matrix. | |
| [Go to Next Slide] |