 IEEE/ICACT20260043 Slide.06
[Big Slide]
Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20260043 Slide.06
[Big Slide]
| Oral Presentation |
|
|
|
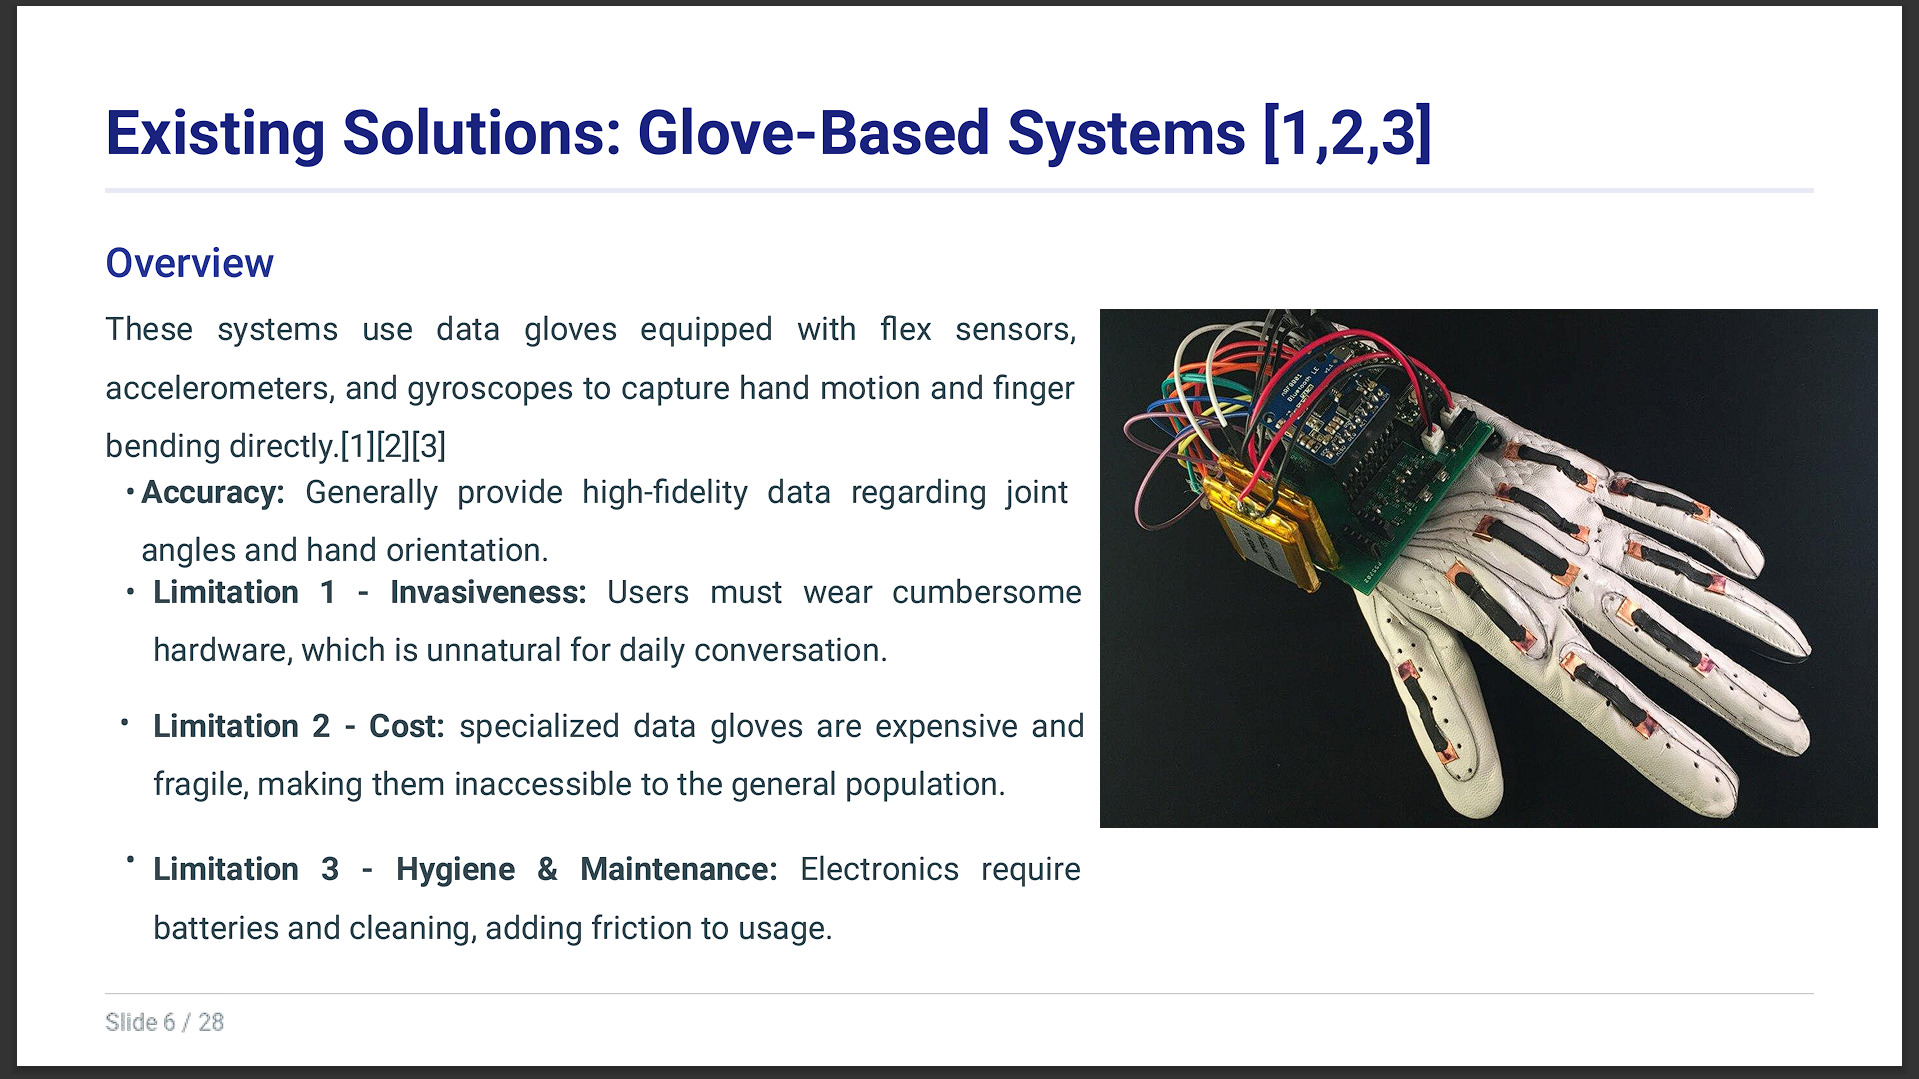
We analyzed existing solutions, starting with Glove-Based Systems. These use flex sensors and accelerometers to capture motion directly. While they offer high accuracy regarding joint angles, they have three major limitations. First, they are invasive and cumbersome to wear. Second, the hardware is expensive and fragile. And third, issues with hygiene and maintenance add friction to daily usage. | |
| [Go to Next Slide] |