 |
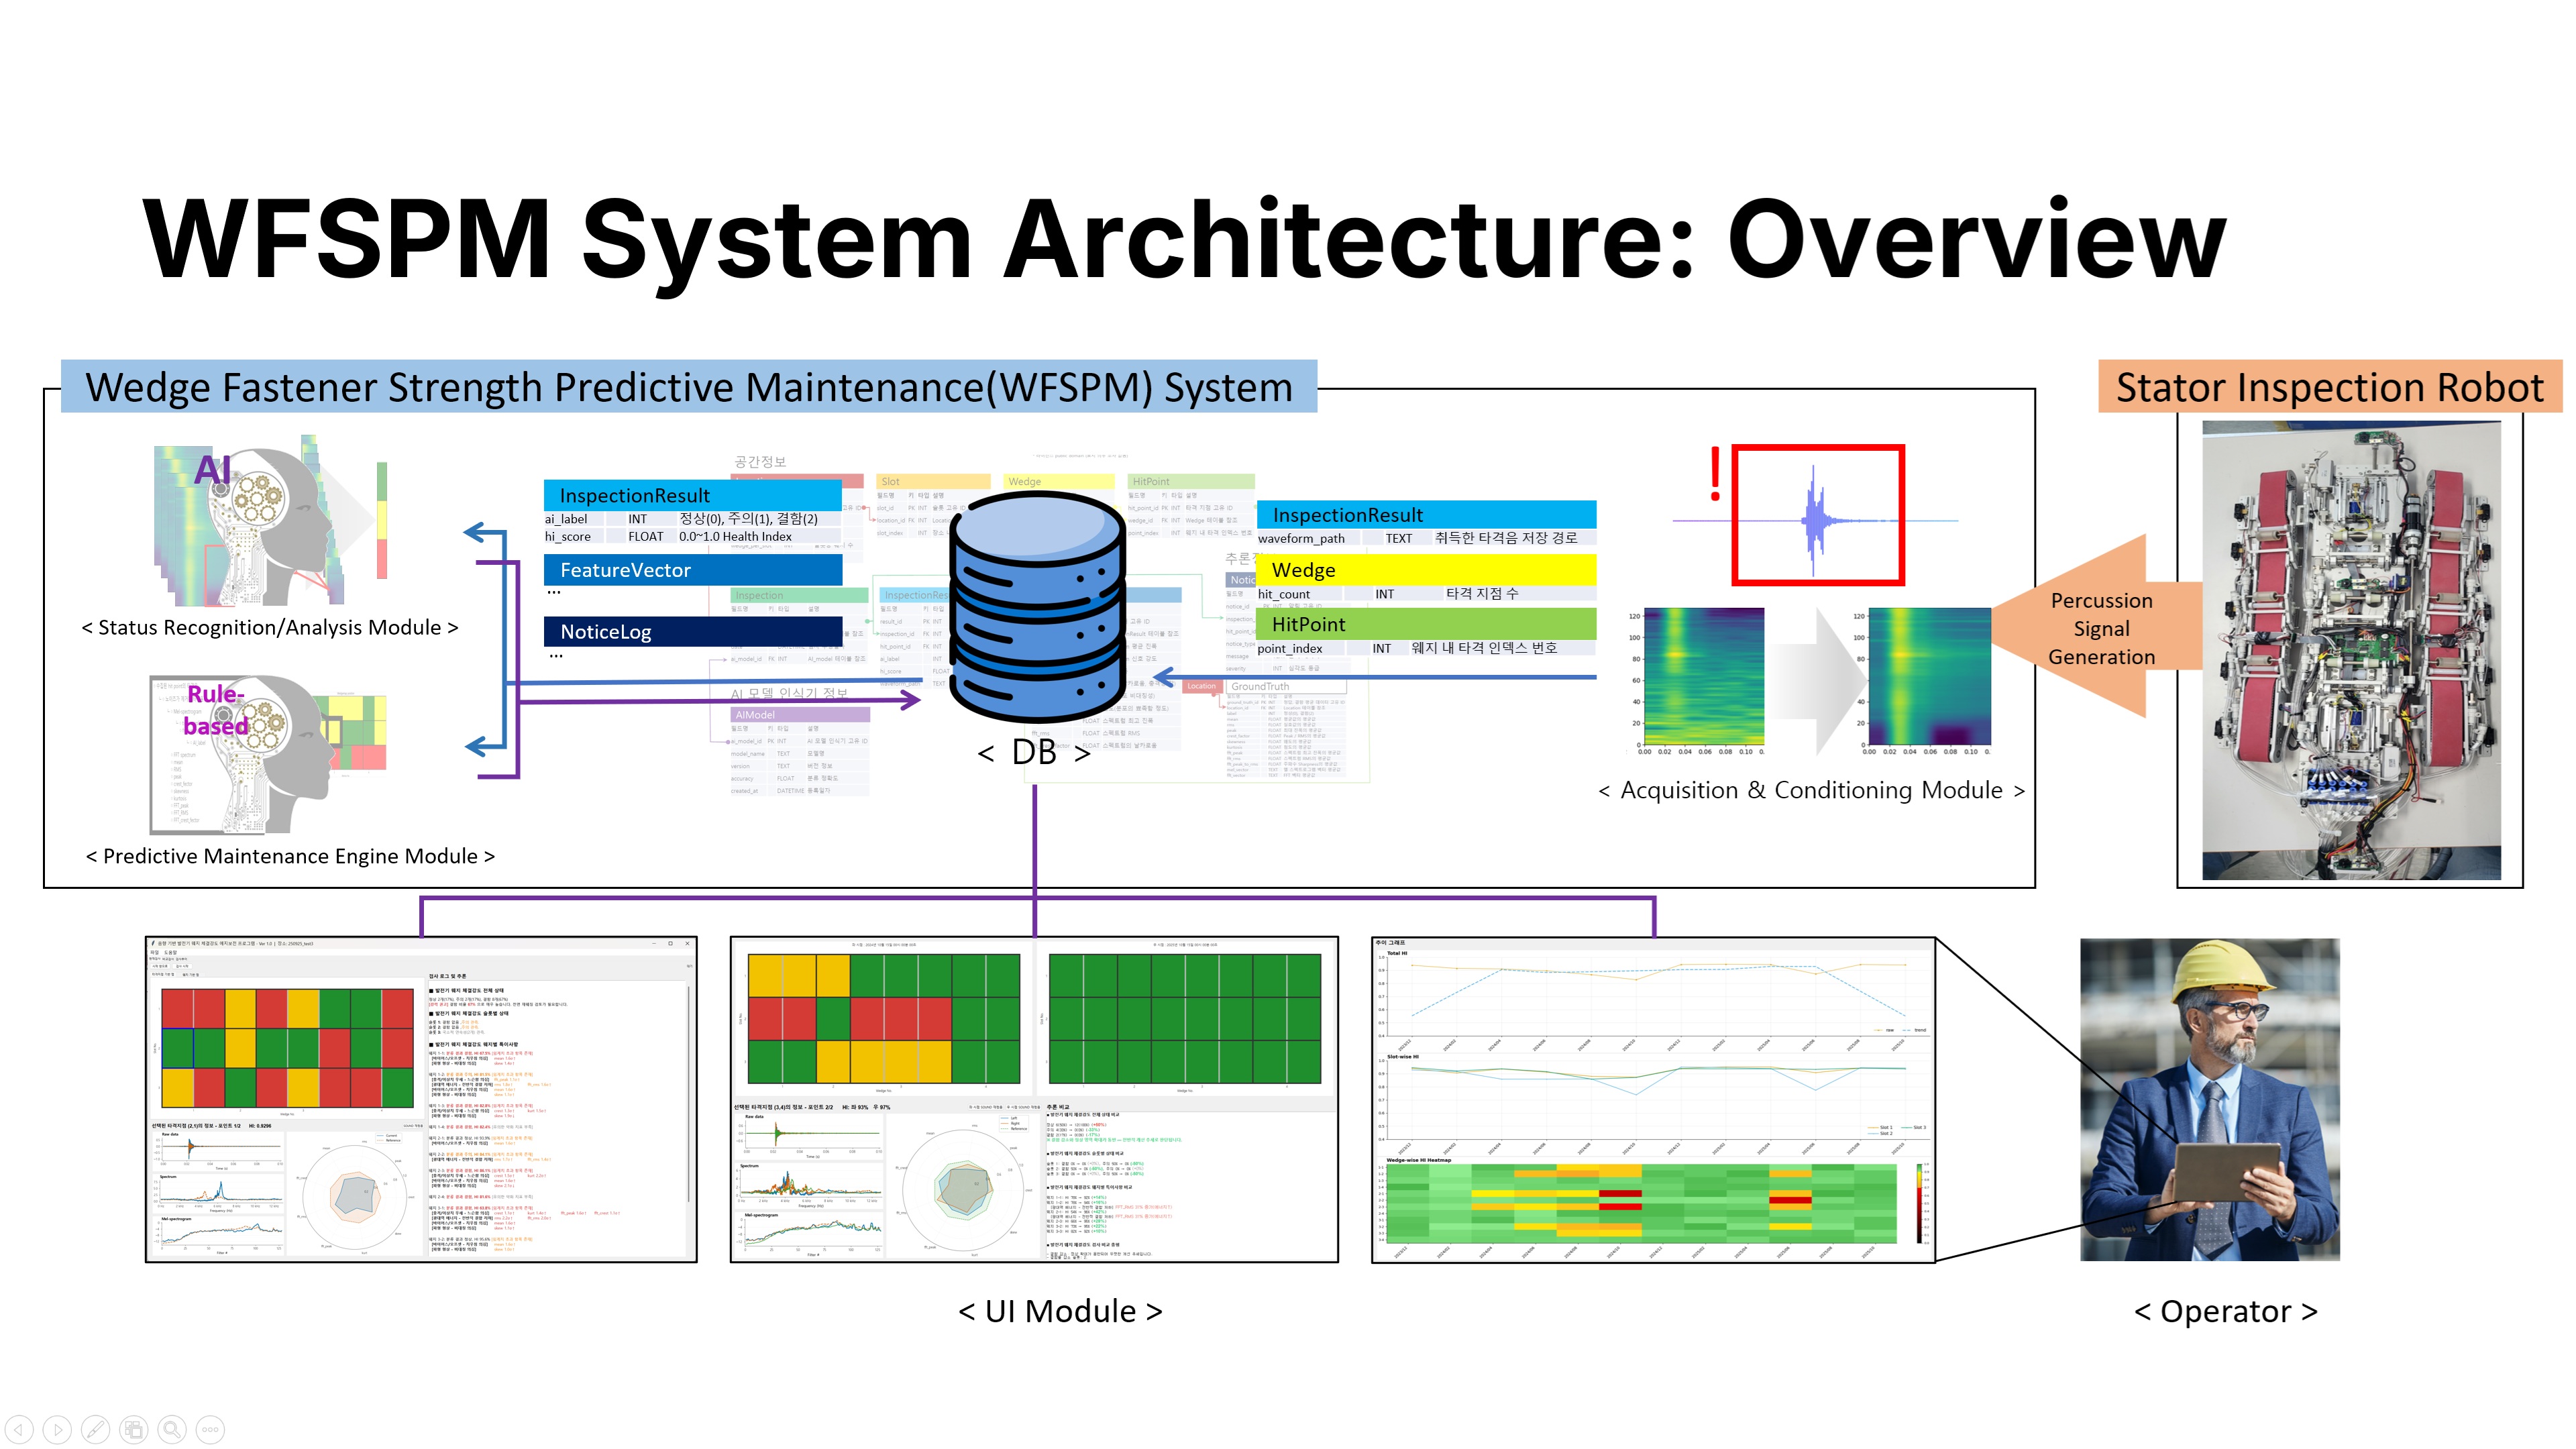
Here is the detailed overview of our proposed WFSPM system architecture. As you can see, it is not just a single algorithm, but a comprehensive, full-stack solution designed for real-world deployment. The architecture consists of several distinct, interconnected modules. On the far left, we have the Inspection Robot and the Acquisition Module, which capture the raw percussion signals. These signals are then passed to the Status Recognition and Analysis Module. This is where the core signal processing happens, extracting features and calculating the Health Index. This module doesnt just look at a single hit, but aggregates data to make a robust assessment. Next, we have the Predictive Maintenance Engine. This engine takes the analysis results, and applies our dual-threshold logic to determine the current state, whether it is Normal, Caution, or Fault. It also handles the logic for triggering re-inspections. All of this data is securely stored in our Database, which acts as the backbone for traceability. Finally, on the right, we have the UI Module and reporting tools. This seamlessly connects the physical inspection robot, to the user interface, providing real-time feedback to the operator. This entire loop, from the robots sensor to the users screen, operates autonomously, ensuring a closed-loop system for maintenance. |
 IEEE/ICACT20260214 Slide.06
[Big Slide]
[YouTube]