 |
The system design is divided into two parts: software design and hardware design for detailed description.
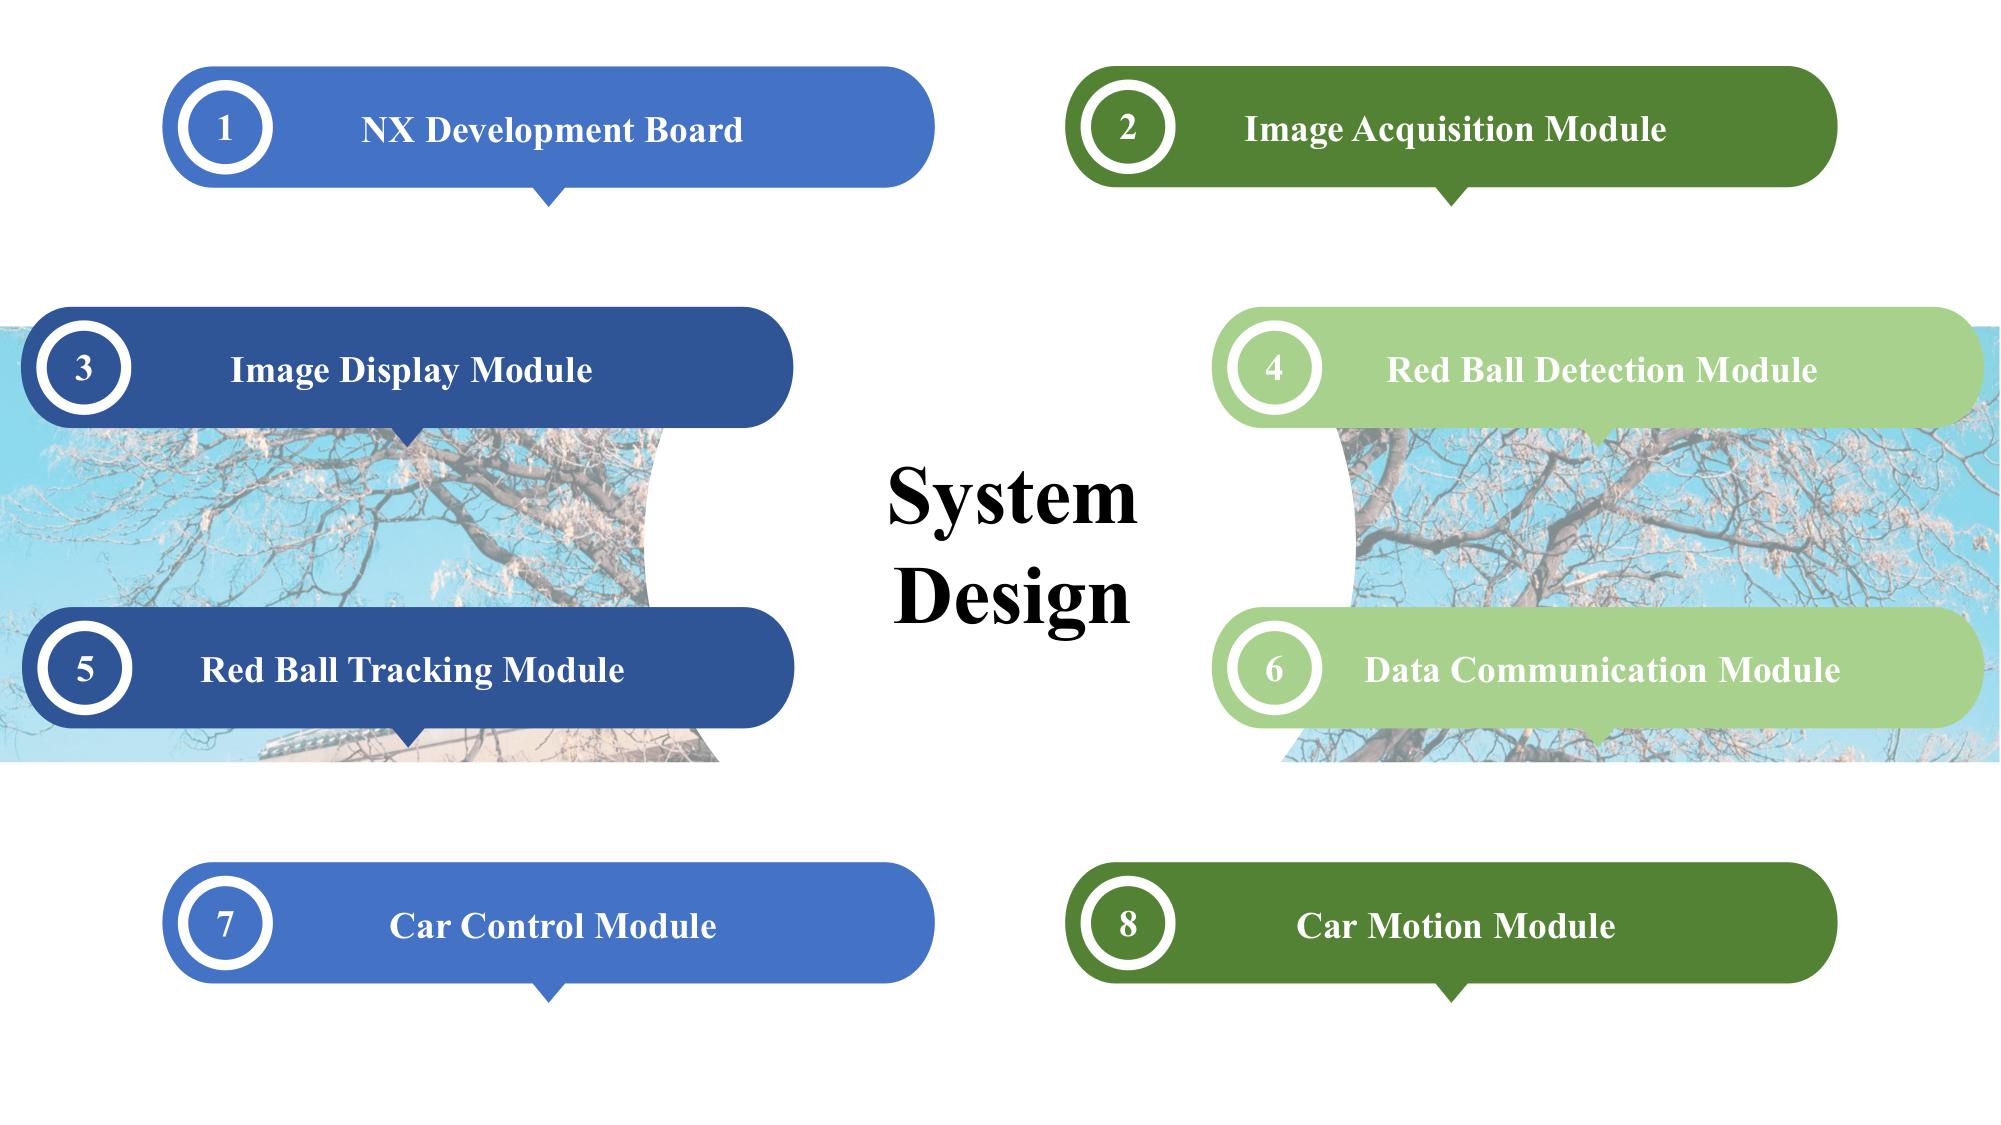
The overall design of the red ball detection and tracking system is shown in Figure 1. The red ball target detection model is trained based on the server. As shown in the figure 1, the NX development board is the core of the whole embedded terminal deployment. The image information is collected by connecting with the camera, and the detection model is ported to the NX development board after accelerating the YOLOv3-tiny model by using TensorRT, which outputs the red ball positioning and size information to the LCD after target detection. NX relies on the UART serial port to communicate with the motion module of the car to control the left/ right/ back/ forward movement of the car. The following key components constitute the entire system.
|
 IEEE/ICACT20220027 Slide.07
[Big Slide]