 |
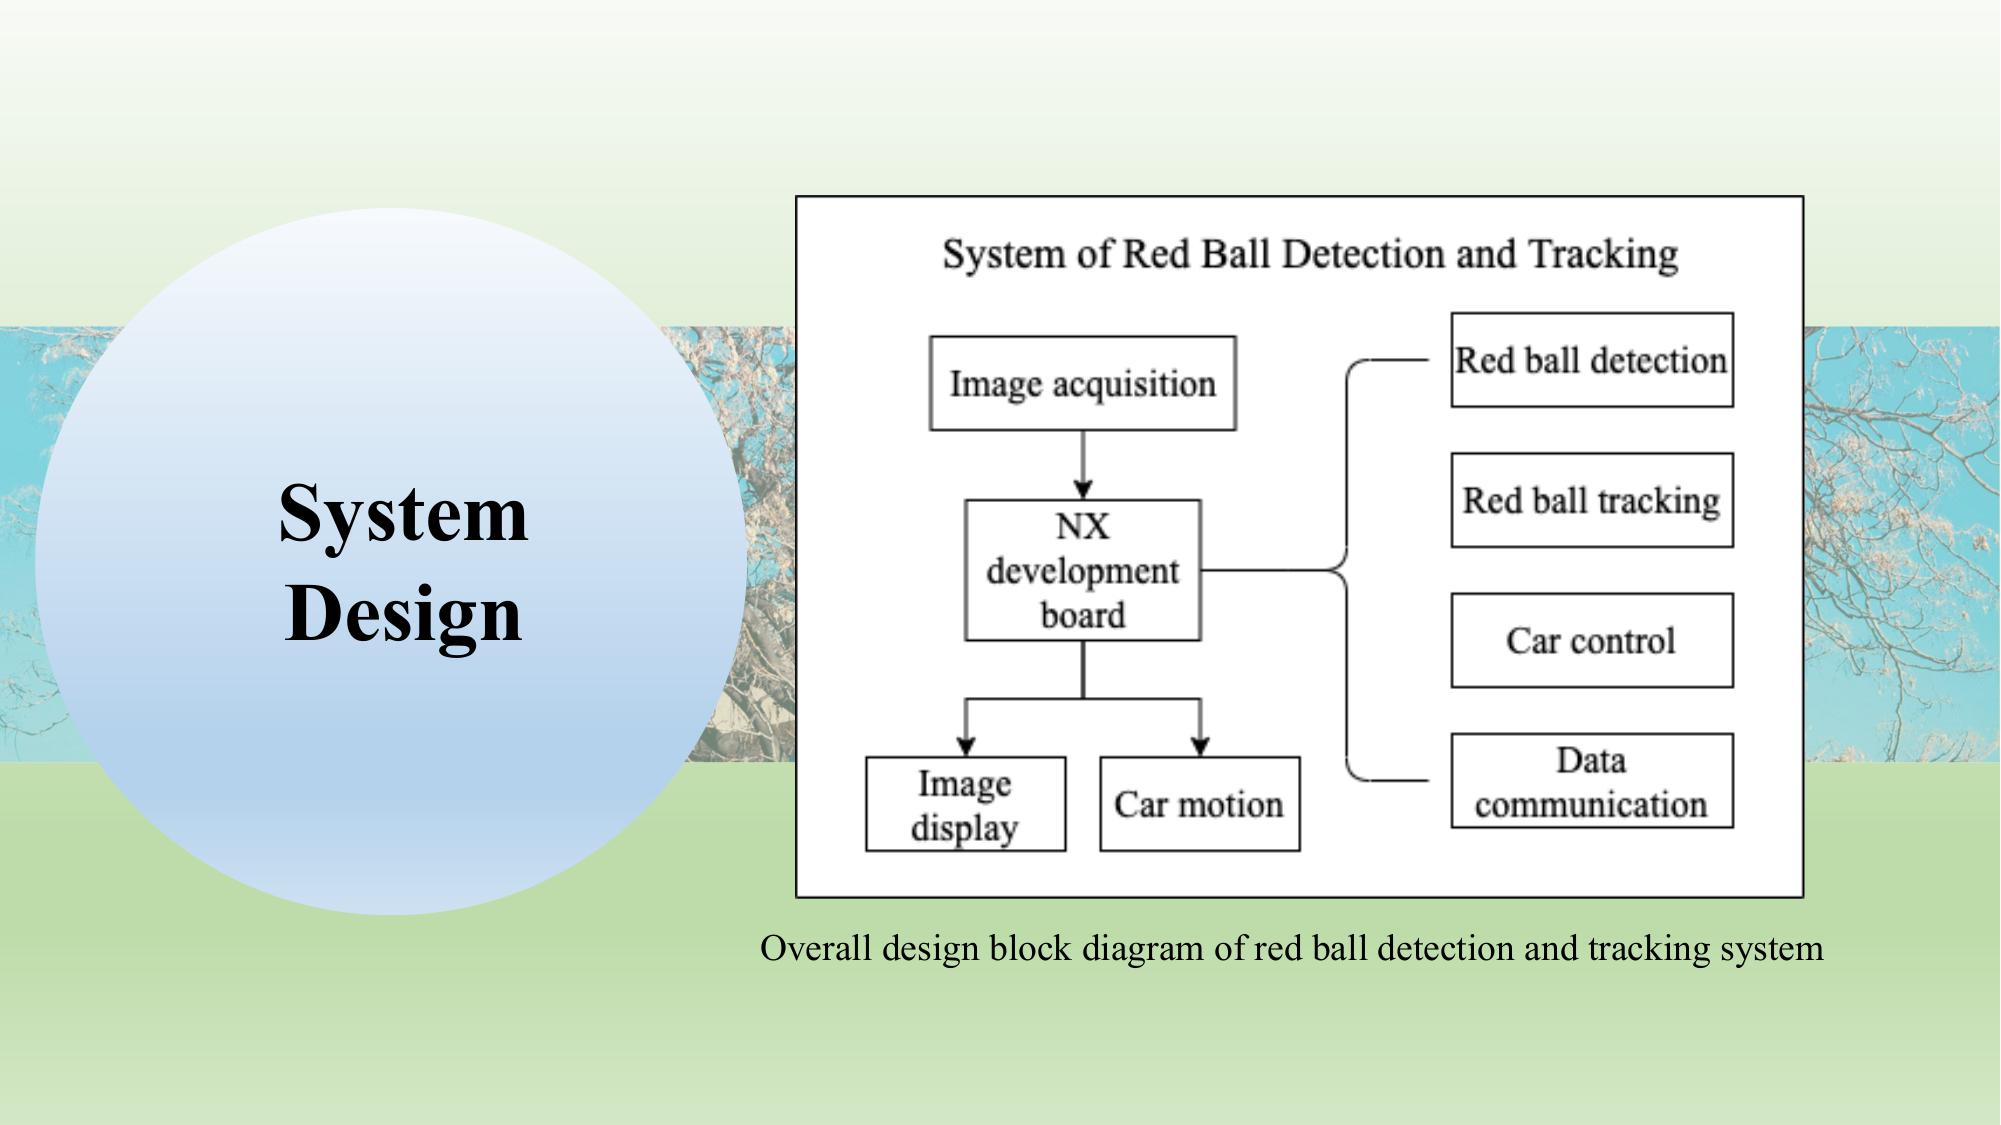
NX Development Board: NX is the core part of the entire embedded system.
Image Acquisition Module: This part transmits the acquired image information to the NX platform through the camera.
Image Display Module: The display is connected to the NX via the micro-HDMI interface, and is responsible for displaying the collected images and the red ball detection and tracking results.
Red Ball Detection Module: Target detection based on the YOLOv3-tiny model is used to locate the position and size of the red ball on the camera input video.
Red Ball Tracking Module: This module mainly implements the function of tracking of the red ball position in real time.
Data Communication Module: NX communicates with Mecanum wheel car via UART serial transmission.
Car Control Module: This module controls the car for left/ right/ back/ forward motion.
Car Motion Module: This part realizes the movement of the car following the red ball.
|
 IEEE/ICACT20220027 Slide.08
[Big Slide]