 |
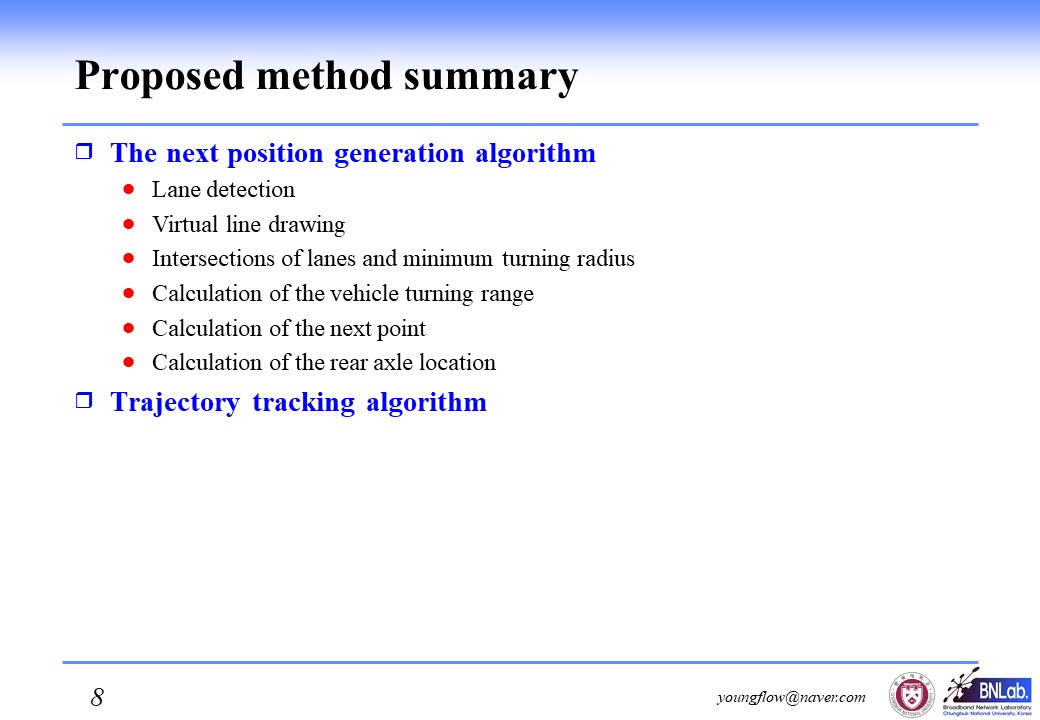
The proposed method is divided into two main categories.
The first is the next position generation algorithm
And the second is the Trajectory tracking algorithm
The next position generation algorithm proceeds with lane detection, drawing virtual lines, finding the intersection of lanes and minimum turning radius, calculating the vehicle’s turning range, calculating the next point, and calculating of the rear axle location.
Then, the steering angle is calculated through the trajectory tracking algorithm.
|
 IEEE/ICACT20220144 Slide.08
[Big Slide]