 IEEE/ICACT20230029 Slide.08
[Big Slide]
Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20230029 Slide.08
[Big Slide]
| Oral Presentation |
|
|
|
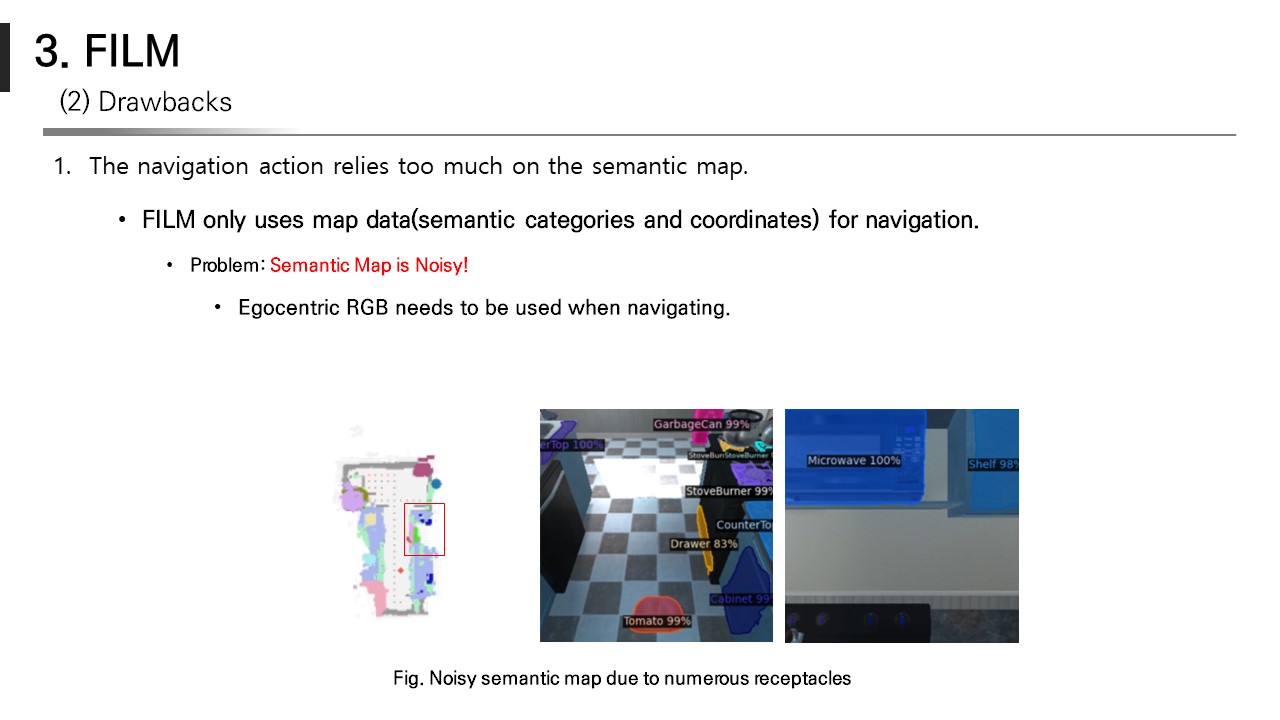
Let’s look at the drawbacks more precisely. The first drawback is the heavy reliance on the semantic map. FILM only uses map data, for navigation. And the map data include semantic categories and coordinates. However, Semantic map is often very noisy, especially when there are numerous receptacles in the provided scene. So, the agent is likely to struggle when locating the target object in this situation. Therefore, egocentric RGB, or direct visual observation needs to be used when navigating. | |
| [Go to Next Slide] |