 |
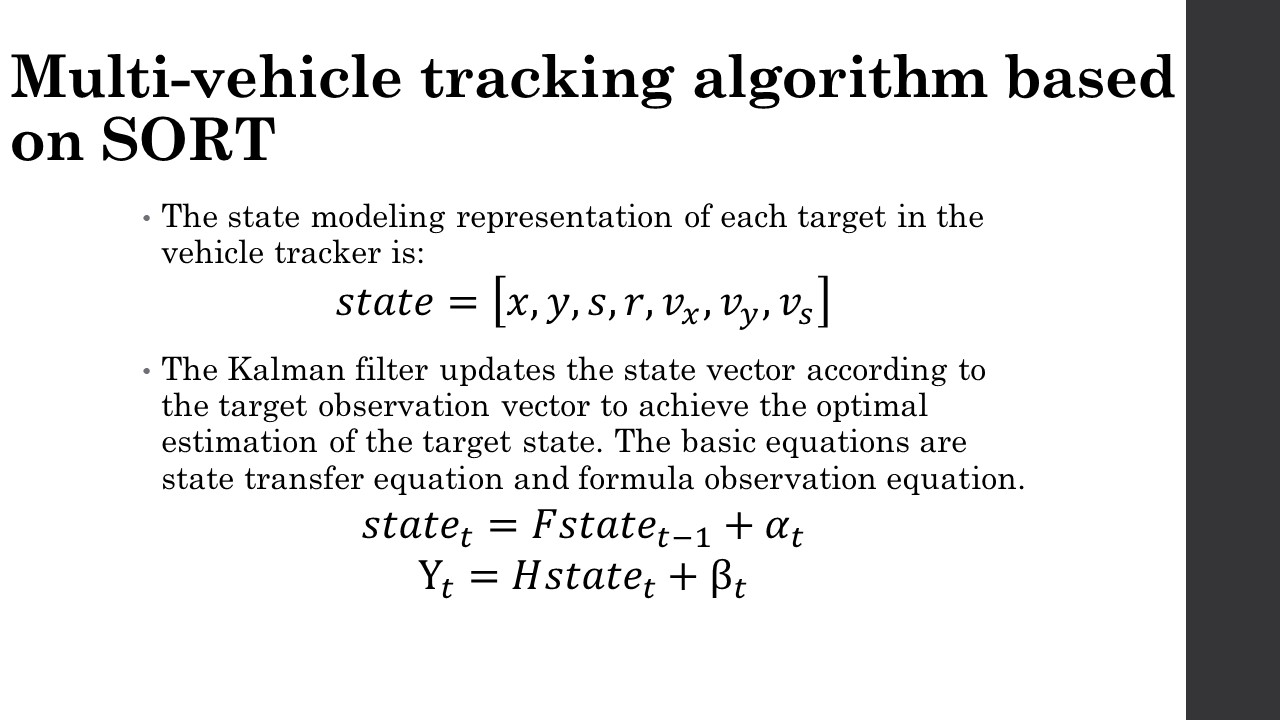
The state modeling representation of each target in the vehicle tracker is shown in formula. 𝑥 is the horizontal coordinate of the target center. 𝑦 is the vertical coordinates of target center. 𝑠 is the target boundary box area. 𝑟 is the target boundary frame aspect ratio. 𝑣_𝑥 is the target velocity in a horizontal component, 𝑣_𝑦 is a target velocity component in vertical direction, 𝑣_𝑠 is the area of the target boundary box change rate. The Kalman filter updates the state vector according to the target observation vector to achieve the optimal estimation of the target state. The basic equations are state transfer equation and observation equation.
|
 IEEE/ICACT20210157 Slide.09
[Big Slide]