 |
The system design is divided into hardware part and software part. The hardware part of the system is designed with a camera、Mecanum wheel car、NX development board、LCD monitor and other devices. The whole system design is based on the embedded deployment platform, through the camera to capture images after the input image preprocessing and transfer to the NX platform, and then the camera input video for target detection, while locating the position and size of the red ball supplemented by target tracking algorithm to track the position of the red ball in real time, finally, the results will be presented on the LCD display. NX through the UART serial port and Mecanum wheel car for communication. The car is controlled to move left/ right/ back/ forward to finally achieve the following motion of the red ball.
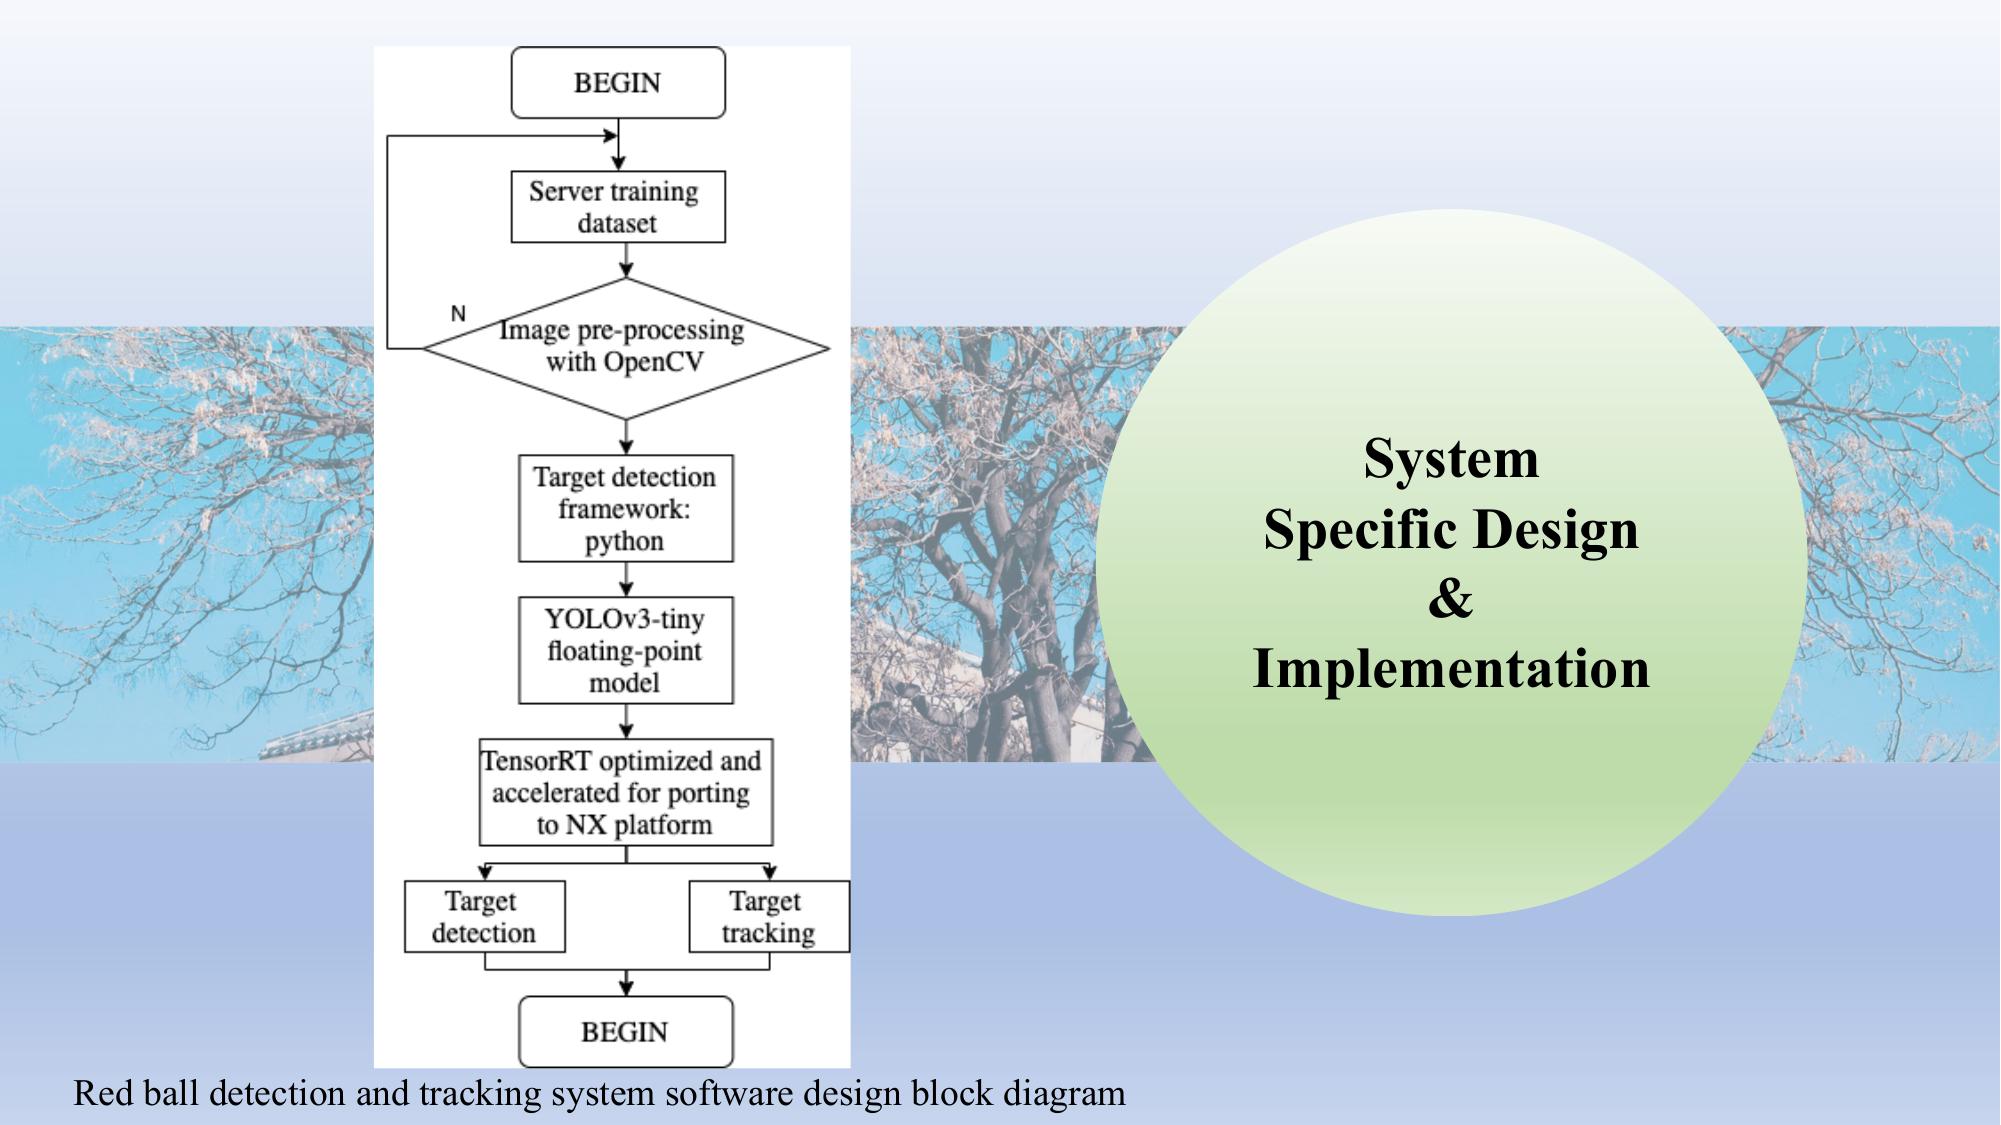
The software part of this system contains a software environment using TensorRT to optimize the model for acceleration, an OpenCV library is selected to preprocess the image input from the camera, and the PyTorch framework is chosen for feature extraction.
In this paper, we adopt the frame per second (FPS) of the image processed by the model algorithm as an indicator to measure the performance of the red ball target detection model. The red ball target detection and tracking system is designed with the fundamental goal of achieving the highest possible model representation ability under limited computational complexity, and to increase the actual execution speed of the model. After the preliminary dataset preparation and hardware design, the software part is designed and the overall software flow of the red ball detection and tracking system is shown in Figure.
|
 IEEE/ICACT20220027 Slide.09
[Big Slide]