 |
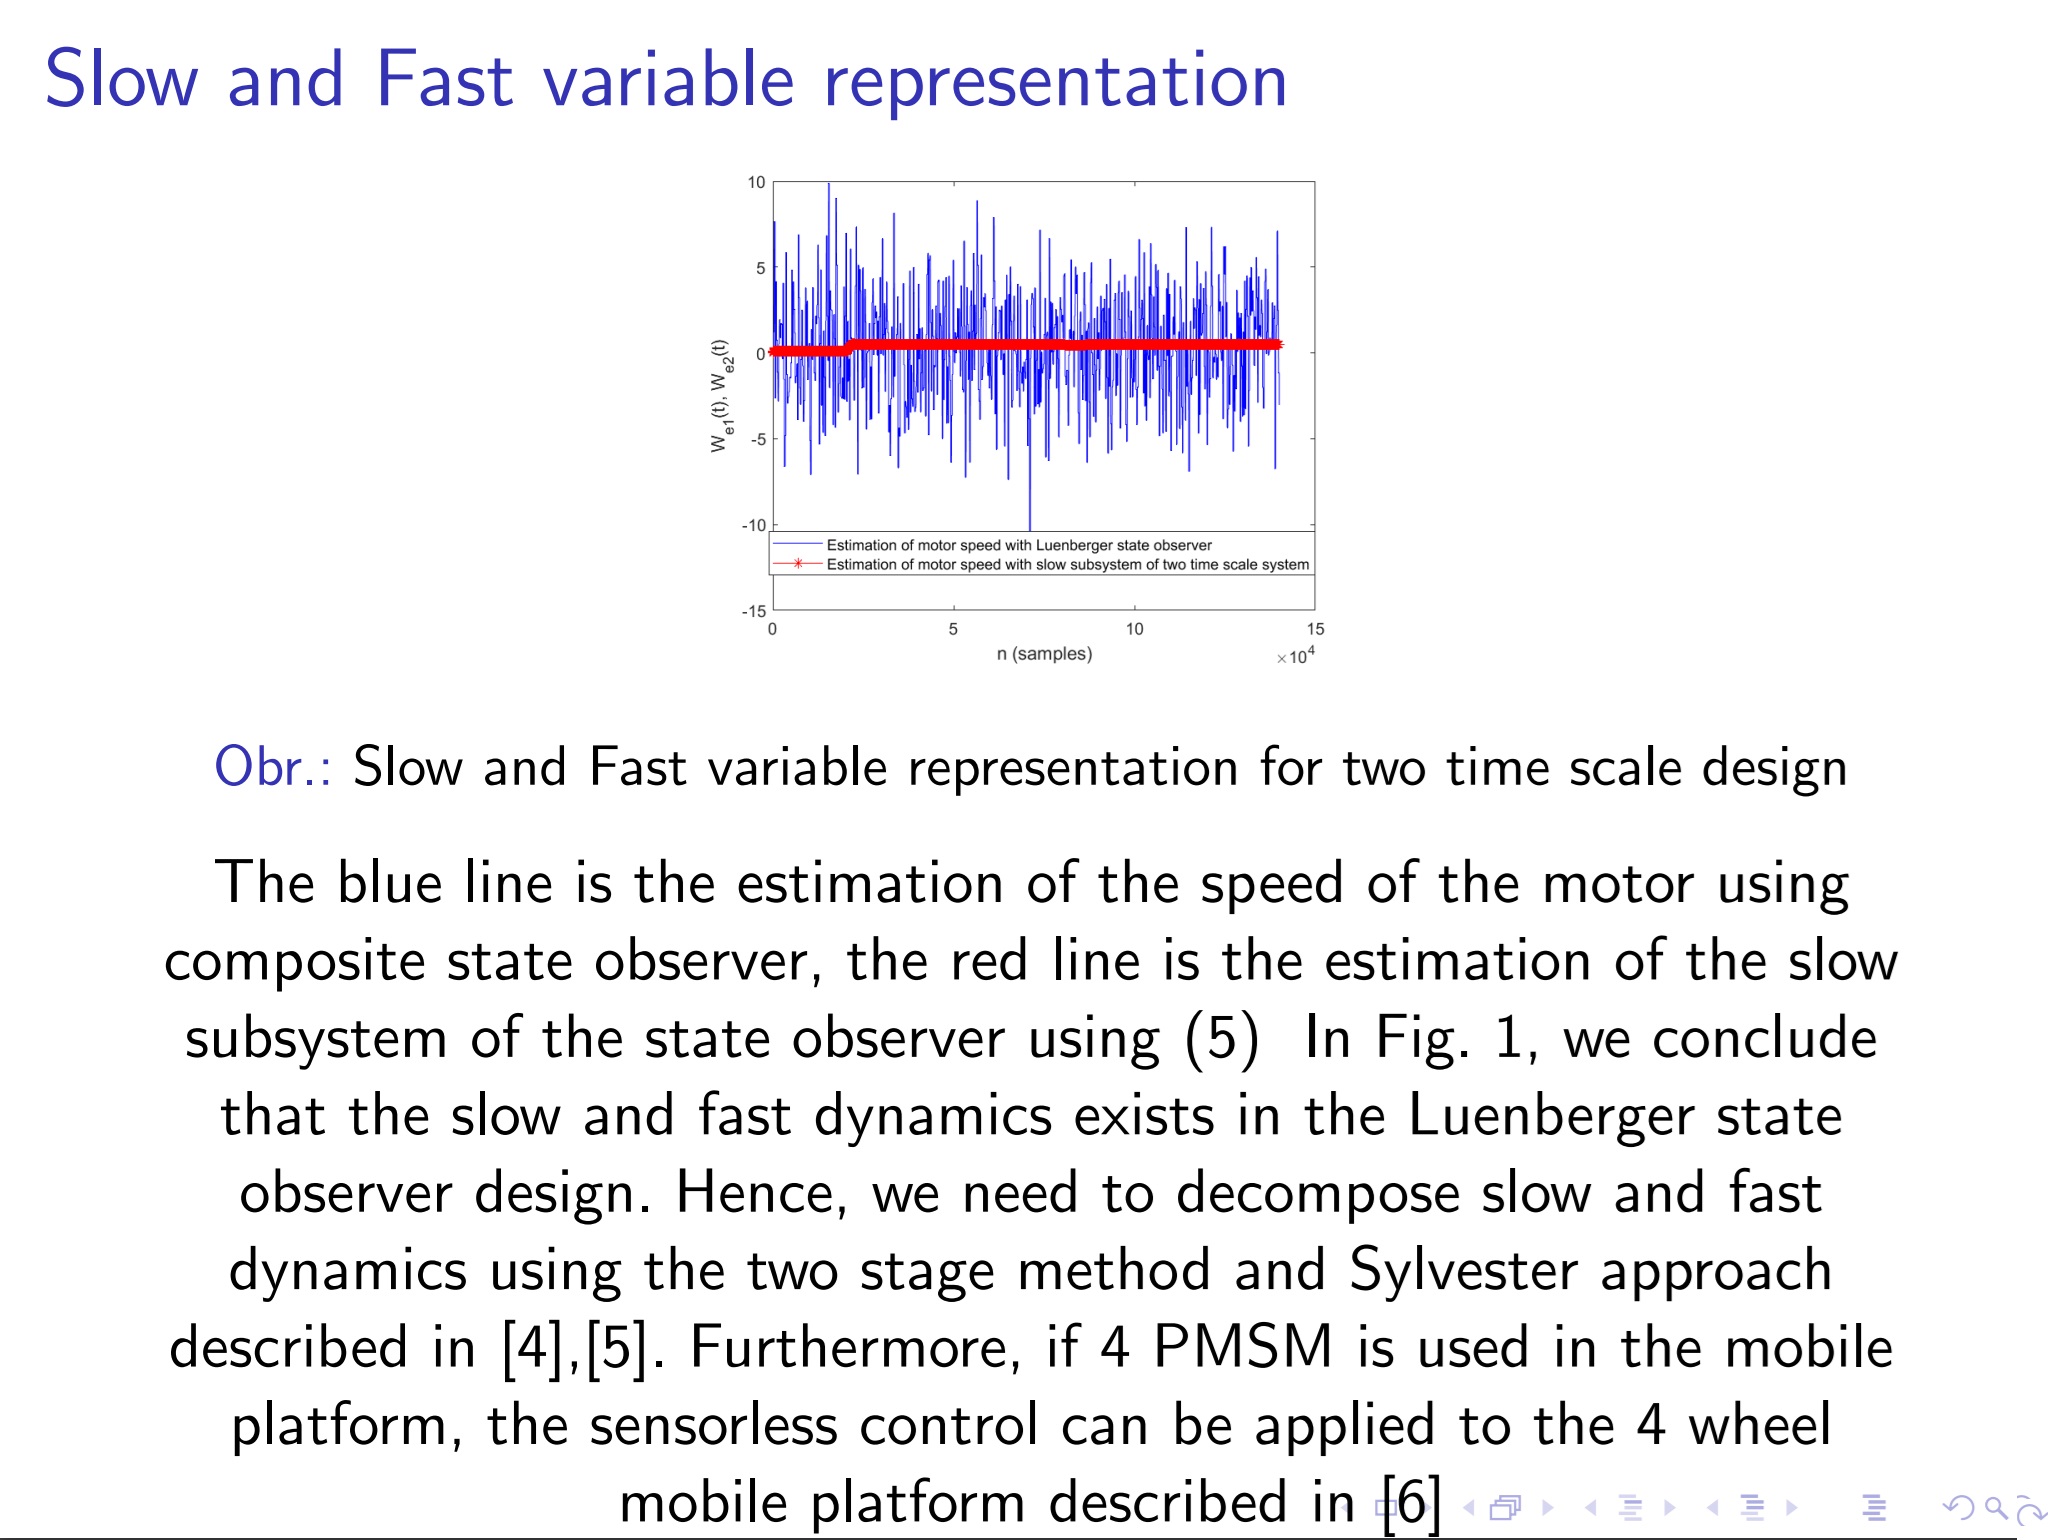
The blue line is the estimation of the speed of the motor using
composite state observer, the red line is the estimation of the slow
subsystem of the state observer using (5) In Fig. 1, we conclude
that the slow and fast dynamics exists in the Luenberger state
observer design. Hence, we need to decompose slow and fast
dynamics using the two stage method and Sylvester approach
described in [4],[5]. Furthermore, if 4 PMSM is used in the mobile
platform, the sensorless control can be applied to the 4 wheel
mobile platform described in [6] |
 IEEE/ICACT20250033 Slide.09
[Big Slide]