 |
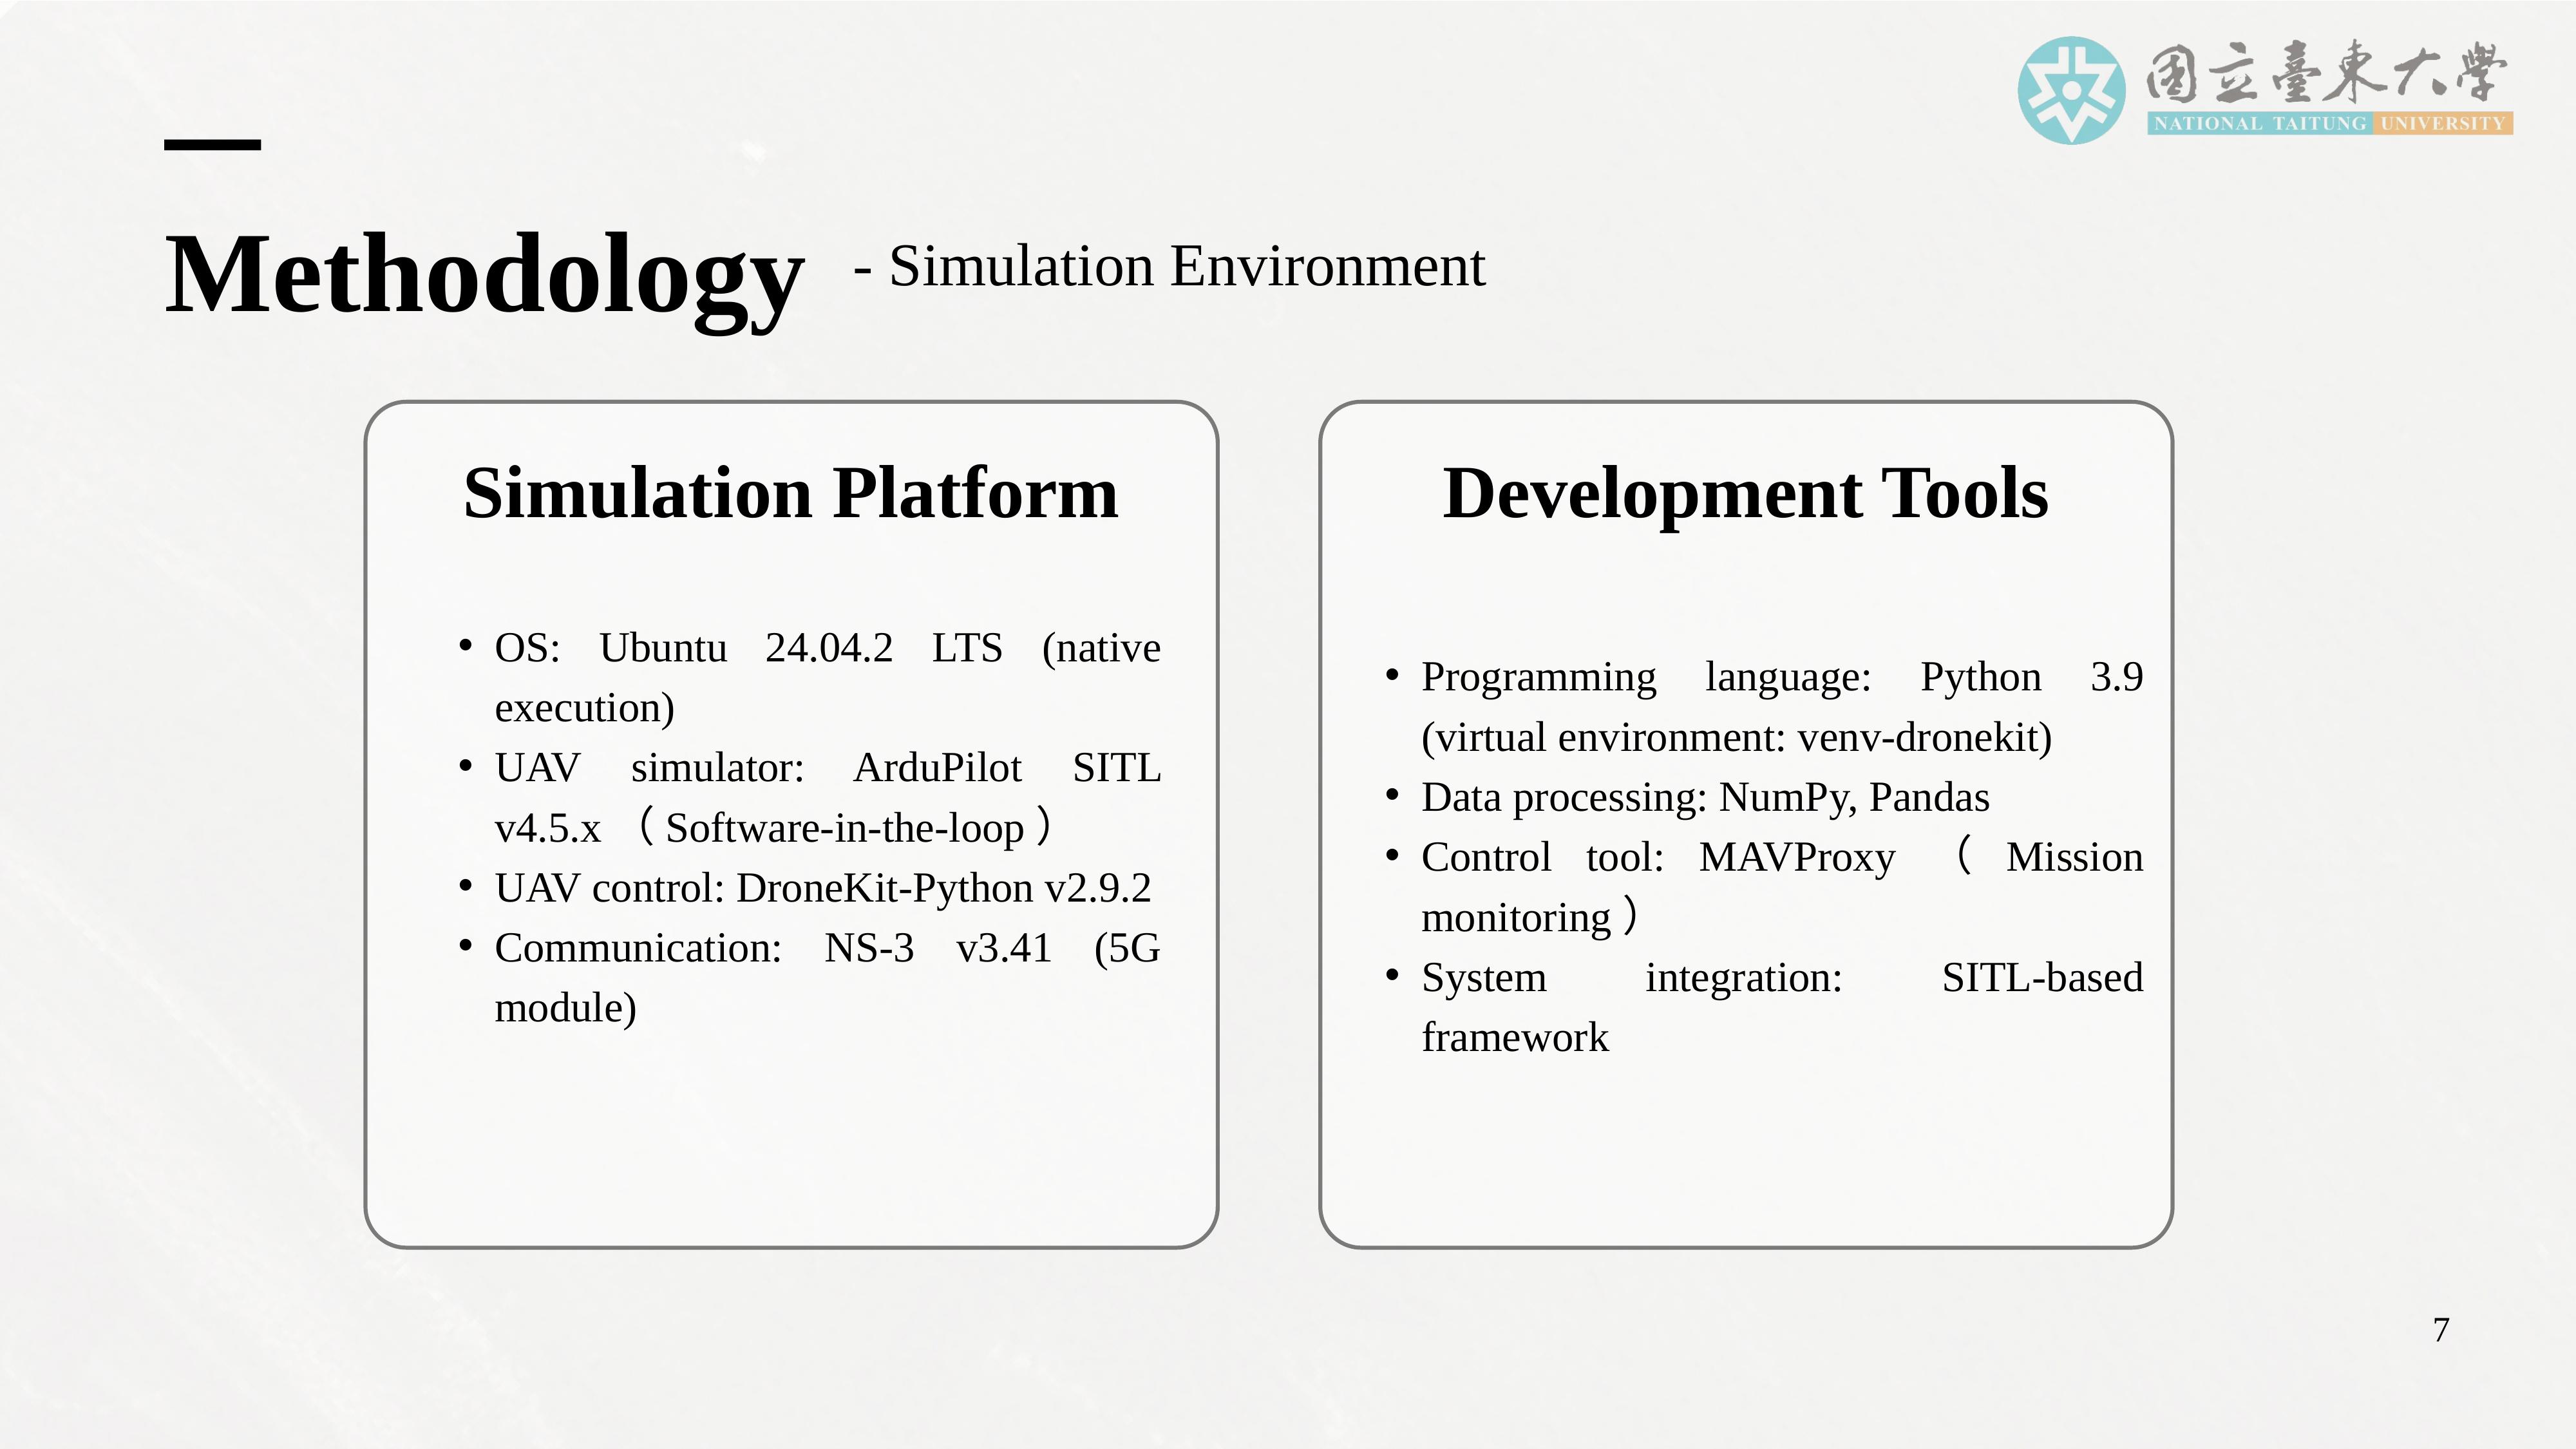
Let me now describe the simulation environment used in this study. All simulations are conducted on Ubuntu 24.04.2 LTS using native execution. UAV flight behavior is simulated using ArduPilot SITL, which provides a realistic software-in-the-loop environment for UAV control and flight dynamics.
DroneKit-Python is used to define UAV missions, generate trajectories, and control the UAV during simulation. For communication simulation, we use NS-3 version 3.41 with a 5G module, which allows us to model realistic wireless network behavior.
Data processing and performance analysis are performed using Python, along with NumPy and Pandas for numerical computation and data handling. MAVProxy is used for mission monitoring and control. This environment enables realistic and repeatable simulation of UAV flight and wireless communication within a unified framework. |
 IEEE/ICACT20260251 Slide.09
[Big Slide]