 IEEE/ICACT20210157 Slide.10
[Big Slide]
Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20210157 Slide.10
[Big Slide]
| Oral Presentation |
|
|
|
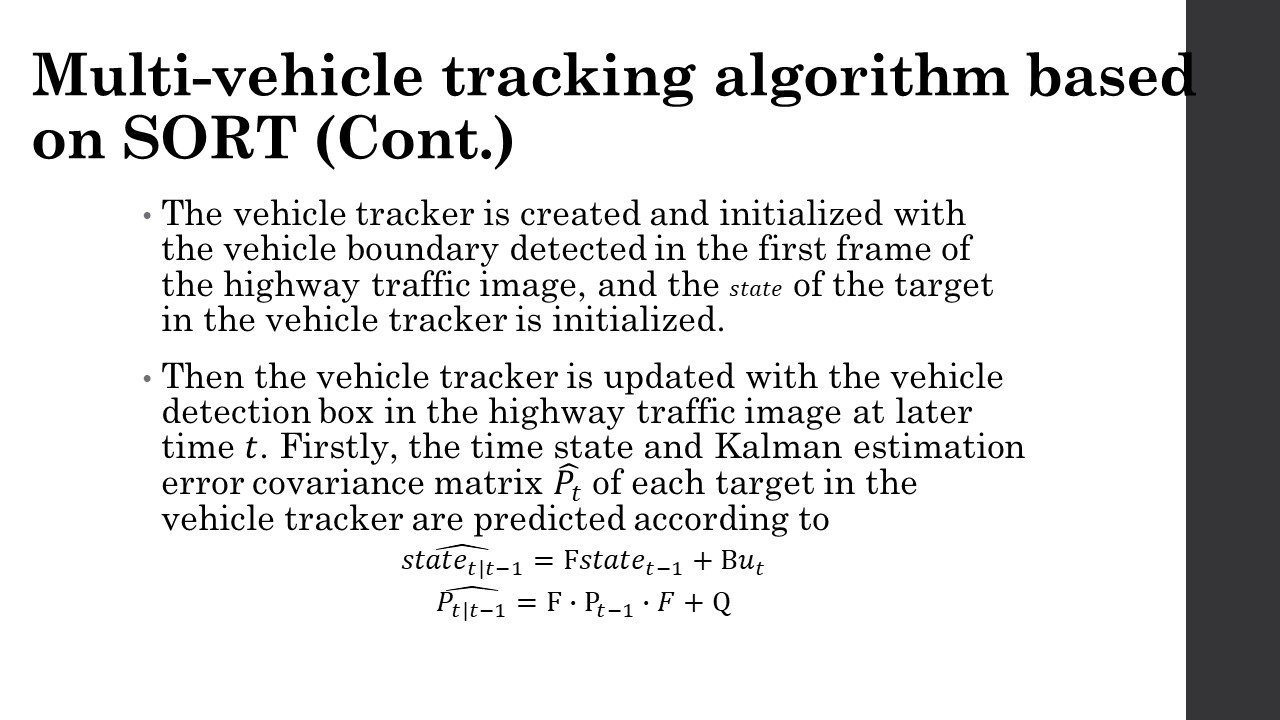
The vehicle tracker is created and initialized with the vehicle boundary detected in the first frame of the highway traffic image, and the 𝑠𝑡𝑎𝑡𝑒 of the target in the vehicle tracker is initialized. Then the vehicle tracker is updated with the vehicle detection box in the highway traffic image at later time 𝑡. Firstly, the time state and Kalman estimation error covariance matrix (𝑃_𝑡 ) ̂ of each target in the vehicle tracker are predicted according to the formula. | |
| [Go to Next Slide] |