 |
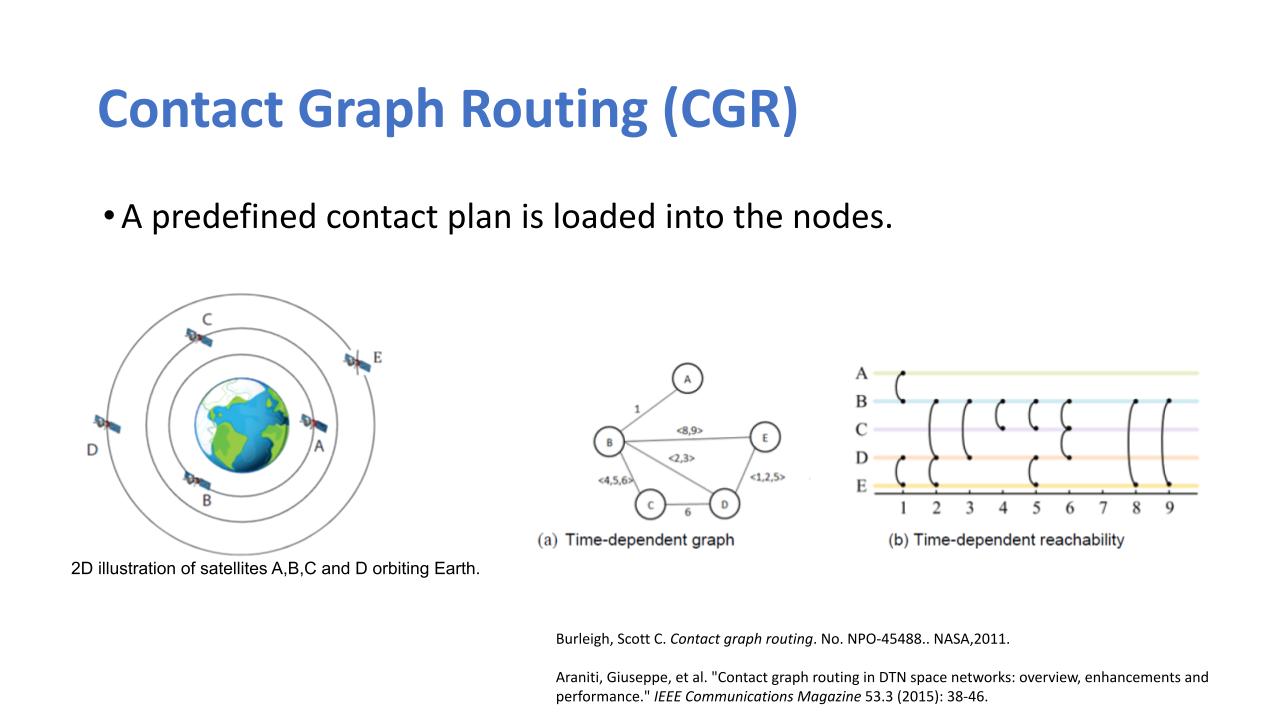
Now, going further to explain the contact graph routing. The contact graph routing, helps to determine the shortest path to follow for sending or transmitting data. Here you can see we have several satellites. This is a 2D illustration of satellites, A, B, C, and D orbiting the Earth, and each of them have a contact plan. So from here you can see, that all the contacts are time dependent. Being time dependent, there's a predefined contact plan meaning that it is not a probabilistic approach, hence the reason we extracted the real-time location of the satellites and it being a deterministic approach. The CGR relies on adapted Dijkstra¡¯s shortest path algorithm. This algorithm computes a route from a source to a target node using a contact graph that is based on a contact plan. Each vertex in the contact graph represents connectivity period between two nodes. Two vertices are connected by a directed edge if the end of the earlier contact matches the start of the next contact. The computed route is a sequence of contacts from the source to the destination. |
 IEEE/ICACT20240287 Slide.10
[Big Slide]