 IEEE/ICACT20250033 Slide.10
[Big Slide]
Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20250033 Slide.10
[Big Slide]
| Oral Presentation |
|
|
|
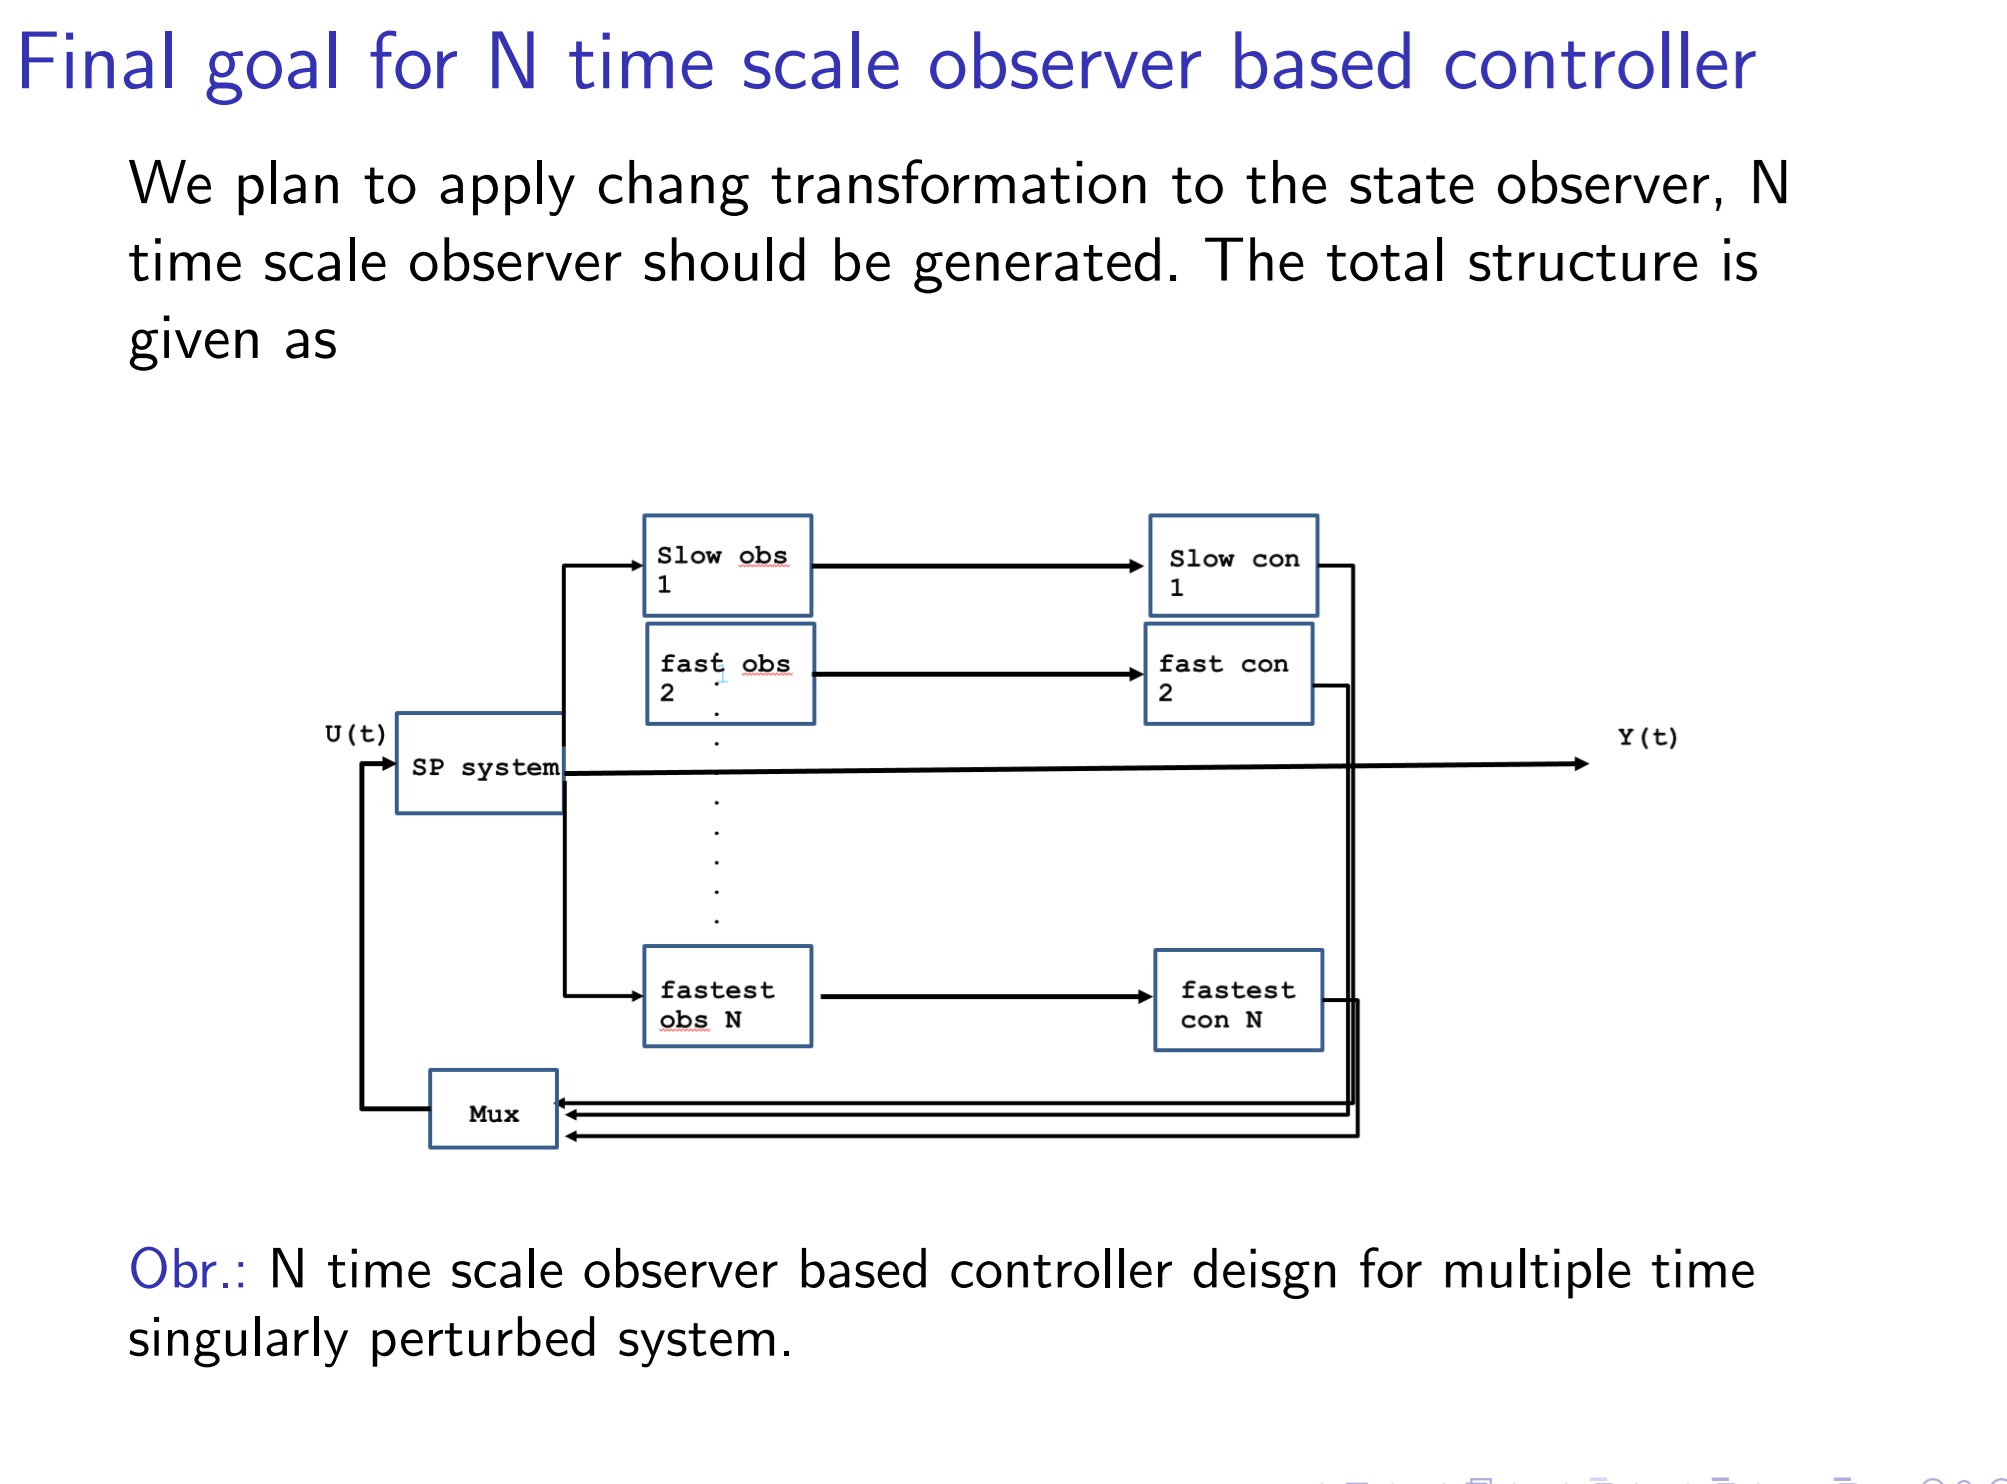
This is our future work, if we use 5 or 6 PMSM motors, the system might be more complicated. In that case, SP system mode can explicit multiple time scale behavior. In that case, we can decompose the syetem into N time scale mode. We can extend the result to N time scale observer and controller design. | |
| [Go to Next Slide] |