 IEEE/ICACT20250169 Slide.10
[Big Slide]
[YouTube] Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20250169 Slide.10
[Big Slide]
[YouTube] |
Oral Presentation |
|
|
|
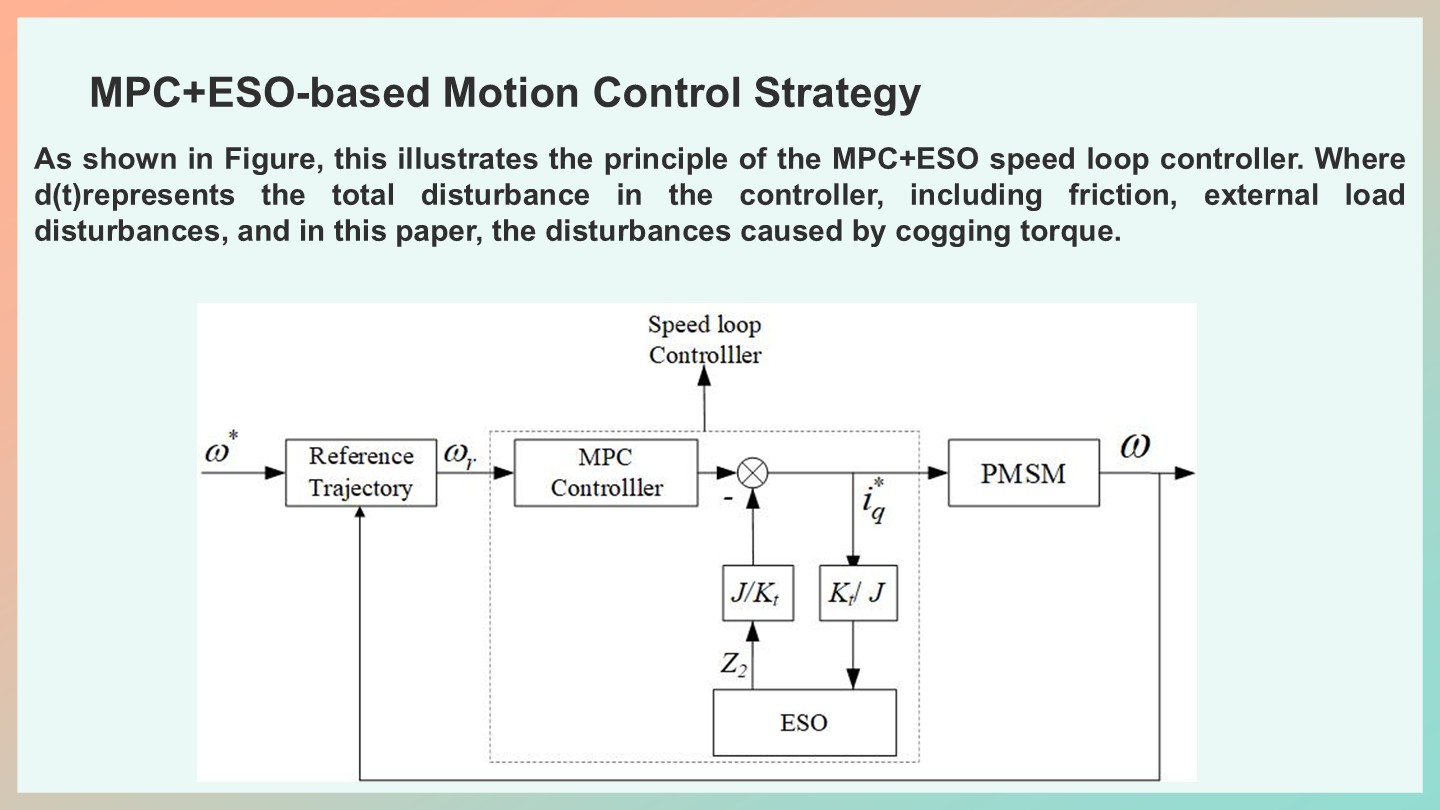
this illustrates the principle of the MPC+ESO speed loop controller. Where d(t)represents the total disturbance in the controller, including friction, external load disturbances, and in this paper, the disturbances caused by cogging torque. | |
| [Go to Next Slide] |