 IEEE/ICACT20210135 Slide.12
[Big Slide]
Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20210135 Slide.12
[Big Slide]
| Oral Presentation |
|
|
|
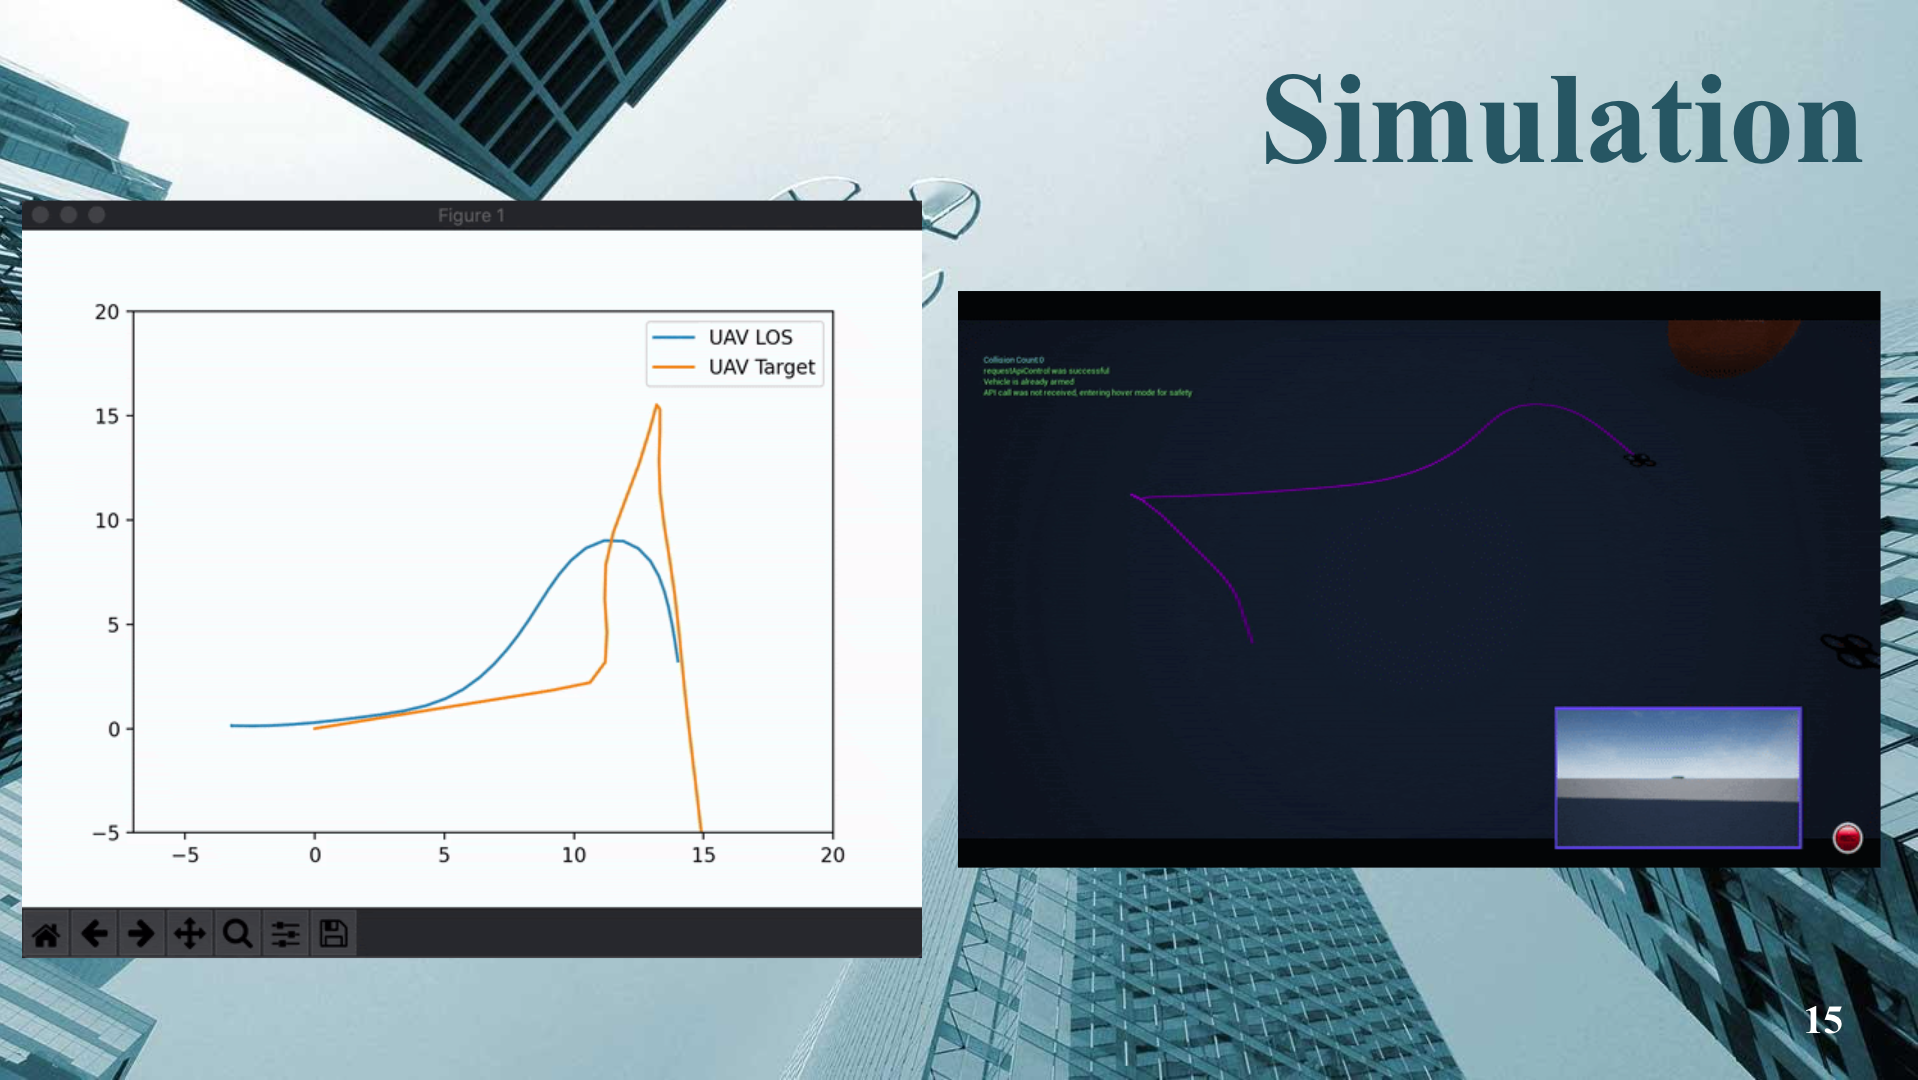
This is the video while the simulation is running. On the right hand side is the windows of the simulation as u can see there are 2 UAV the first one is the target moving along waypoint we set by using the flight controller API that we wrote in python the second one is the follower UAV try to follow the target by using own algorithm | |
| [Go to Next Slide] |