 |
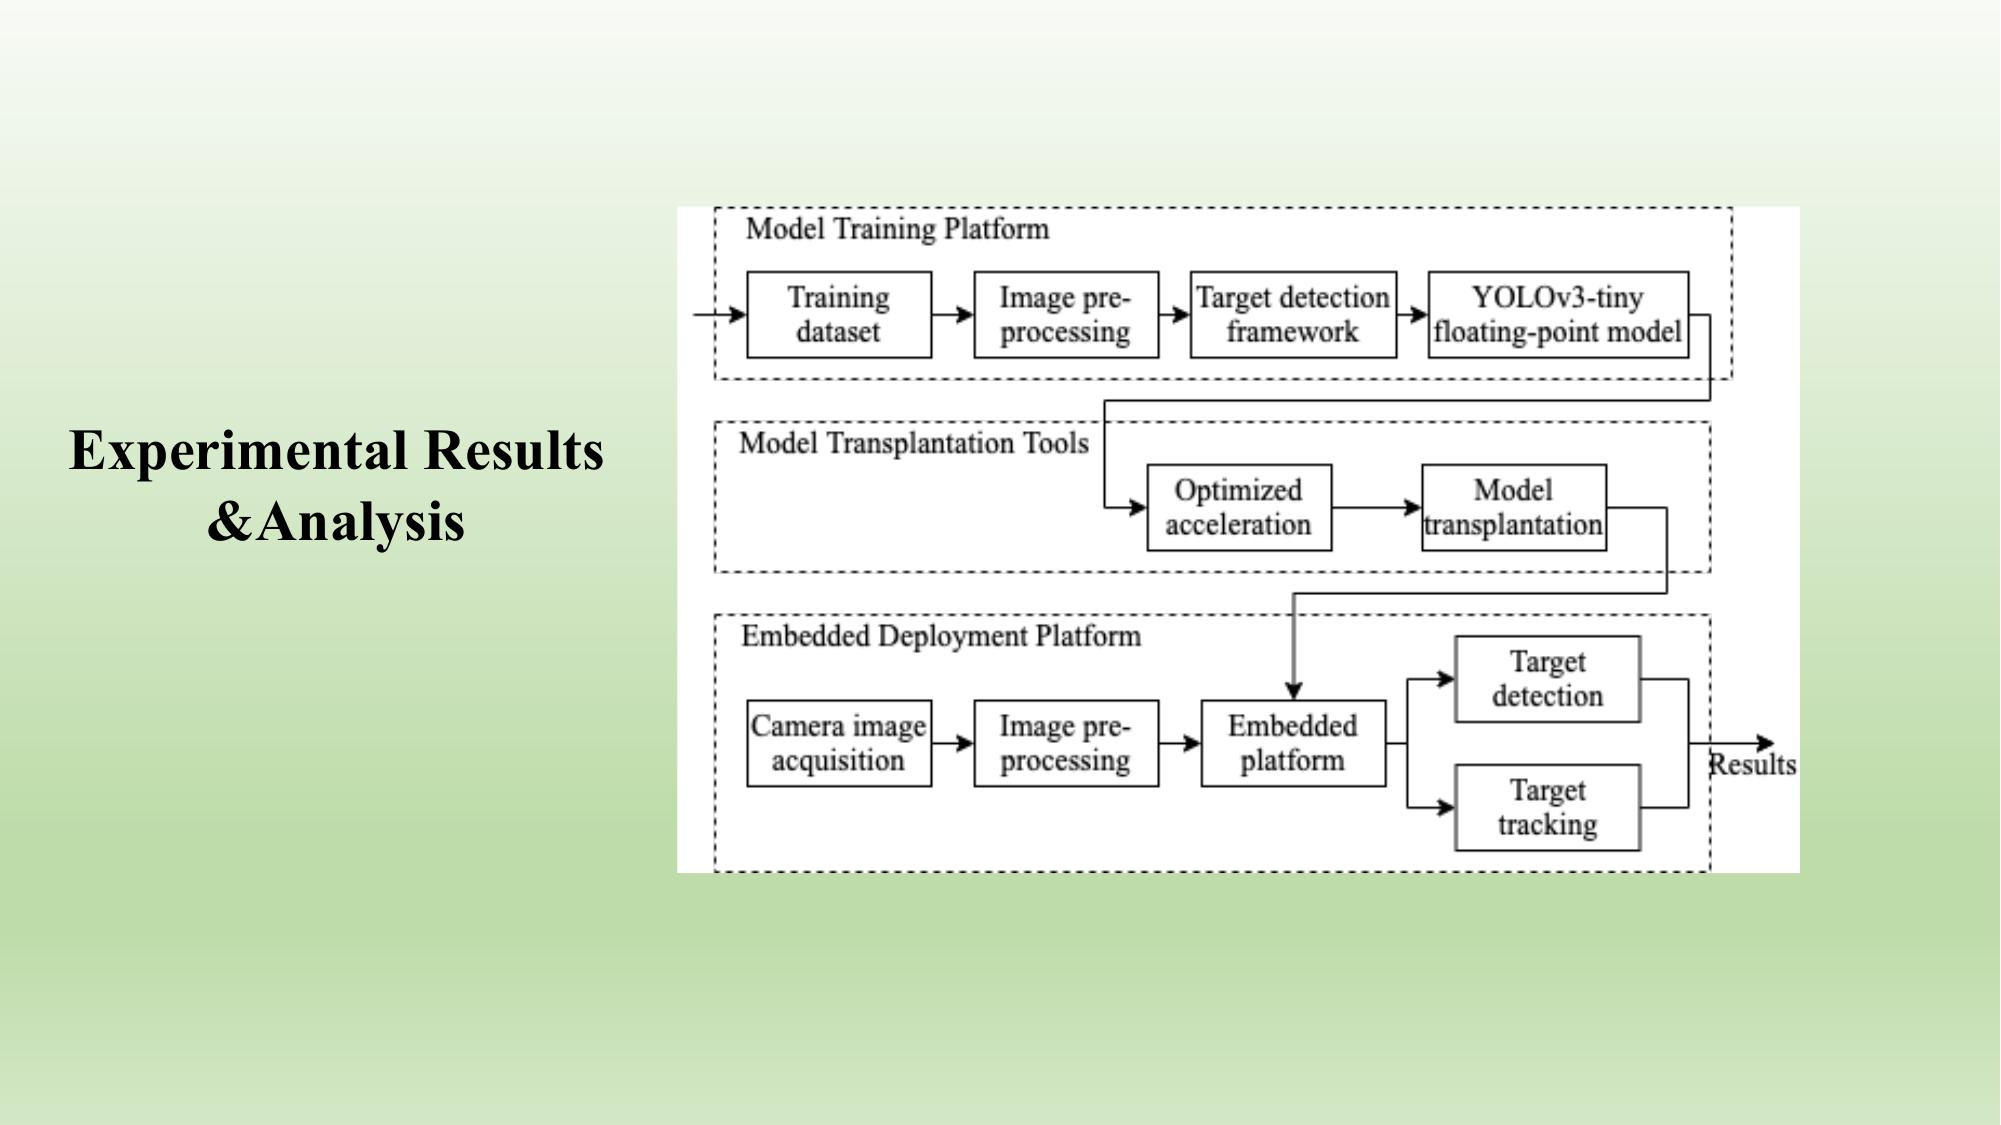
The fundamentally purpose of the experiments in this paper is to deploy the YOLOv3-tiny model with KCF algorithm to the embedded the terminal NX. The data flow architecture of the model terminal deployment consists of three modules.
The first module: server-based to complete this part of the experiment. First train the dataset, preprocess the images and input them into the target detection framework to extract features, and then feeding the extracted features into the YOLOv3-tiny floating-point model.
The second module: based on the model migration tool. Using TensorRT to optimize the acceleration of the YOLOv3-tiny floating-point model, and transplant the processed model to the embedded deployment platform.
The third module: based on the embedded deployment platform. The images are captured by the camera, and the input images are preprocessed and transmitted to the NX platform. The location and size of the red ball are found after performing the target detection on the video input by the camera, and then supplemented with target tracking algorithm to track the position of the red ball in real time. NX then communicates with Mecanum wheel car through the UART serial port to control the movement of the car.
|
 IEEE/ICACT20220027 Slide.12
[Big Slide]