 |
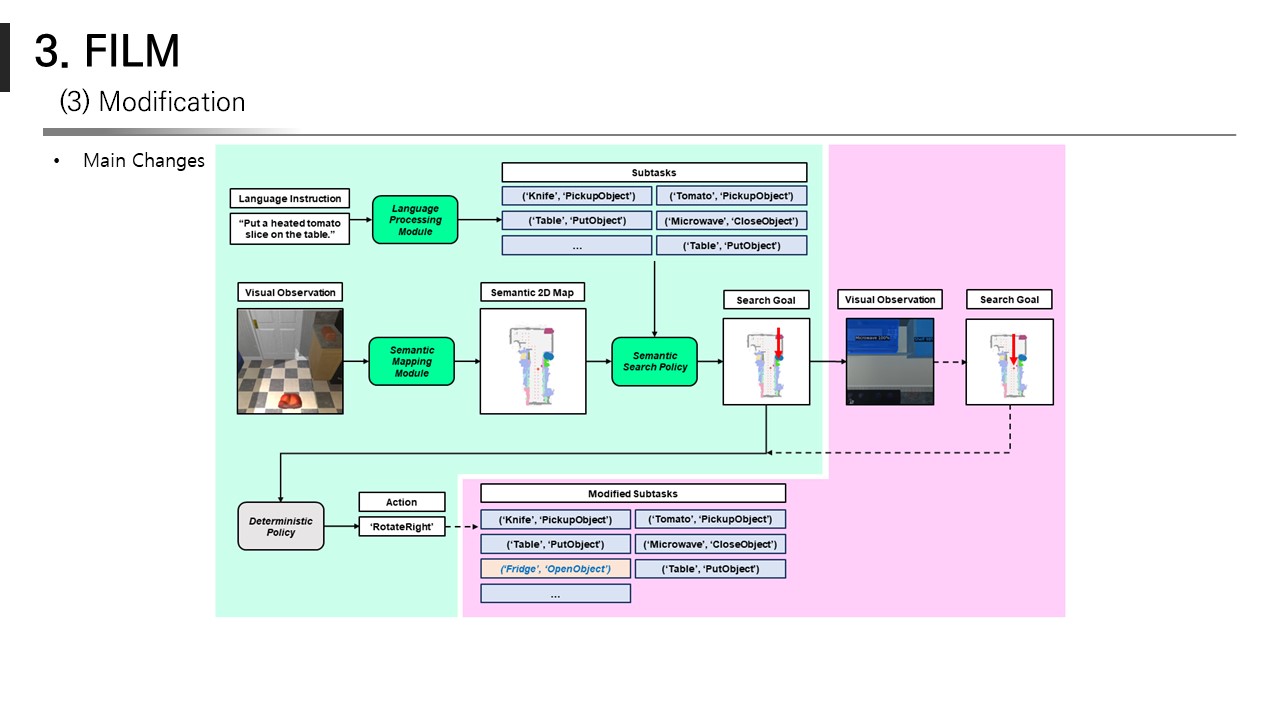
To migrate the mentioned drawbacks, we propose the modified deterministic policy. With the modified deterministic policy, the agent uses visual observations for locating the target object and performs “active” search if the target object is not observed in the current environment by changing the list of subtasks. The figure shows the model overview. The background color denotes the original and the modified architecture of FILM. The part in green indicates the original structure, and pink indicates the modified structure. In the modified model, the Search Goal is selected as the coordinates of the target object in the semantic map or selected by the Semantic Search Policy for every 25 steps. But if the target object mask is observed in the Visual Observation, the Search Goal is changed to current location. Furthermore, the modified model also changes the list of subtask. If the target object is not found after enough steps, the list of subtasks is modified, and the agent opens receptacles for search.
|
 IEEE/ICACT20230029 Slide.12
[Big Slide]