 |
The basic elements of task controller and power controller are set as follows:
Agent: The task controller is configured at the users to manage the user¡¯s subtask offloading. The power controller is configured at BS to manage the transmission power of users.
State: The state of the task controller is expressed as , where is the adjacency matrix of the subtask dependency DAG. The state of the power controller is expressed as Spc = , where is the total number of bits transmitted by the user a.
Action: The action of the task controller is expressed as . The action of the power controller is expressed as .
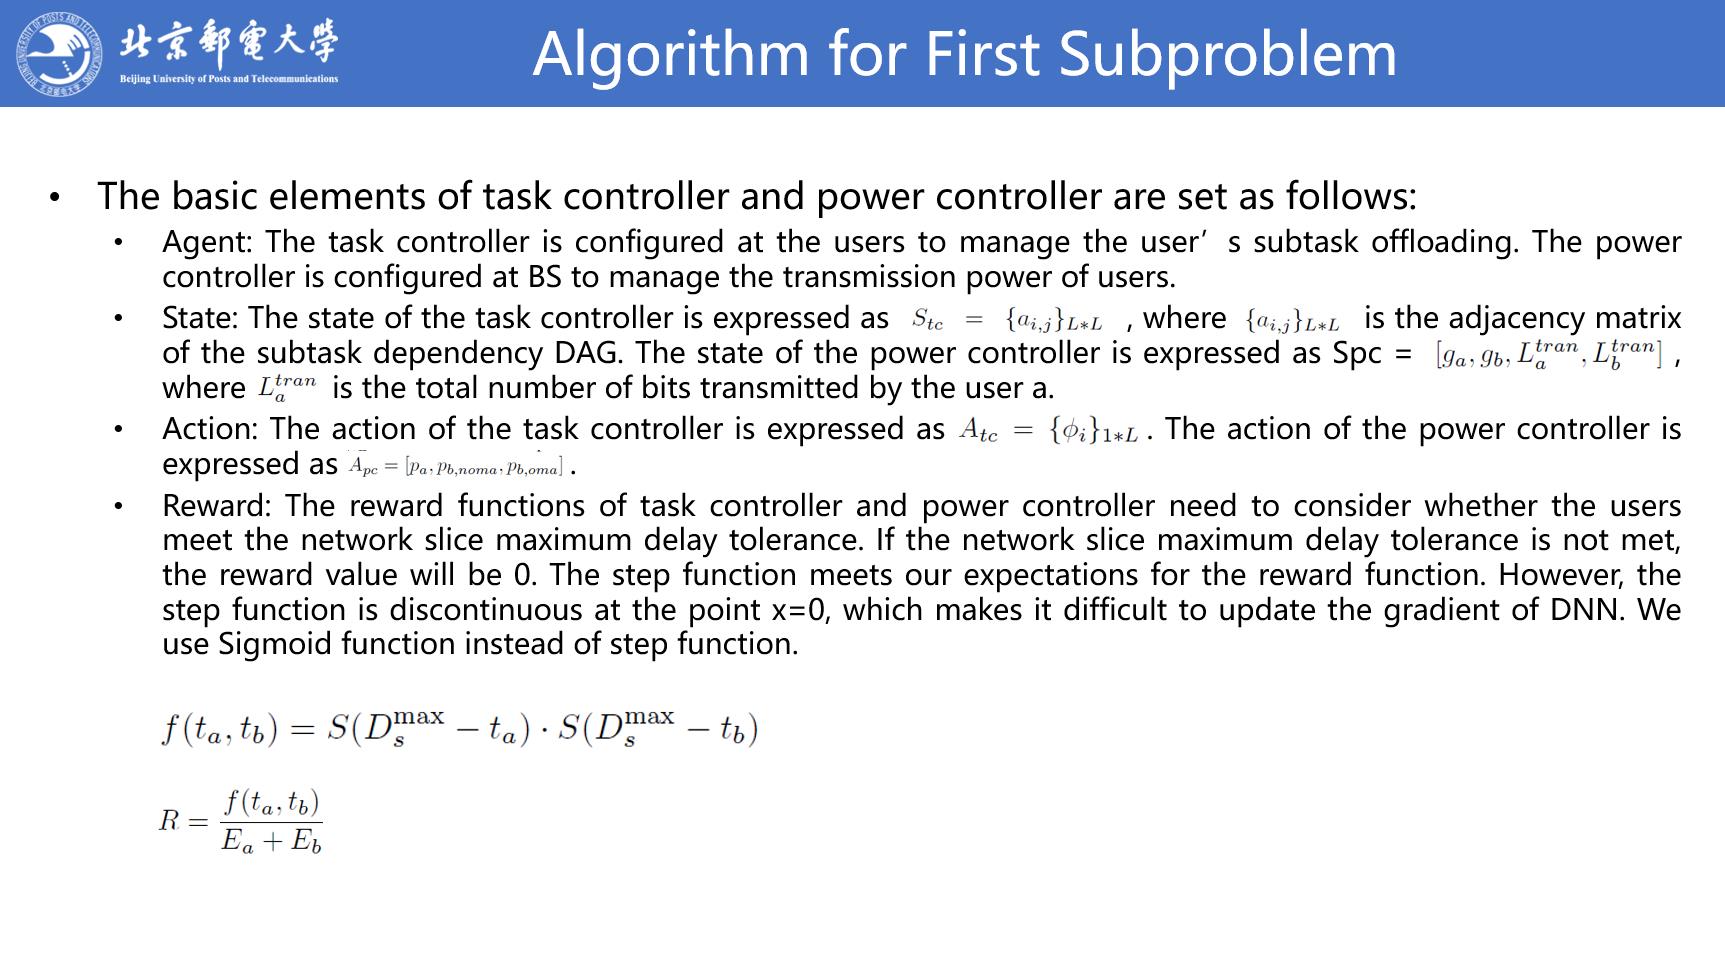
Reward: The reward functions of task controller and power controller need to consider whether the users meet the network slice maximum delay tolerance. If the network slice maximum delay tolerance is not met, the reward value will be 0. The step function meets our expectations for the reward function. However, the step function is discontinuous at the point x=0, which makes it difficult to update the gradient of DNN. We use Sigmoid function instead of step function.
|
 IEEE/ICACT20230164 Slide.12
[Big Slide]