 |
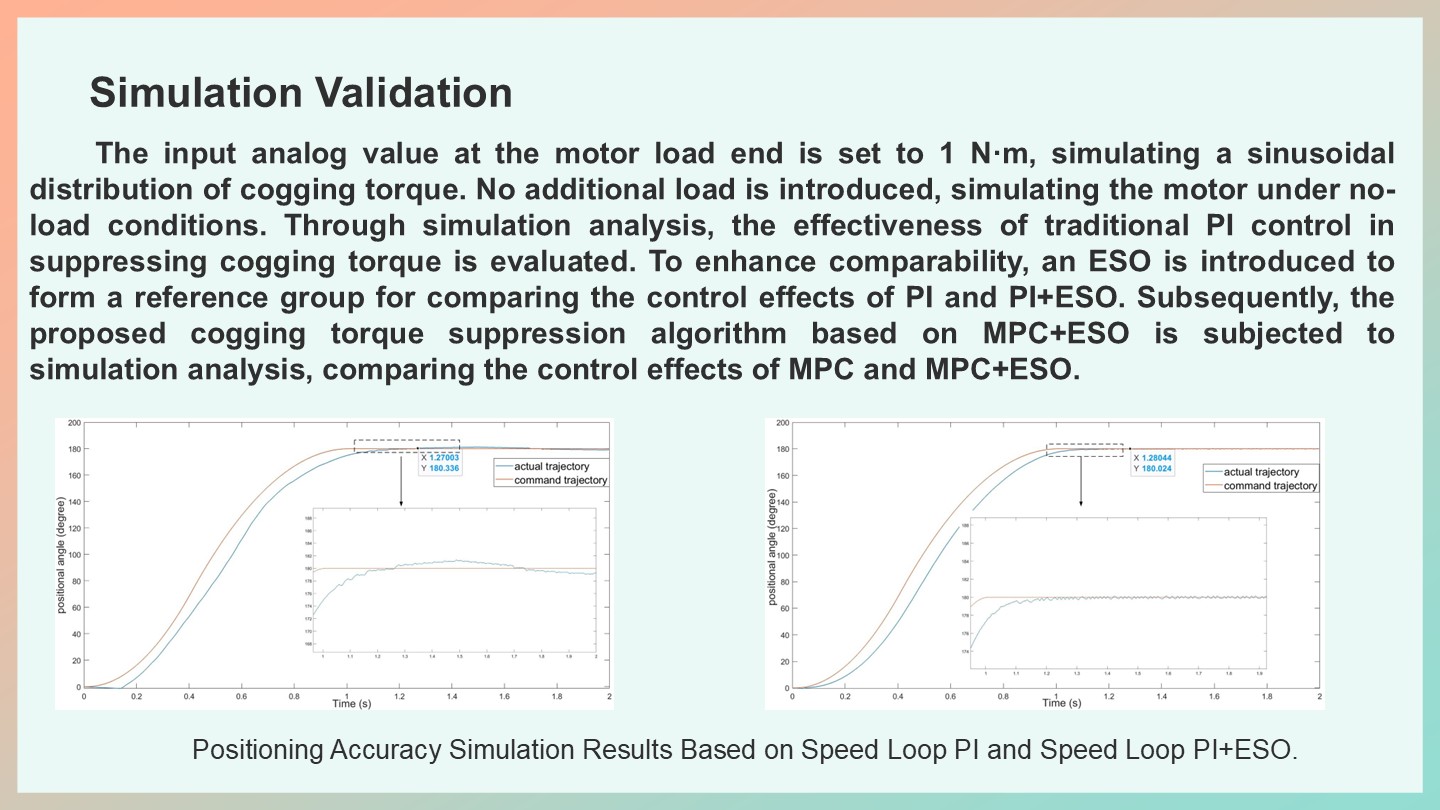
The input analog value at the motor load end is set to 1 N¡¤m, simulating a sinusoidal distribution of cogging torque. No additional load is introduced, simulating the motor under no-load conditions. Through simulation analysis, the effectiveness of traditional PI control in suppressing cogging torque is evaluated. To enhance comparability, an ESO is introduced to form a reference group for comparing the control effects of PI and PI+ESO. Subsequently, the proposed cogging torque suppression algorithm based on MPC+ESO is subjected to simulation analysis, comparing the control effects of MPC and MPC+ESO. |
 IEEE/ICACT20250169 Slide.12
[Big Slide]
[YouTube]