 |
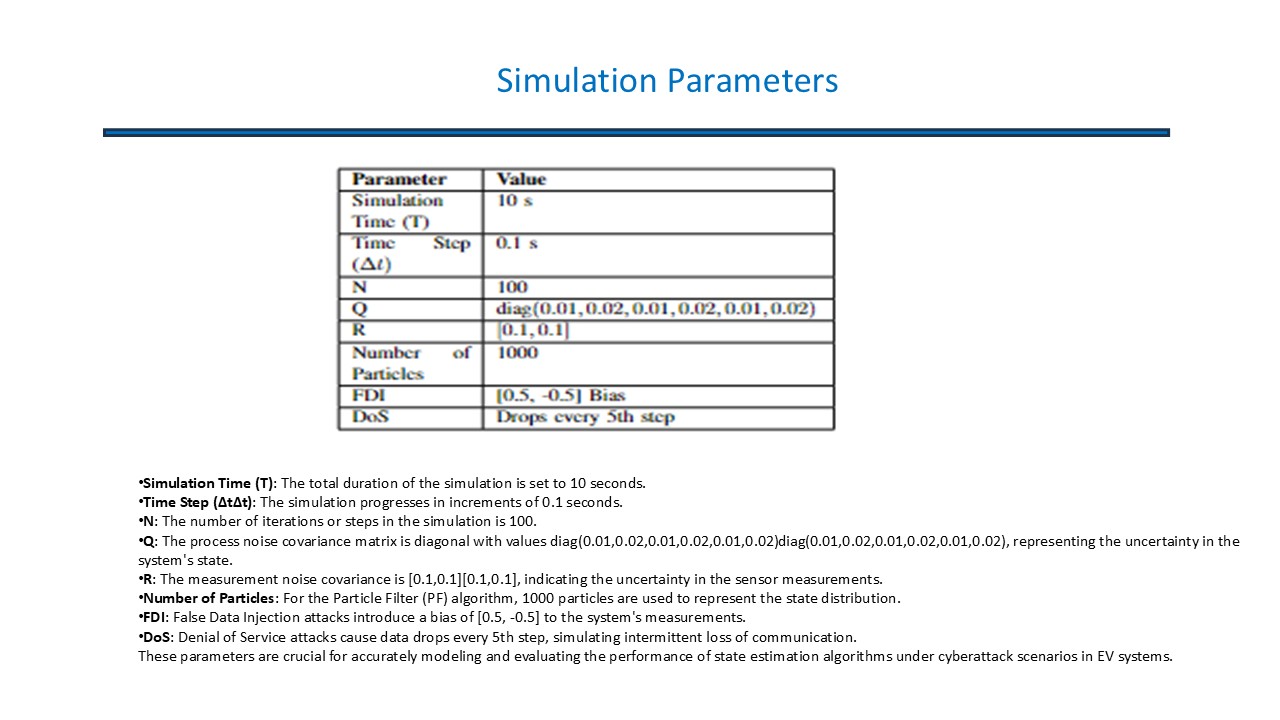
Simulation Time (T): The total duration of the simulation is set to 10 seconds.
Time Step (¥Ät¥Ät): The simulation progresses in increments of 0.1 seconds.
N: The number of iterations or steps in the simulation is 100.
Q: The process noise covariance matrix is diagonal with values diag(0.01,0.02,0.01,0.02,0.01,0.02)diag(0.01,0.02,0.01,0.02,0.01,0.02), representing the uncertainty in the system's state.
R: The measurement noise covariance is [0.1,0.1][0.1,0.1], indicating the uncertainty in the sensor measurements.
Number of Particles: For the Particle Filter (PF) algorithm, 1000 particles are used to represent the state distribution.
FDI: False Data Injection attacks introduce a bias of [0.5, -0.5] to the system's measurements.
DoS: Denial of Service attacks cause data drops every 5th step, simulating intermittent loss of communication.
These parameters are crucial for accurately modeling and evaluating the performance of state estimation algorithms under cyberattack scenarios in EV systems.
|
 IEEE/ICACT20250208 Slide.12
[Big Slide]
[YouTube]