 IEEE/ICACT20250244 Slide.12
[Big Slide]
Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20250244 Slide.12
[Big Slide]
| Oral Presentation |
|
|
|
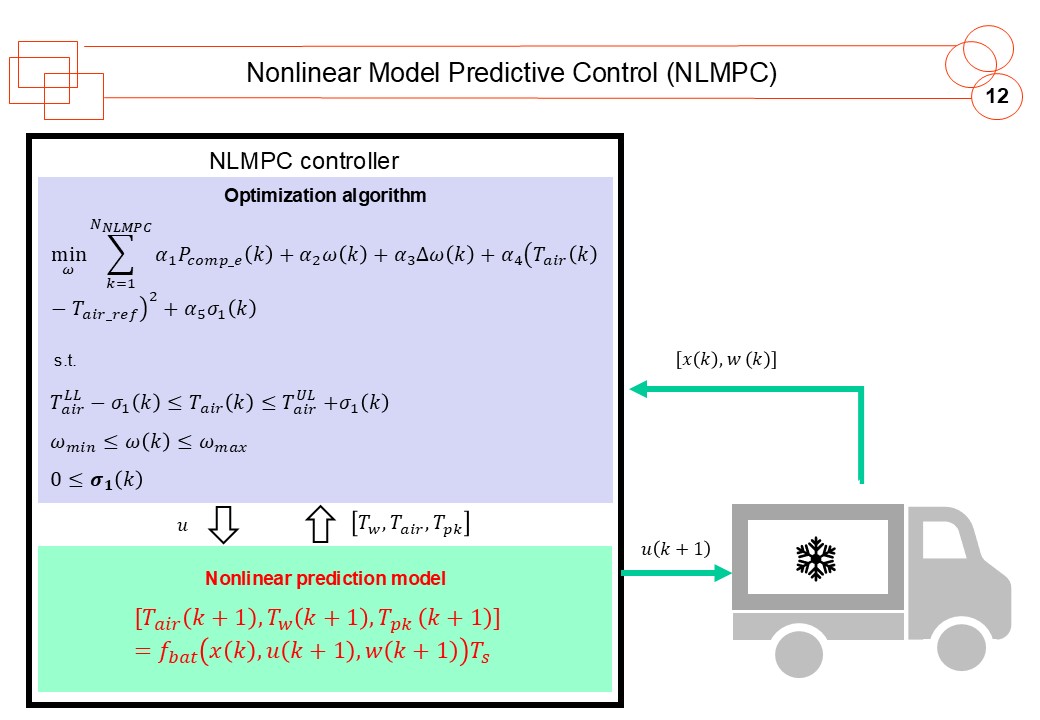
In this work, we developed two MPC controllers. The first one is Nonlinear MPC (NLMPC). In MPC, there is an optimization algorithm and a prediction model. The controller takes measurements from the system, and the prediction model estimates future temperature trajectories within a finite prediction horizon. These predicted states are then used to minimize a cost function, and the optimal control action is applied to the plant. This Nonlinear MPC serves as a benchmark for comparison. | |
| [Go to Next Slide] |