 |
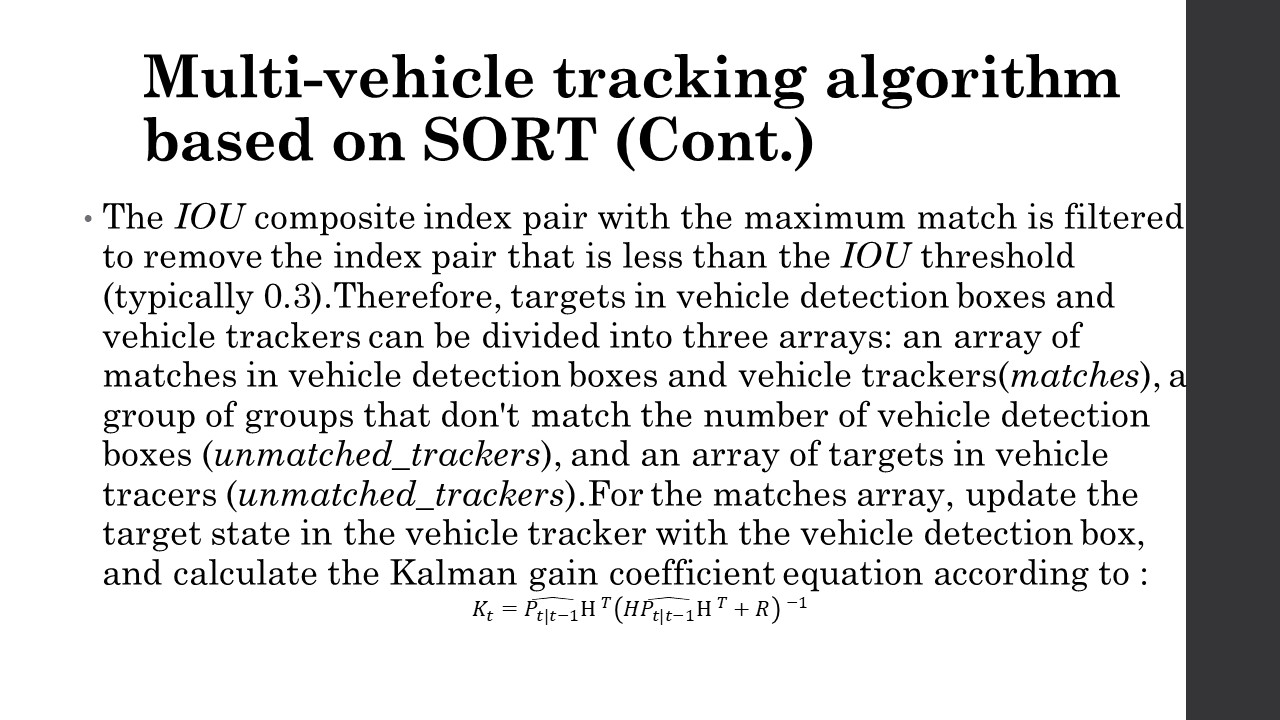
The IOU composite index pair with the maximum match is filtered to remove the index pair that is less than the IOU threshold (typically 0.3).Therefore, targets in vehicle detection boxes and vehicle trackers can be divided into three arrays: an array of matches in vehicle detection boxes and vehicle trackers(matches), a group of groups that don't match the number of vehicle detection boxes (unmatched_trackers), and an array of targets in vehicle tracers (unmatched_trackers).For the matches array, update the target state in the vehicle tracker with the vehicle detection box, and calculate the Kalman gain coefficient equation according to the formula.
|
 IEEE/ICACT20210157 Slide.13
[Big Slide]