 |
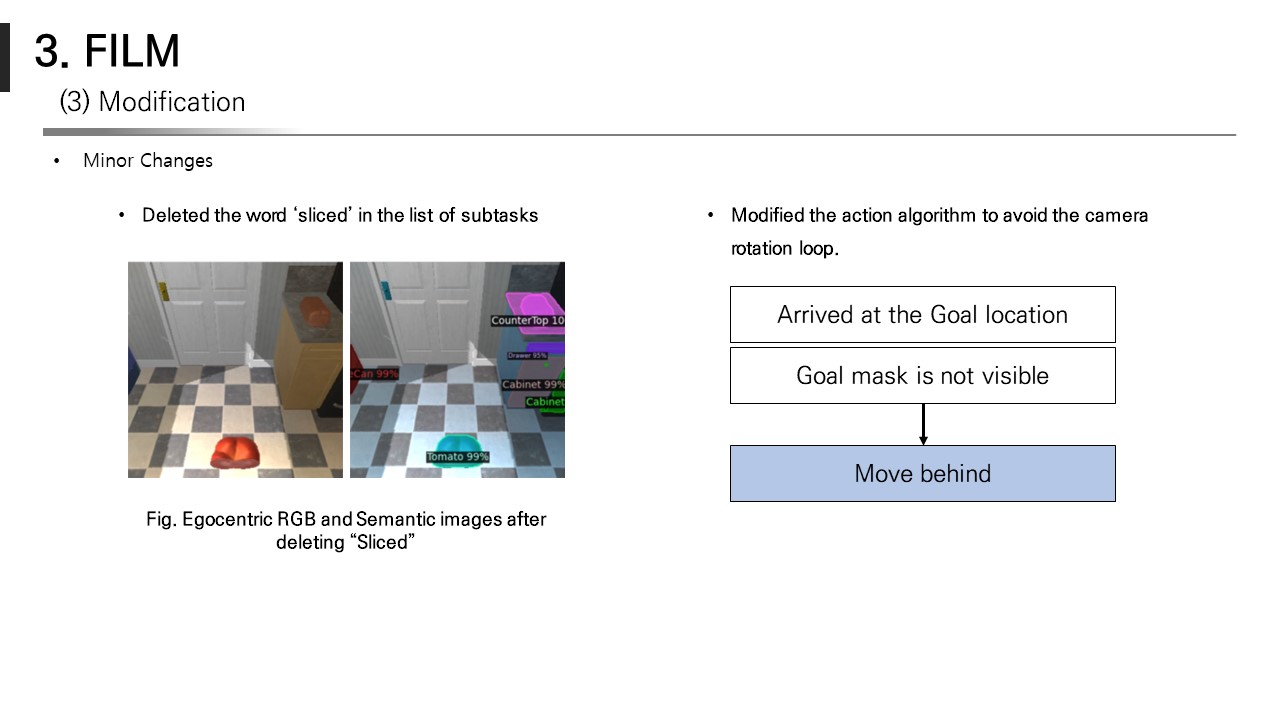
In addition, we added minor changes to avoid semantic segmentation error. First, we deleted the “sliced” object from the subtask template. The pretrained Mask-RCNN module struggles in distinguishing non-sliced object and sliced object. It both classifies both objects as non-sliced object, so it is meaningless to differentiate those two in the subtasks. Moreover, in the deterministic policy, there’s a part where the agent rotates the camera angle right and left repeatedly if it is arrived at the goal location but cannot observe any goal mask. The agent often trap itself in a camera rotation loop if it fails in semantic segmentation. This occasionally happens when the goal object is only observed partially in the visual observation frame. Thus, we modified the algorithm to move behind to get the whole picture if camera rotation loop happens.
|
 IEEE/ICACT20230029 Slide.13
[Big Slide]