 |
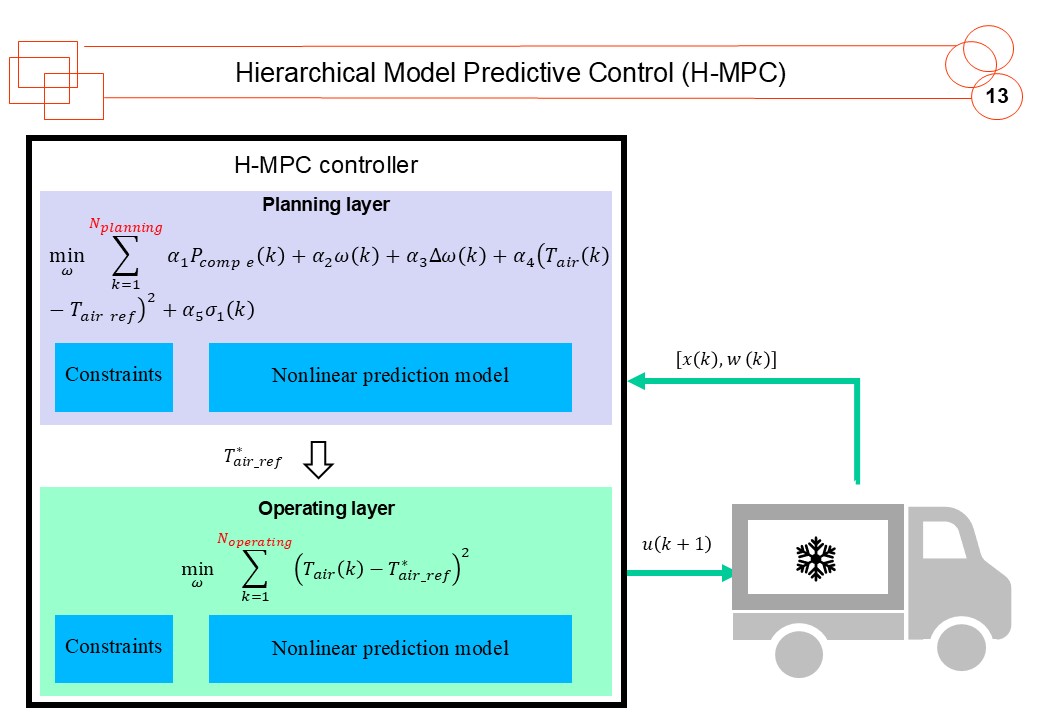
The second controller we developed is Hierarchical MPC (H-MPC). In this structure, we use two MPC controllers: one in the planning layer and another in the operating layer. The upper (planning) layer performs long-horizon optimization, prioritizing energy savings. The lower (operating) layer focuses on short-horizon control, tracking the optimal cargo space temperature trajectory, which was produced from the planning layer. The constraints and prediction models in Hierarchical MPC are the same as in Nonlinear MPC. But one very interesting thing is that the two MPC controllers on both layers can use different prediction horizons and sampling times. This can help to reduces computational intensity. |
 IEEE/ICACT20250244 Slide.13
[Big Slide]