 IEEE/ICACT20210265 Slide.14
[Big Slide]
Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20210265 Slide.14
[Big Slide]
| Oral Presentation |
|
|
|
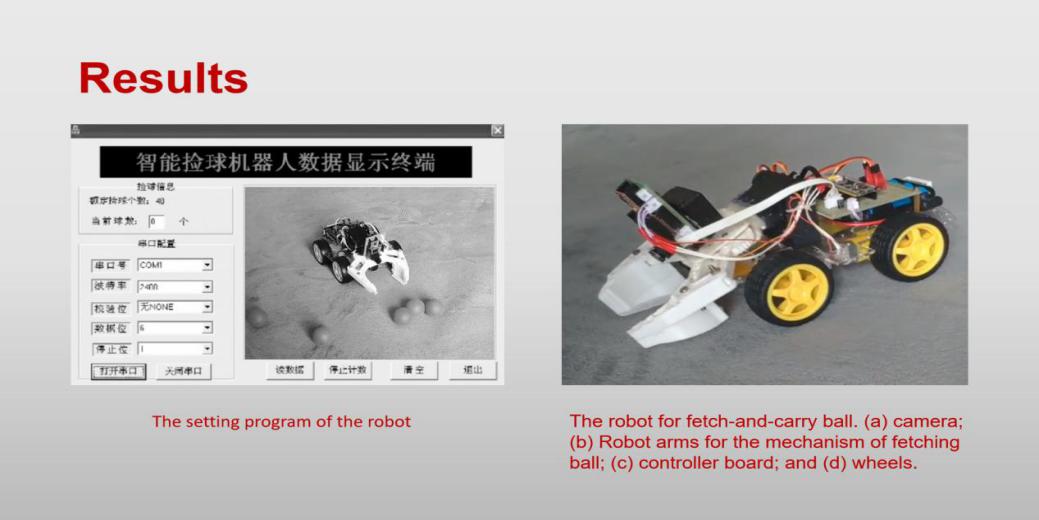
It is notable to find a clear presentation in the program in PC for parameter settings in the controller terminal. The user-machine interface is user friendly to design a clear-cut and reasonable model for the robot. The right side is the robot for fetch-and-carry ball. There are 4 parts, (a) camera; (b) Robot arms for the mechanism of fetching ball; (c) controller board; and (d) wheels. | |
| [Go to Next Slide] |