 IEEE/ICACT20220144 Slide.14
[Big Slide]
Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20220144 Slide.14
[Big Slide]
| Oral Presentation |
|
|
|
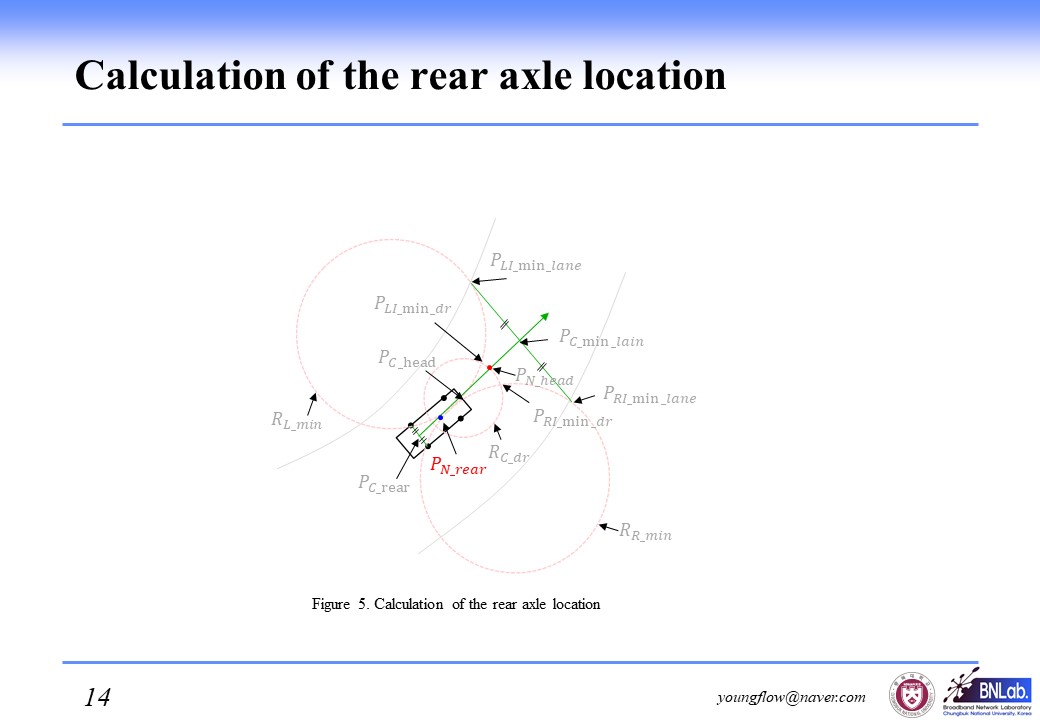
When the vehicles move in the direction of Pn_head position, it is necessary to calculate the position of the rear axle. Because trajectory algorithm is calculated based on rear axle. rear axle location ( Pn_rear) is calculated considering driving radius and yaw angle with respect to the global coordinates. | |
| [Go to Next Slide] |