 IEEE/ICACT20210198 Slide.15
[Big Slide]
Oral Presentation
| Virual Oral Presentation Slide by Slide |
|
IEEE/ICACT20210198 Slide.15
[Big Slide]
| Oral Presentation |
|
|
|
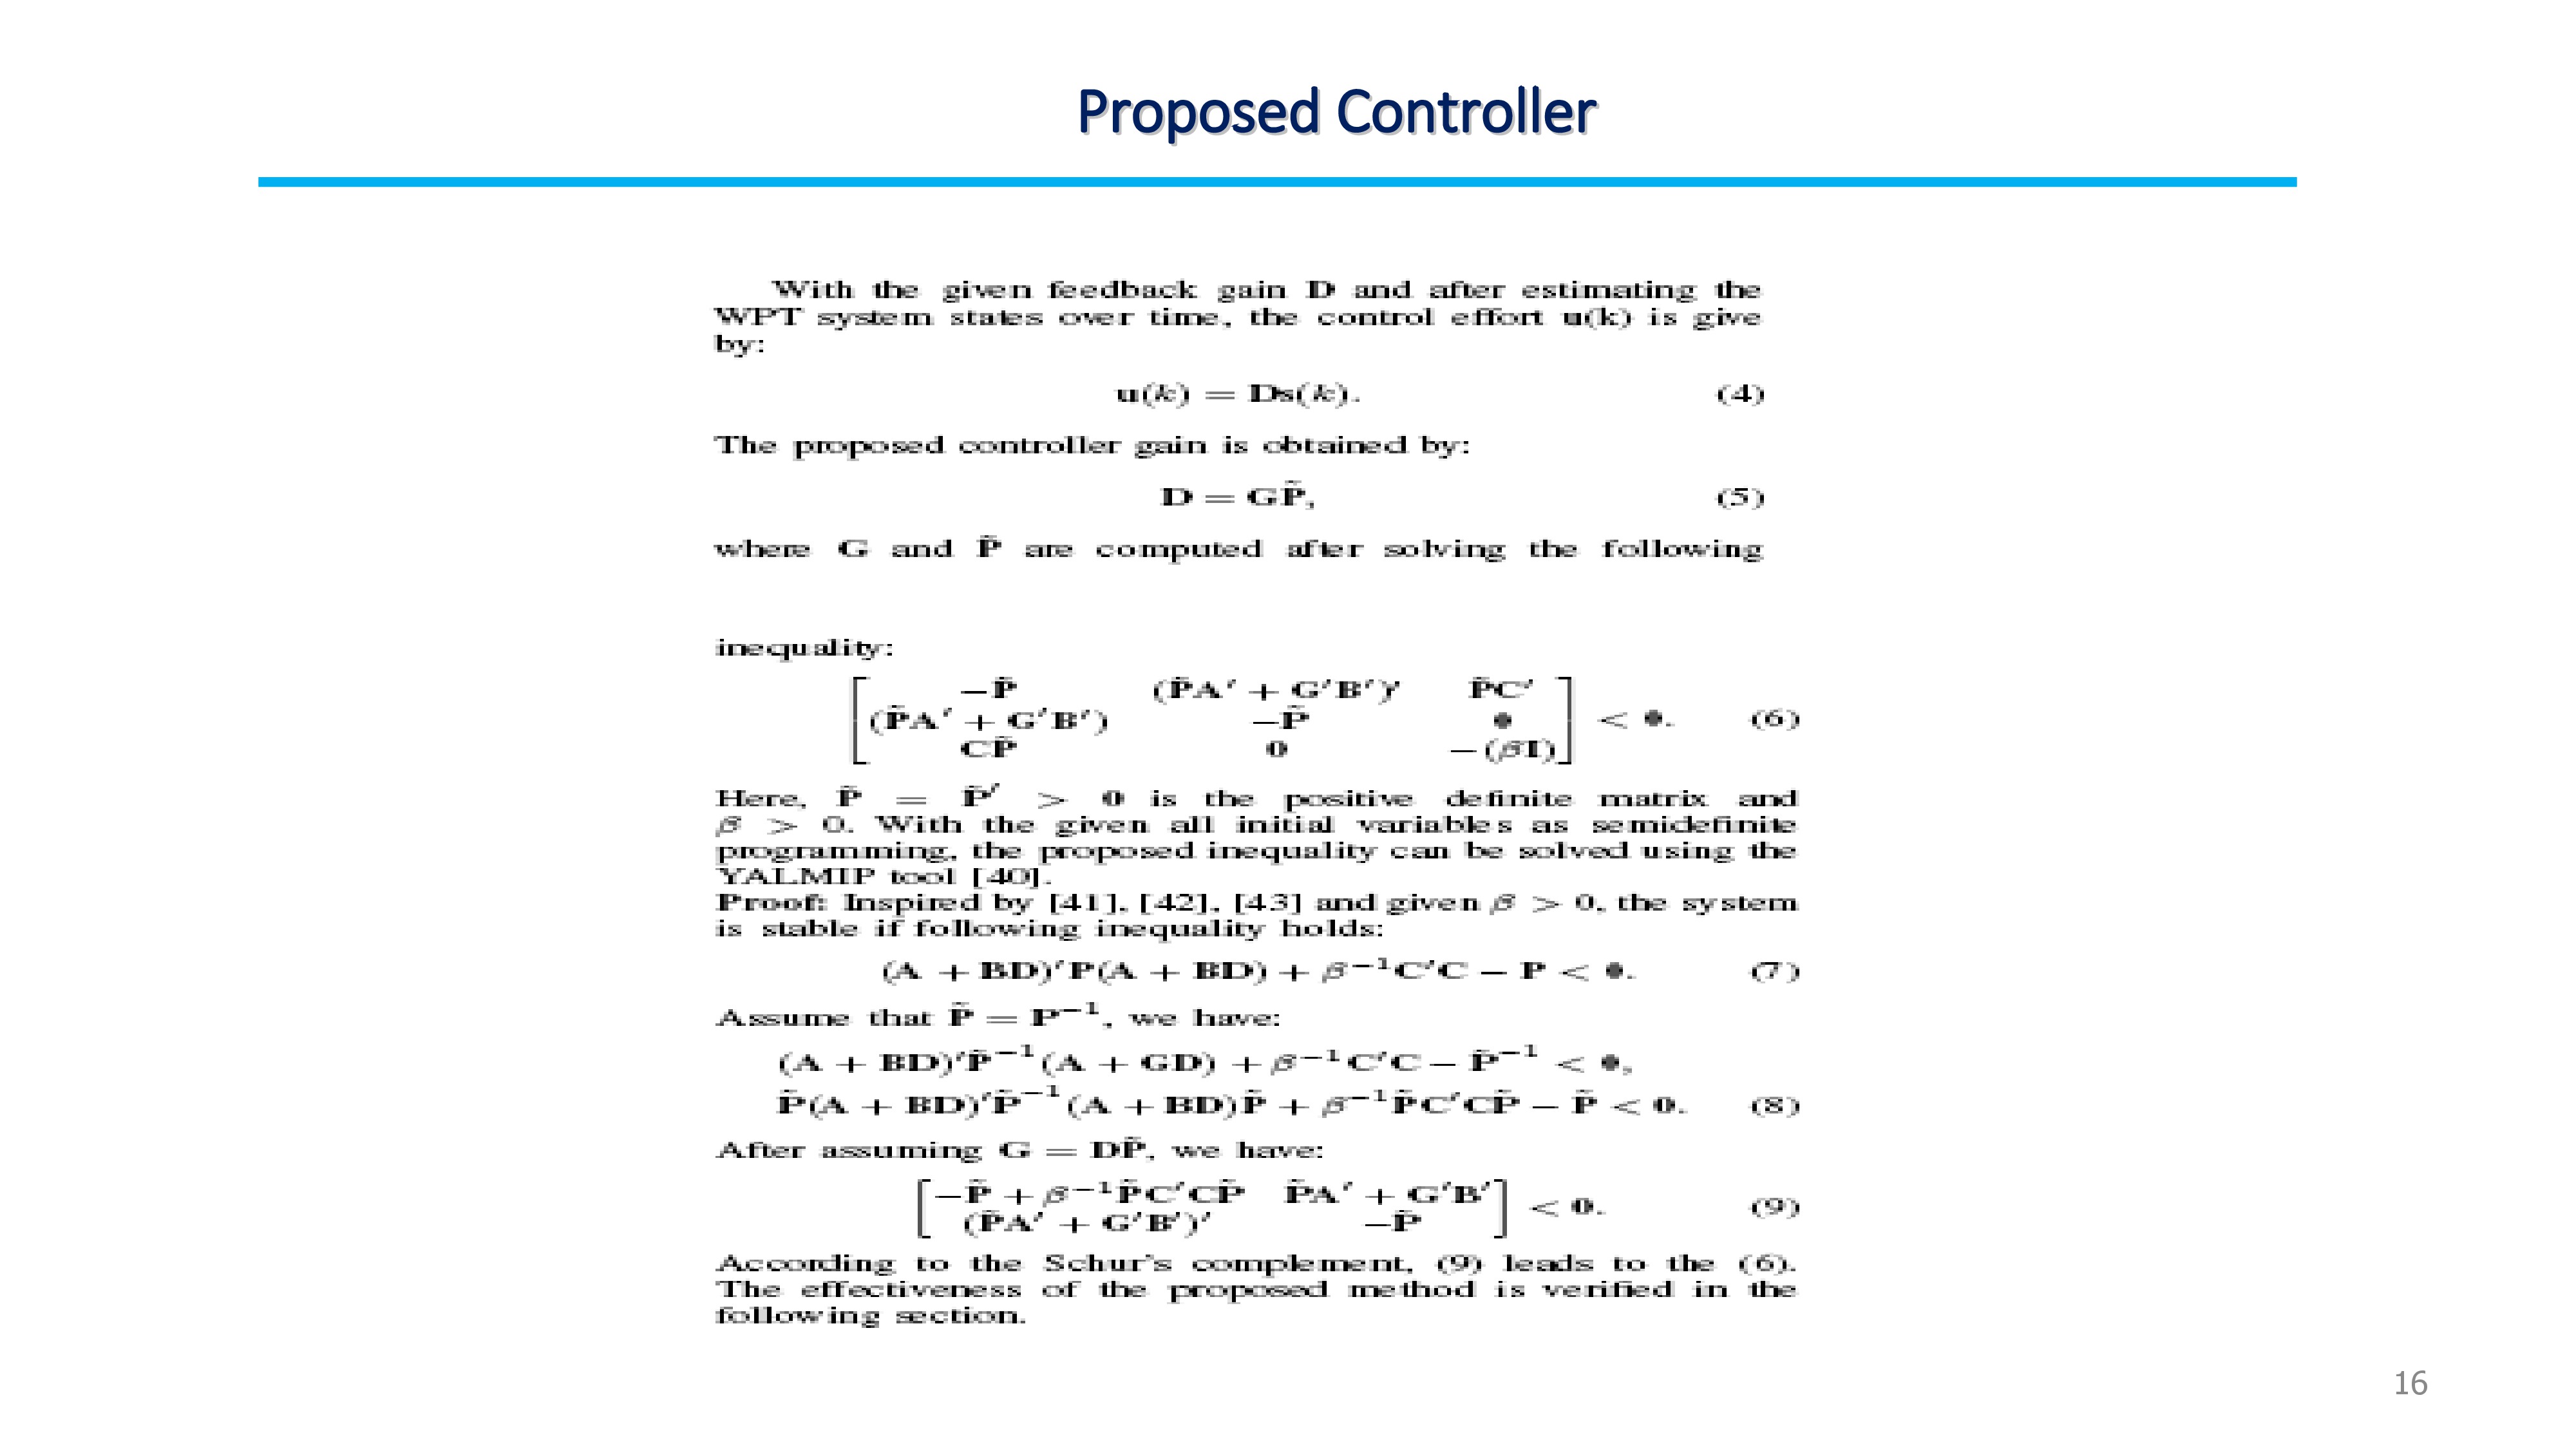
Proposed Controller With the given feedback gain D and after estimating the WPT system states over time, the control effort u(k) is give by After soling this equation we will get controller gain. | |
| [Go to Next Slide] |