 |
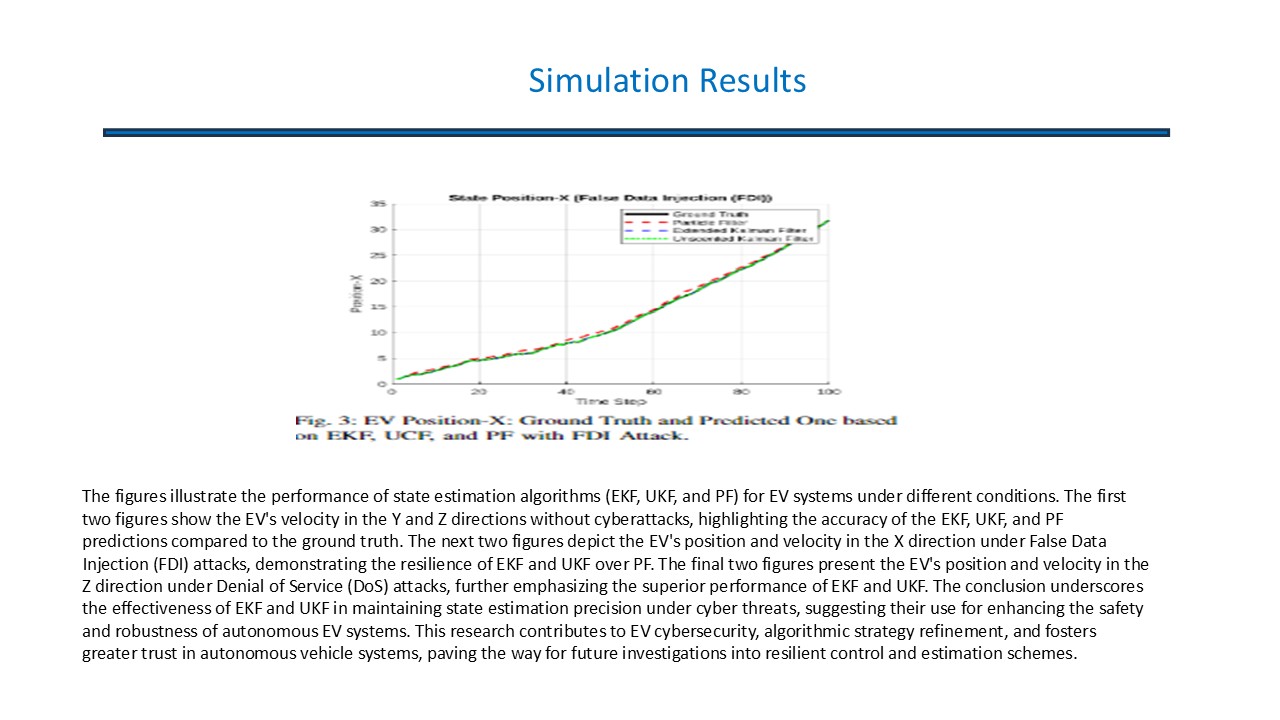
The figures illustrate the performance of state estimation algorithms (EKF, UKF, and PF) for EV systems under different conditions. The first two figures show the EV's velocity in the Y and Z directions without cyberattacks, highlighting the accuracy of the EKF, UKF, and PF predictions compared to the ground truth. The next two figures depict the EV's position and velocity in the X direction under False Data Injection (FDI) attacks, demonstrating the resilience of EKF and UKF over PF. The final two figures present the EV's position and velocity in the Z direction under Denial of Service (DoS) attacks, further emphasizing the superior performance of EKF and UKF. The conclusion underscores the effectiveness of EKF and UKF in maintaining state estimation precision under cyber threats, suggesting their use for enhancing the safety and robustness of autonomous EV systems. This research contributes to EV cybersecurity, algorithmic strategy refinement, and fosters greater trust in autonomous vehicle systems, paving the way for future investigations into resilient control and estimation schemes.
|
 IEEE/ICACT20250208 Slide.15
[Big Slide]
[YouTube]