 ICACT20210135 Slide.19
[Big slide for presentation] |
Chrome Text-to-Speach Click!! |
 |
Thank you
|
|
ICACT20210135 Slide.18
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
 |
This is references.
|
|
ICACT20210135 Slide.17
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
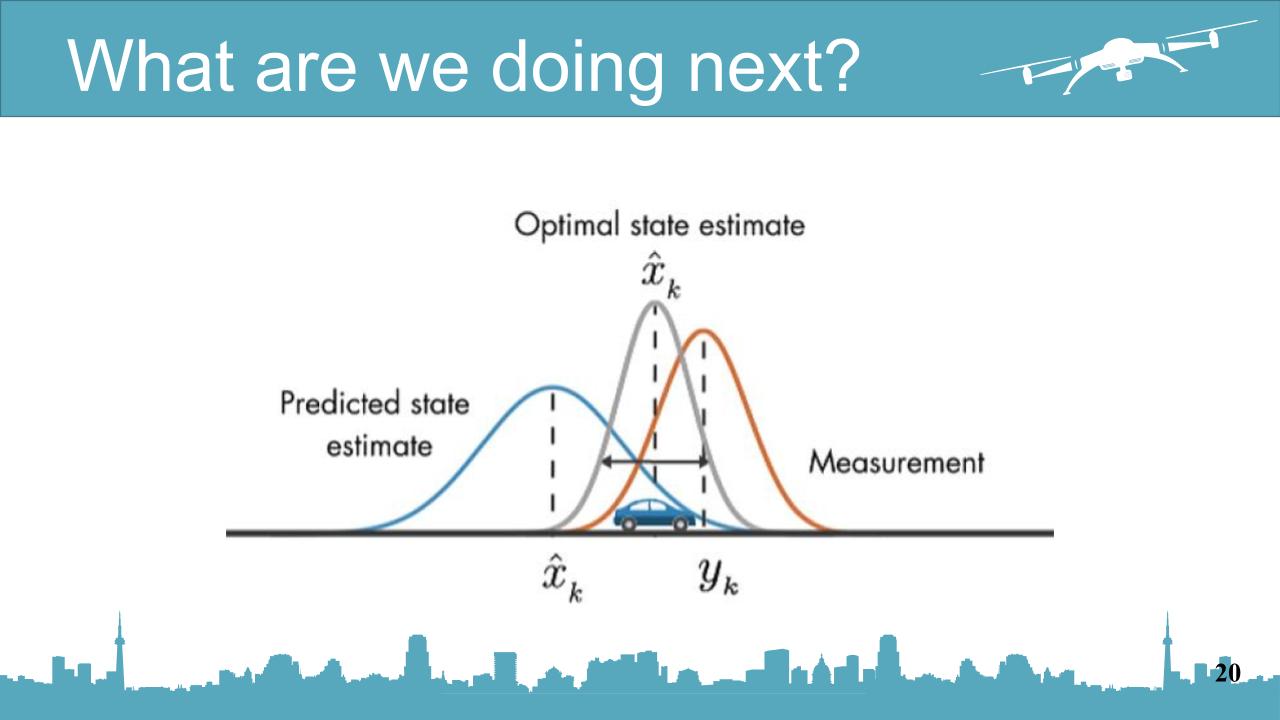 |
We have realized that in the real world, positioning the UAV there are no API as we use right now.
we have to use GPS to localize the target UAV
and GPS have an error.
We decided to improve our work in our next work.
|
|
ICACT20210135 Slide.16
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
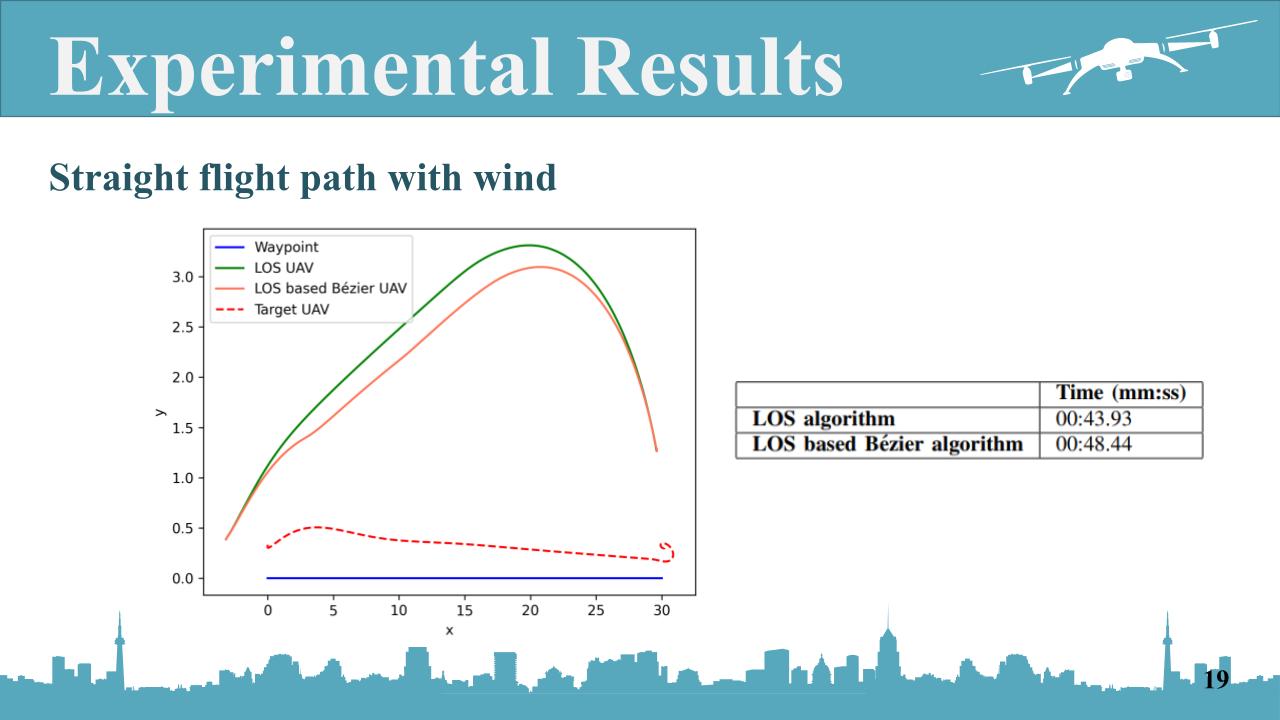 |
The last one, the straight flight path with wind.
We added the wind to the north direction or along the y-axis with speed 6 m/s.
Even with the wind, our proposed method is still better.
|
|
ICACT20210135 Slide.15
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
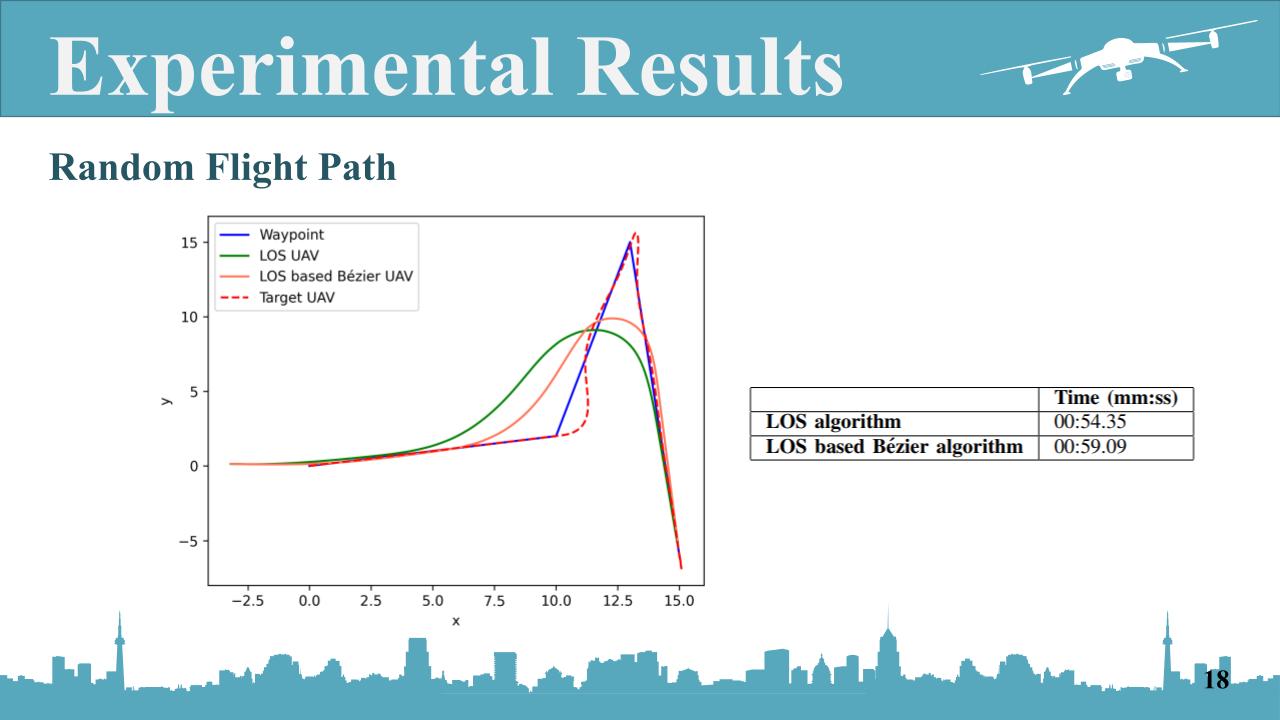 |
For the Random flight path,
Same kind of result here
As u can see our new algorithm provides the better performance than only LOS method, even use more time.
|
|
ICACT20210135 Slide.14
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
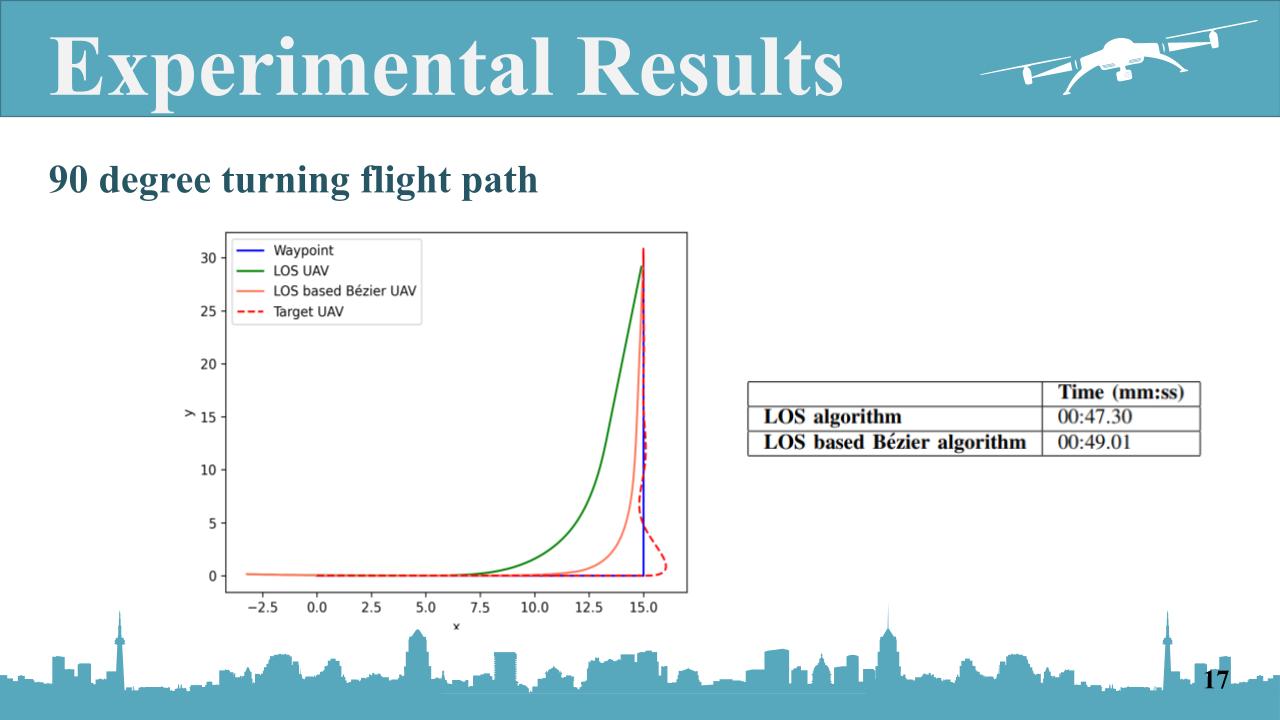 |
For the 90 degree turning flight path
This is the result we got.
The blue line is the waypoint for the target UAV
and the dash line is the actual path of the target UAV which moving along the waypoint
the orange line is the follower UAV which using the proposed method to follow the target
and the green line is the follower UAV as well but use conventional method
as you can see, our proposed algorithm which is orange line is better than the convention method which is the orange line
but however, our proposed algorithm spends more time than the conventional method
|
|
ICACT20210135 Slide.13
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
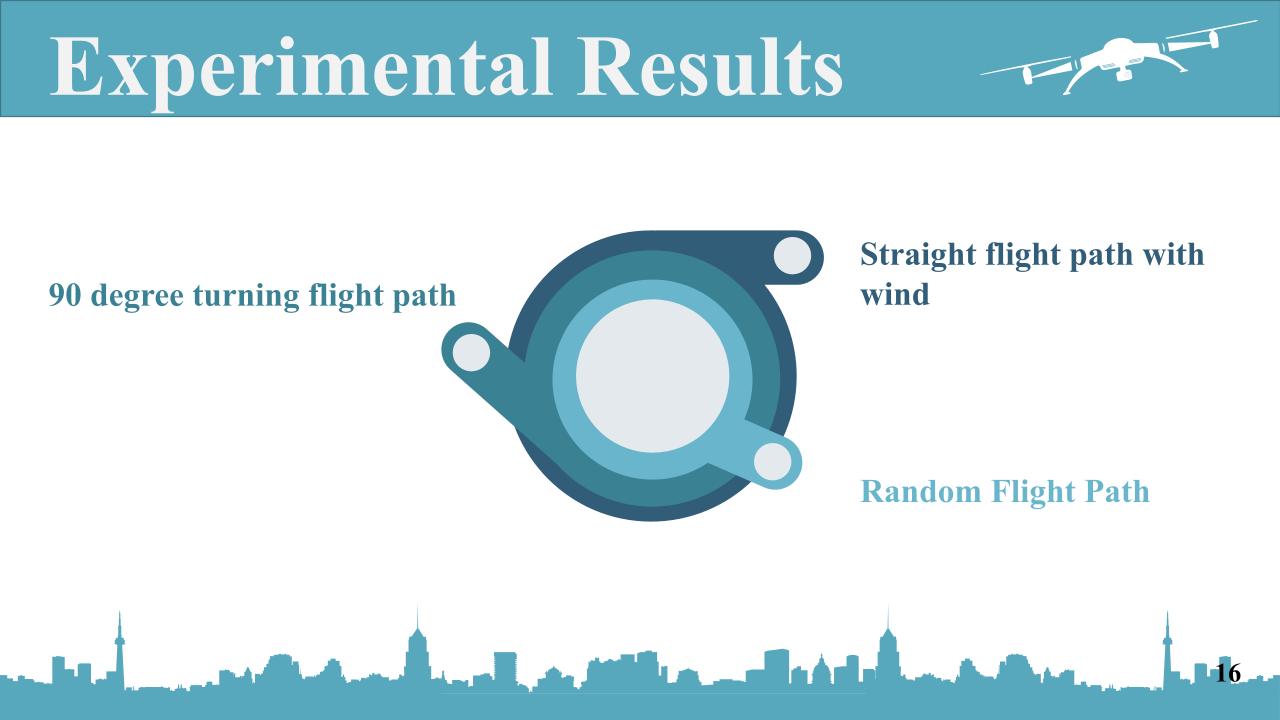 |
For the experimental results, we were doing 3 different cas of experiment which are
1) the 90-degree turning flight path,
2) straight flight path with the wind,
and 3) random flight path.
and compare the conventional method and the proposed method
|
|
ICACT20210135 Slide.12
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
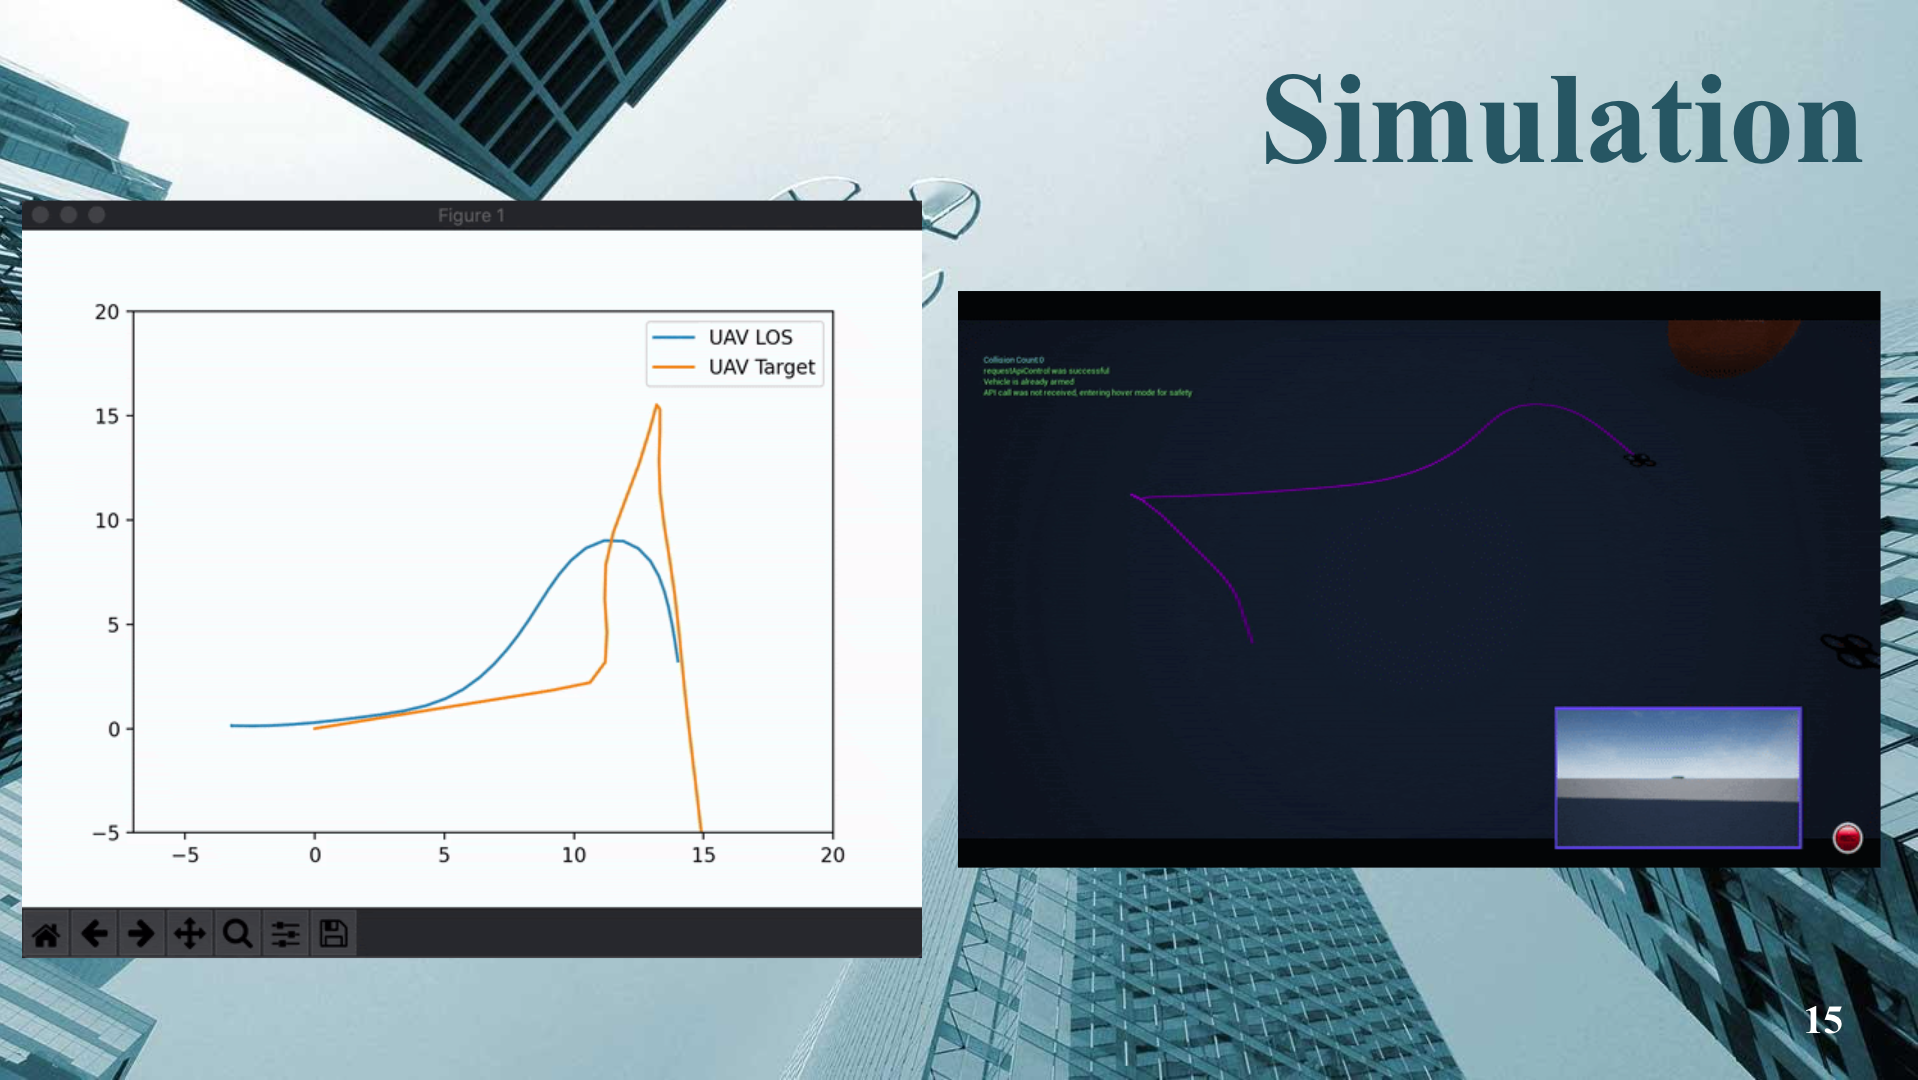 |
This is the video while the simulation is running.
On the right hand side is the windows of the simulation
as u can see there are 2 UAV
the first one is the target moving along waypoint we set by using the flight controller API that we wrote in python
the second one is the follower UAV try to follow the target by using own algorithm
|
|
ICACT20210135 Slide.11
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
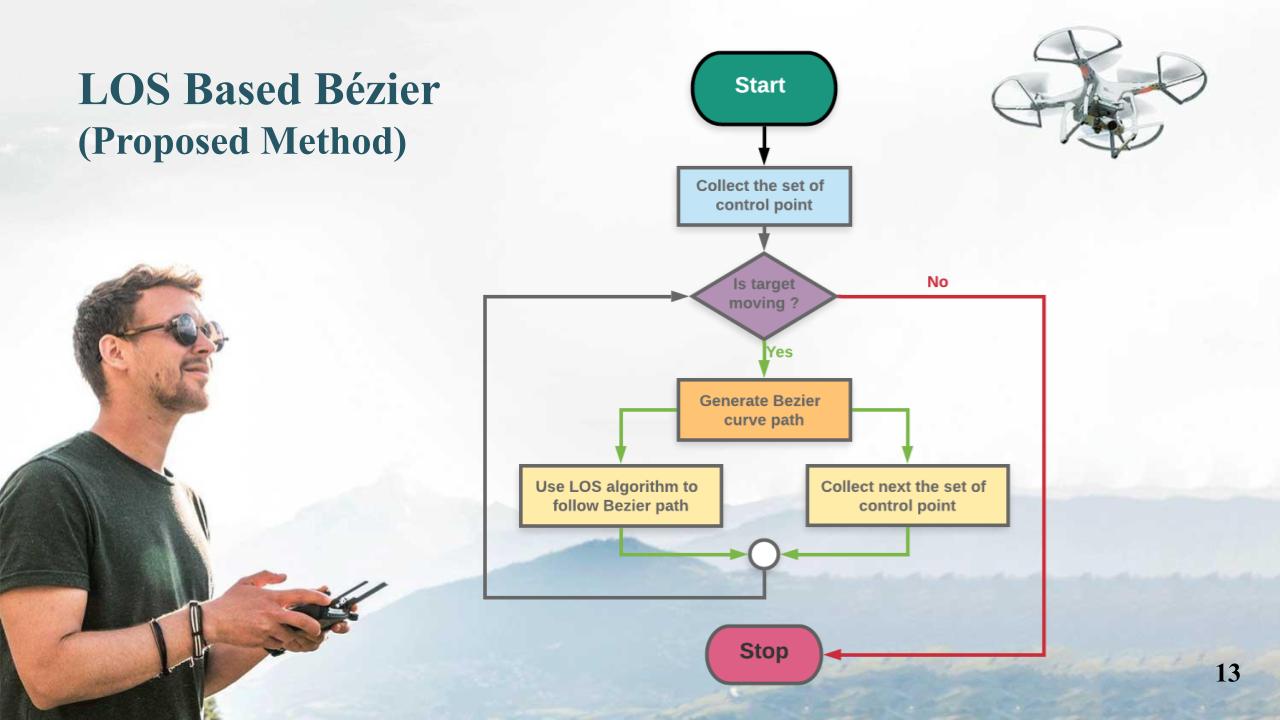 |
Another method is proposed method called LOS based bezier.
and this is the flowchart of the method we created
Start with collecting the set of control point which is the set of position that target has been through
then we check if target is moving
then generate the Bezier curve path from those data,
then use LOS technique to command the UAV to follow the path
at the same time we collect the next set of control point to use in the next loop.
|
|
ICACT20210135 Slide.10
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
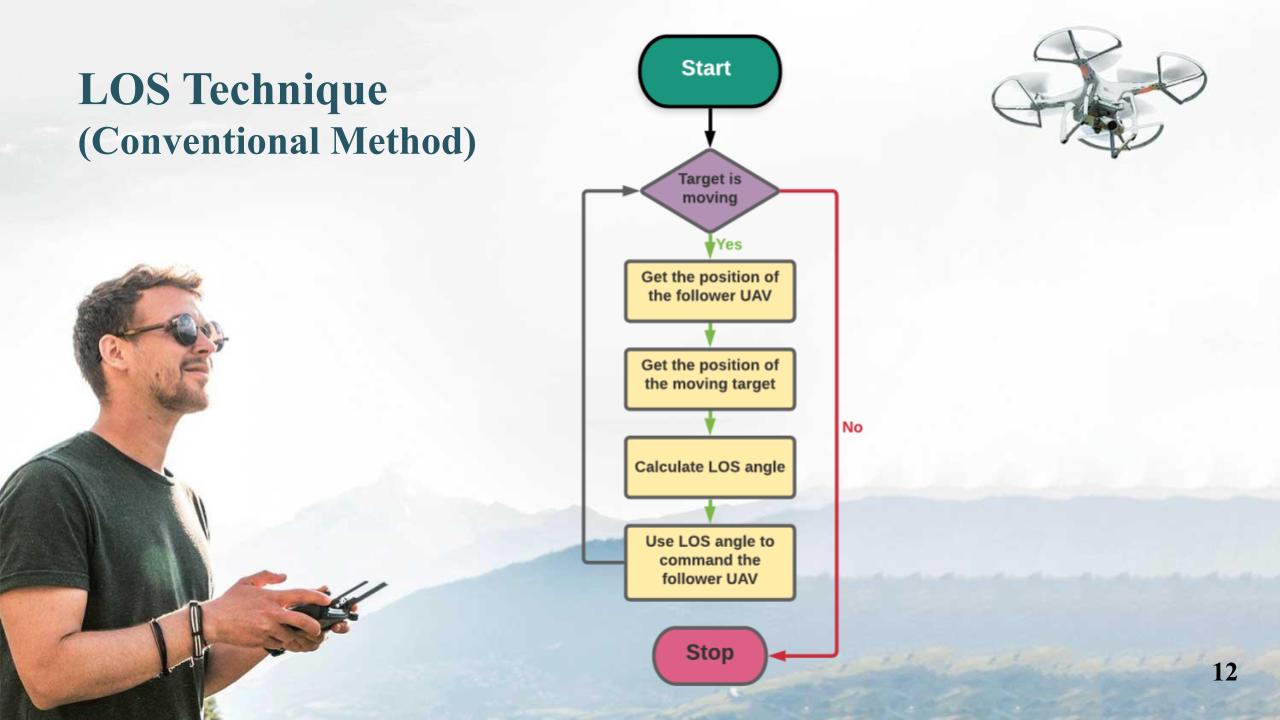 |
The first one is conventional method we call LOS technique which use LOS guidance law only.
And this is the flowchart of LOS algorithms what people usually do.
Start with check if target is moving if it moving, we get the position of follower UAV in this we used flight controller API and then get the position of the target.
then those information to calculate the LOS angle by using the LOS theory.
then use the LOS angle to command the UAV to follow the target.
|
|
ICACT20210135 Slide.09
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
 |
According to aim of the project, there are 2 Methods.
|
|
ICACT20210135 Slide.08
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
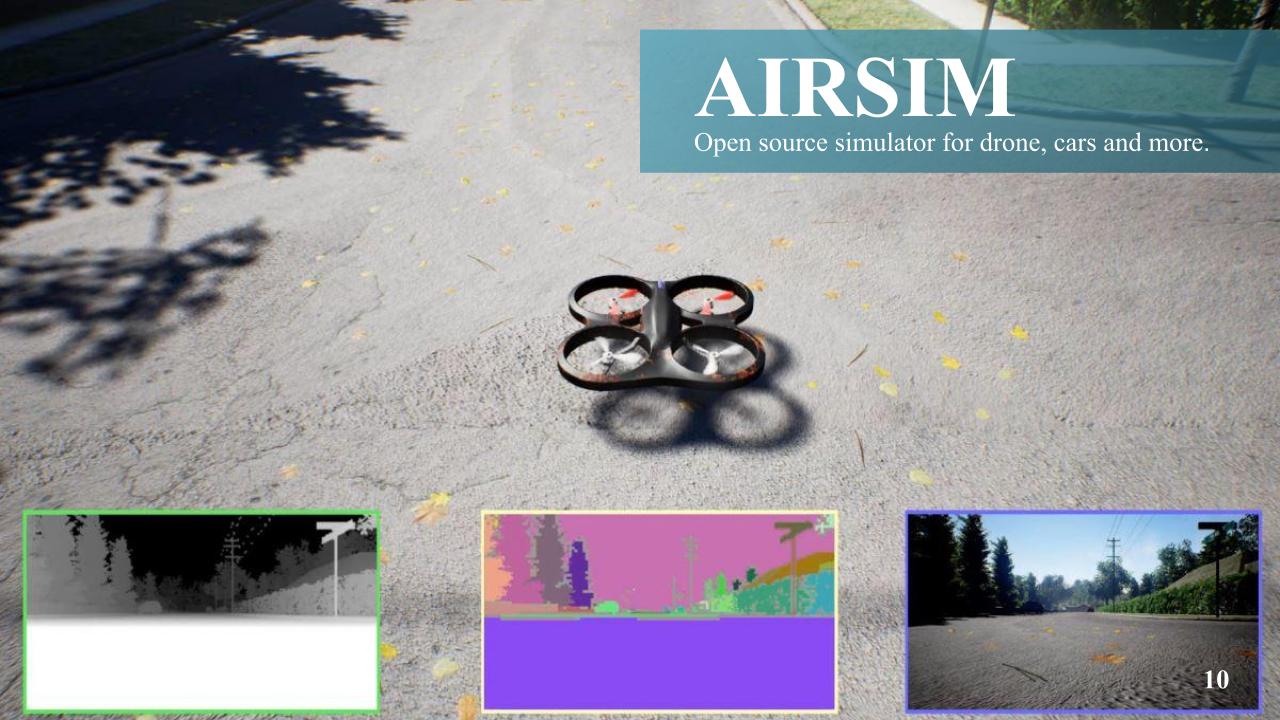 |
AirSim is used to be the simulator for this work
and we used AirSim API to control the UAV inside the simulation which available in many programming language such as python, C, and Javascript.
|
|
ICACT20210135 Slide.07
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
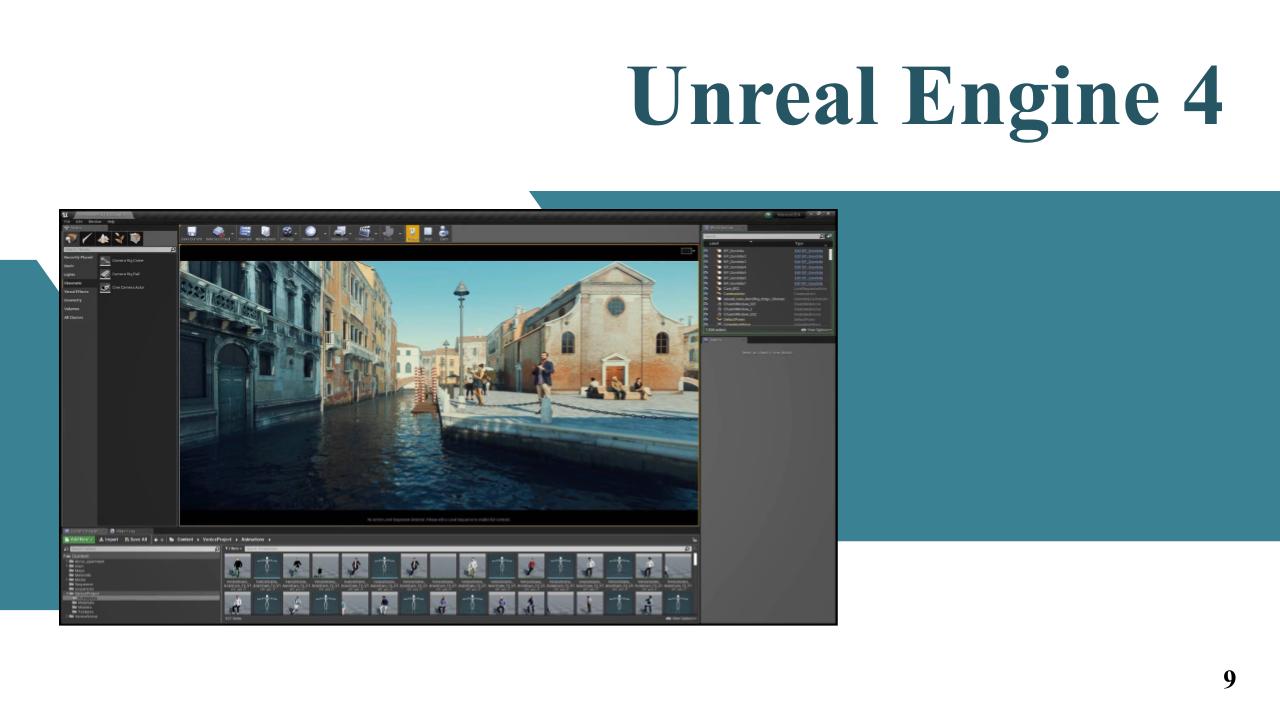 |
Unreal engine is the most open and advanced real-time 3D creation platform. We used Unreal Engine for run the simulation.
|
|
ICACT20210135 Slide.06
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
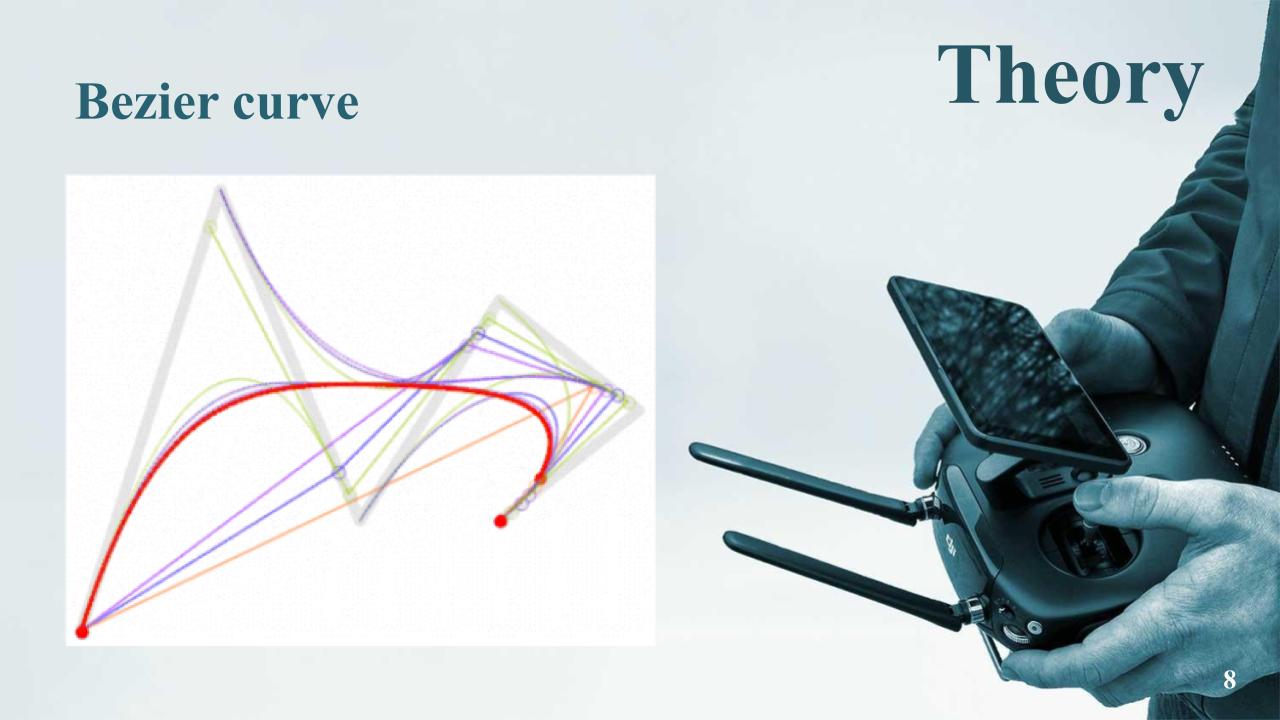 |
The example of Bezier path planning.
|
|
ICACT20210135 Slide.05
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
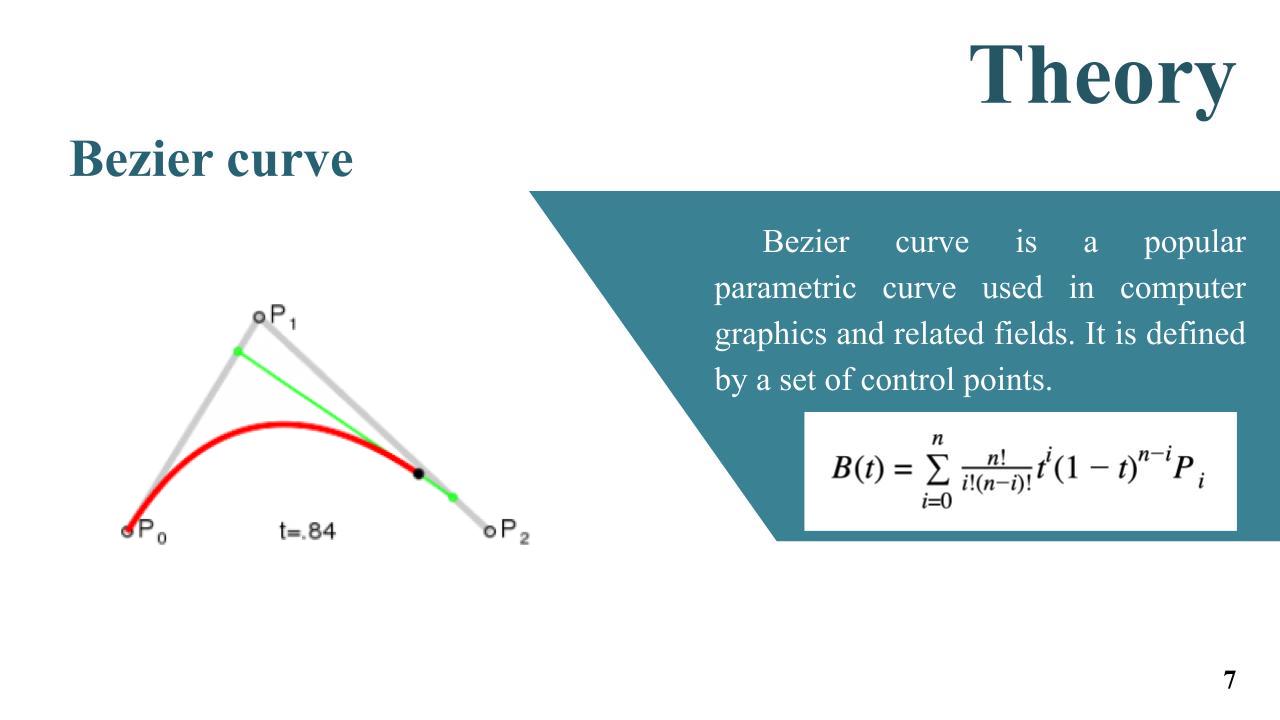 |
Bezier curve is popular parametric curve used in computer graphics and path planning fields. Bezier curve is parametric curve calculated from set of control point which is P0, P1, and P2 in this example. We used it to be path planning method for the UAV by let the point that target has been through to be set of control point and use this theory to generate the path.
|
|
ICACT20210135 Slide.04
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
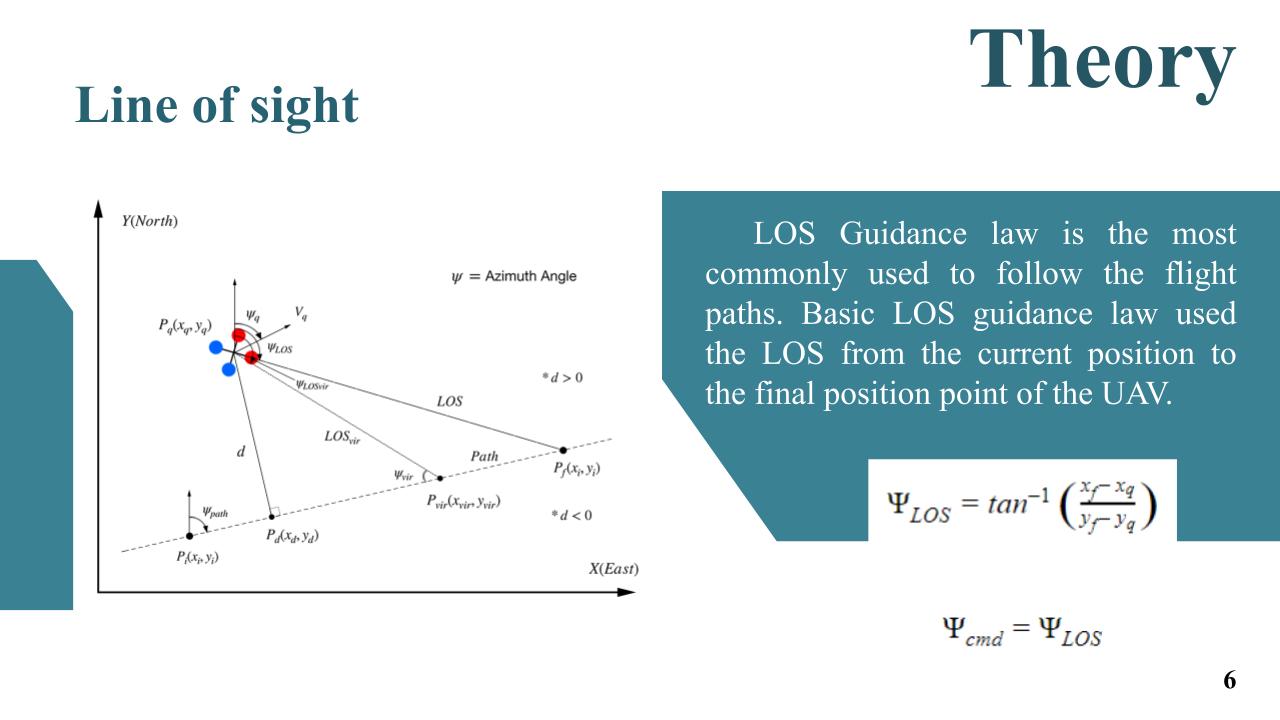 |
Line of Sight guidance law theory is simply, which you can localize your own position and target position you can calculate the LOS angle from this simple equation. So positioning is quite import too. And we use line of sight angle to be command angle of UAV to guide the UAV.
|
|
ICACT20210135 Slide.03
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
 |
So we studied about line of sight guidance law, bezier curve, unreal engine and airsim plugin.
|
|
ICACT20210135 Slide.02
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
 |
So we decided to adapting a guidance law system as Line of Sight and path planning method as Bezier curve to guide a quadrotor to pursue another moving quadrotor in the simulation call AirSim.
|
|
ICACT20210135 Slide.01
[Big slide for presentation]
|
Chrome Text-to-Speach Click!! |
 |
Hi everyone My name is Warunyu Hematulin from Thailand. I'm 20 years old. I'm studying aeronautical engineering at KMITL in Thailand. I hope you enjoy my work.
|
















