 ICACT20250033 Slide.01
[Big Slide] |
Chrome  Click!! |
 |
This is title of our presentation. It seems that it is more related to estimation and control part, actually it is, but it is related to the control of 4 wheel mobile platform, that is part of communication part, That is the reason that we applied to ICACT by taking this subject.
The subtitle is extension from the two stage design to N time scale design for SP system. That is the point we are going to make in the future work.
|
| ICACT20250033 Slide.02
[Big Slide]
|
Chrome Click!! |
 |
This is content we presents today.
|
| ICACT20250033 Slide.03
[Big Slide]
|
Chrome Click!! |
 |
Using the two stage design, the two time scale system can be modeled. So this is first content.
|
| ICACT20250033 Slide.04
[Big Slide]
|
Chrome Click!! |
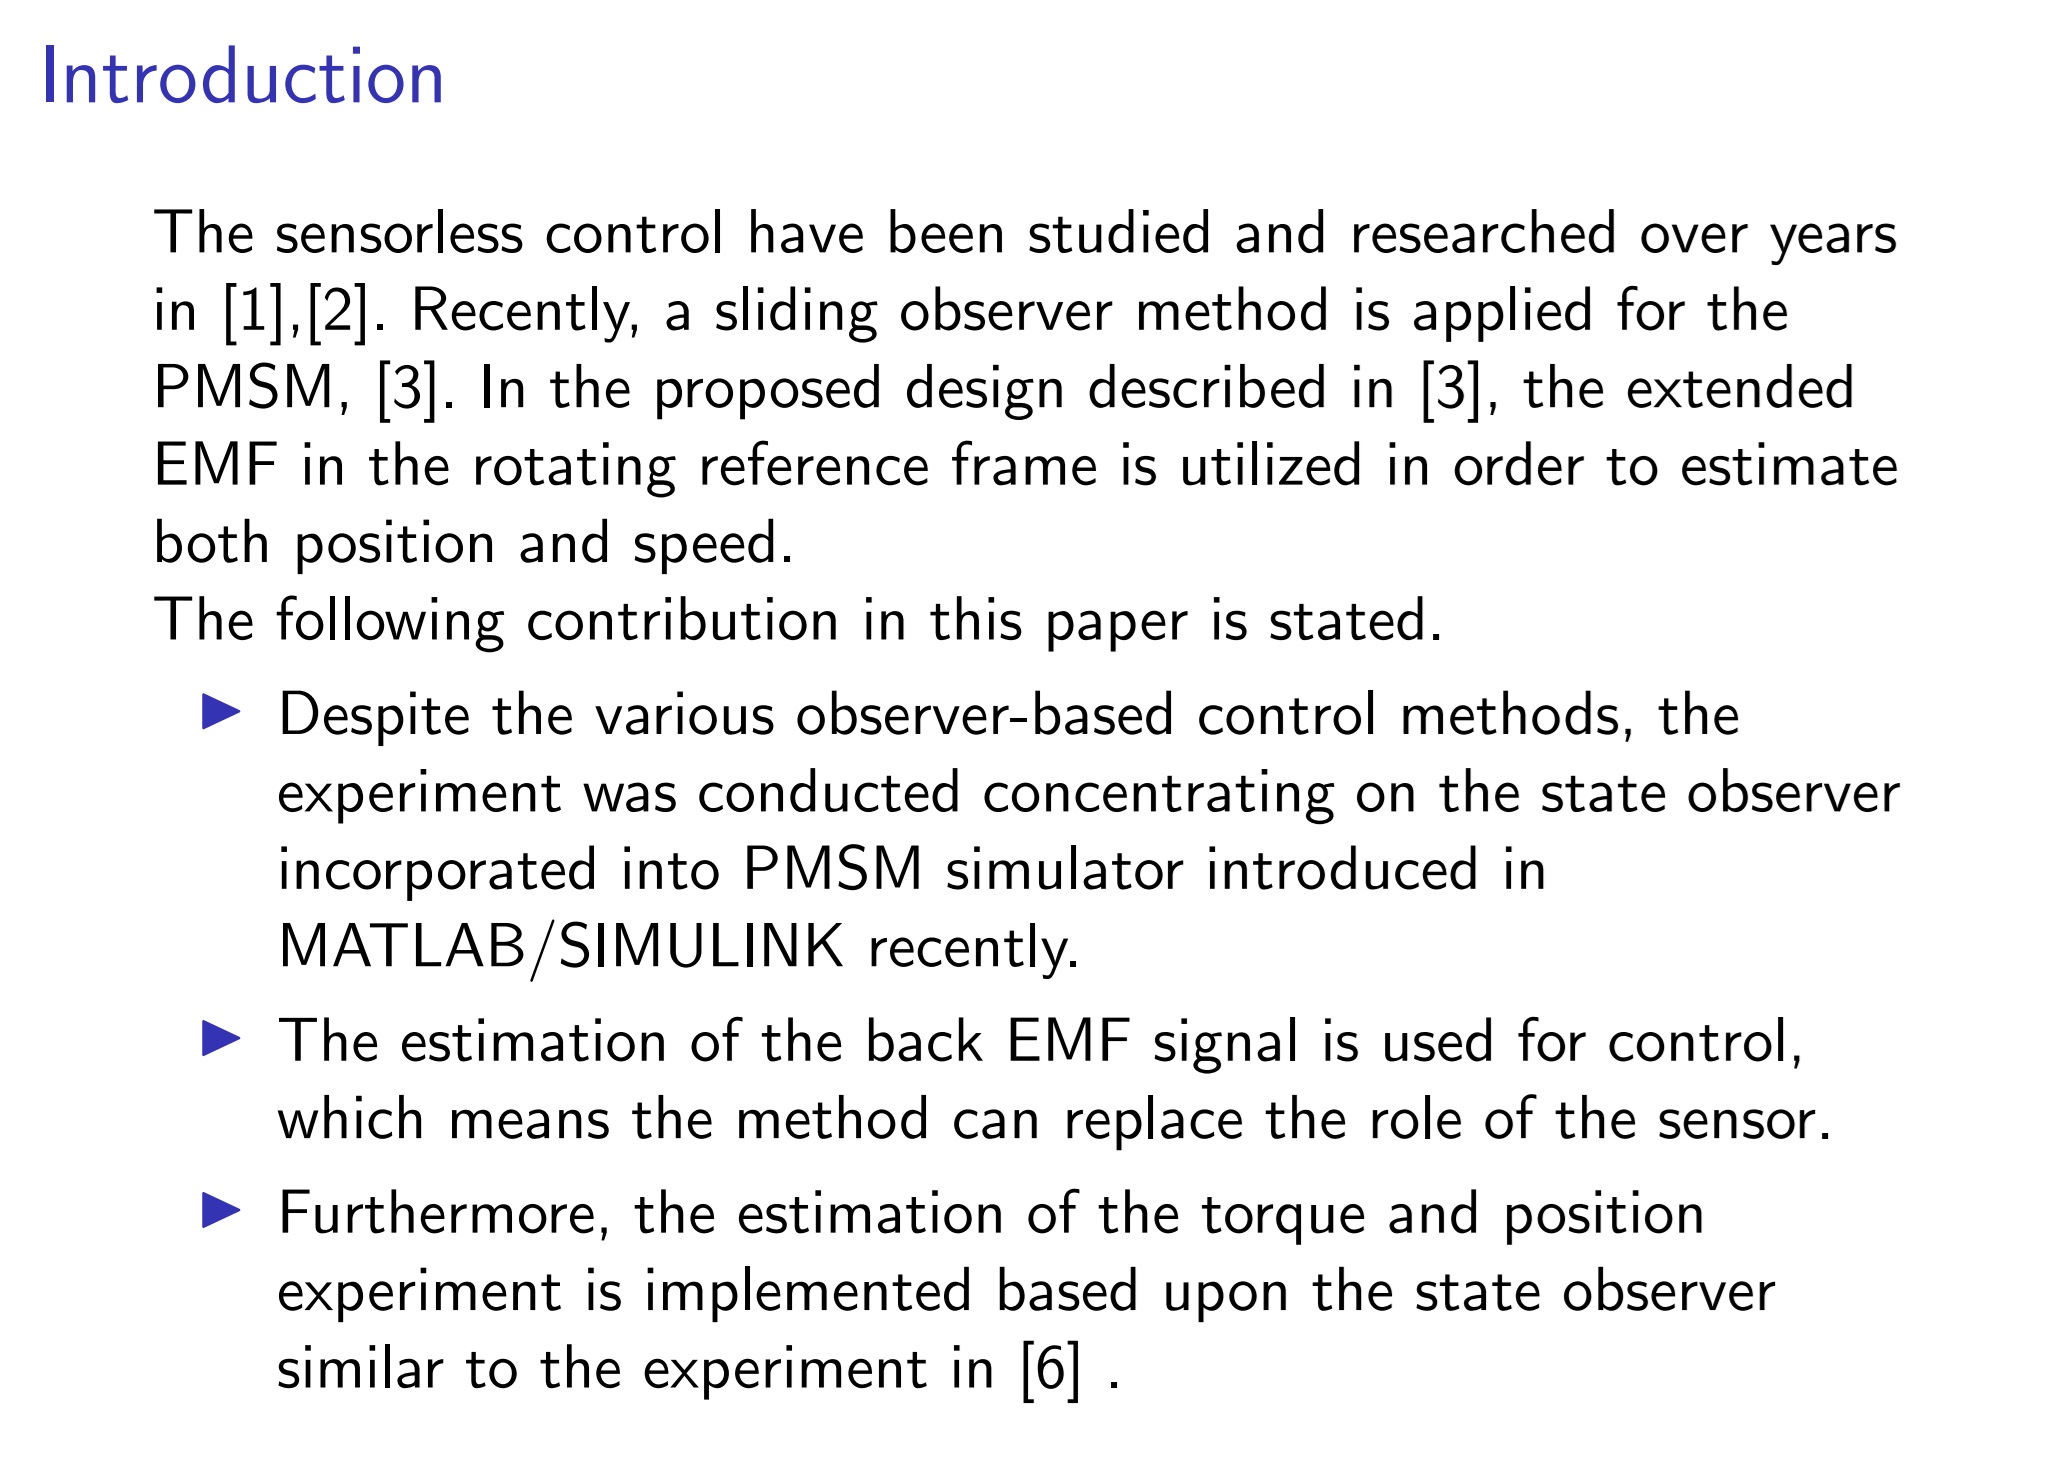 |
Despite the various observer-based control methods, the
experiment was conducted concentrating on the state observer
incorporated into PMSM simulator introduced in
MATLAB/SIMULINK recently.
Also, The estimation of the back EMF signal is used for control,
which means the method can replace the role of the sensor.
Furthermore, the estimation of the torque and position
experiment is implemented based upon the state observer
similar to the experiment in [6] |
| ICACT20250033 Slide.05
[Big Slide]
|
Chrome Click!! |
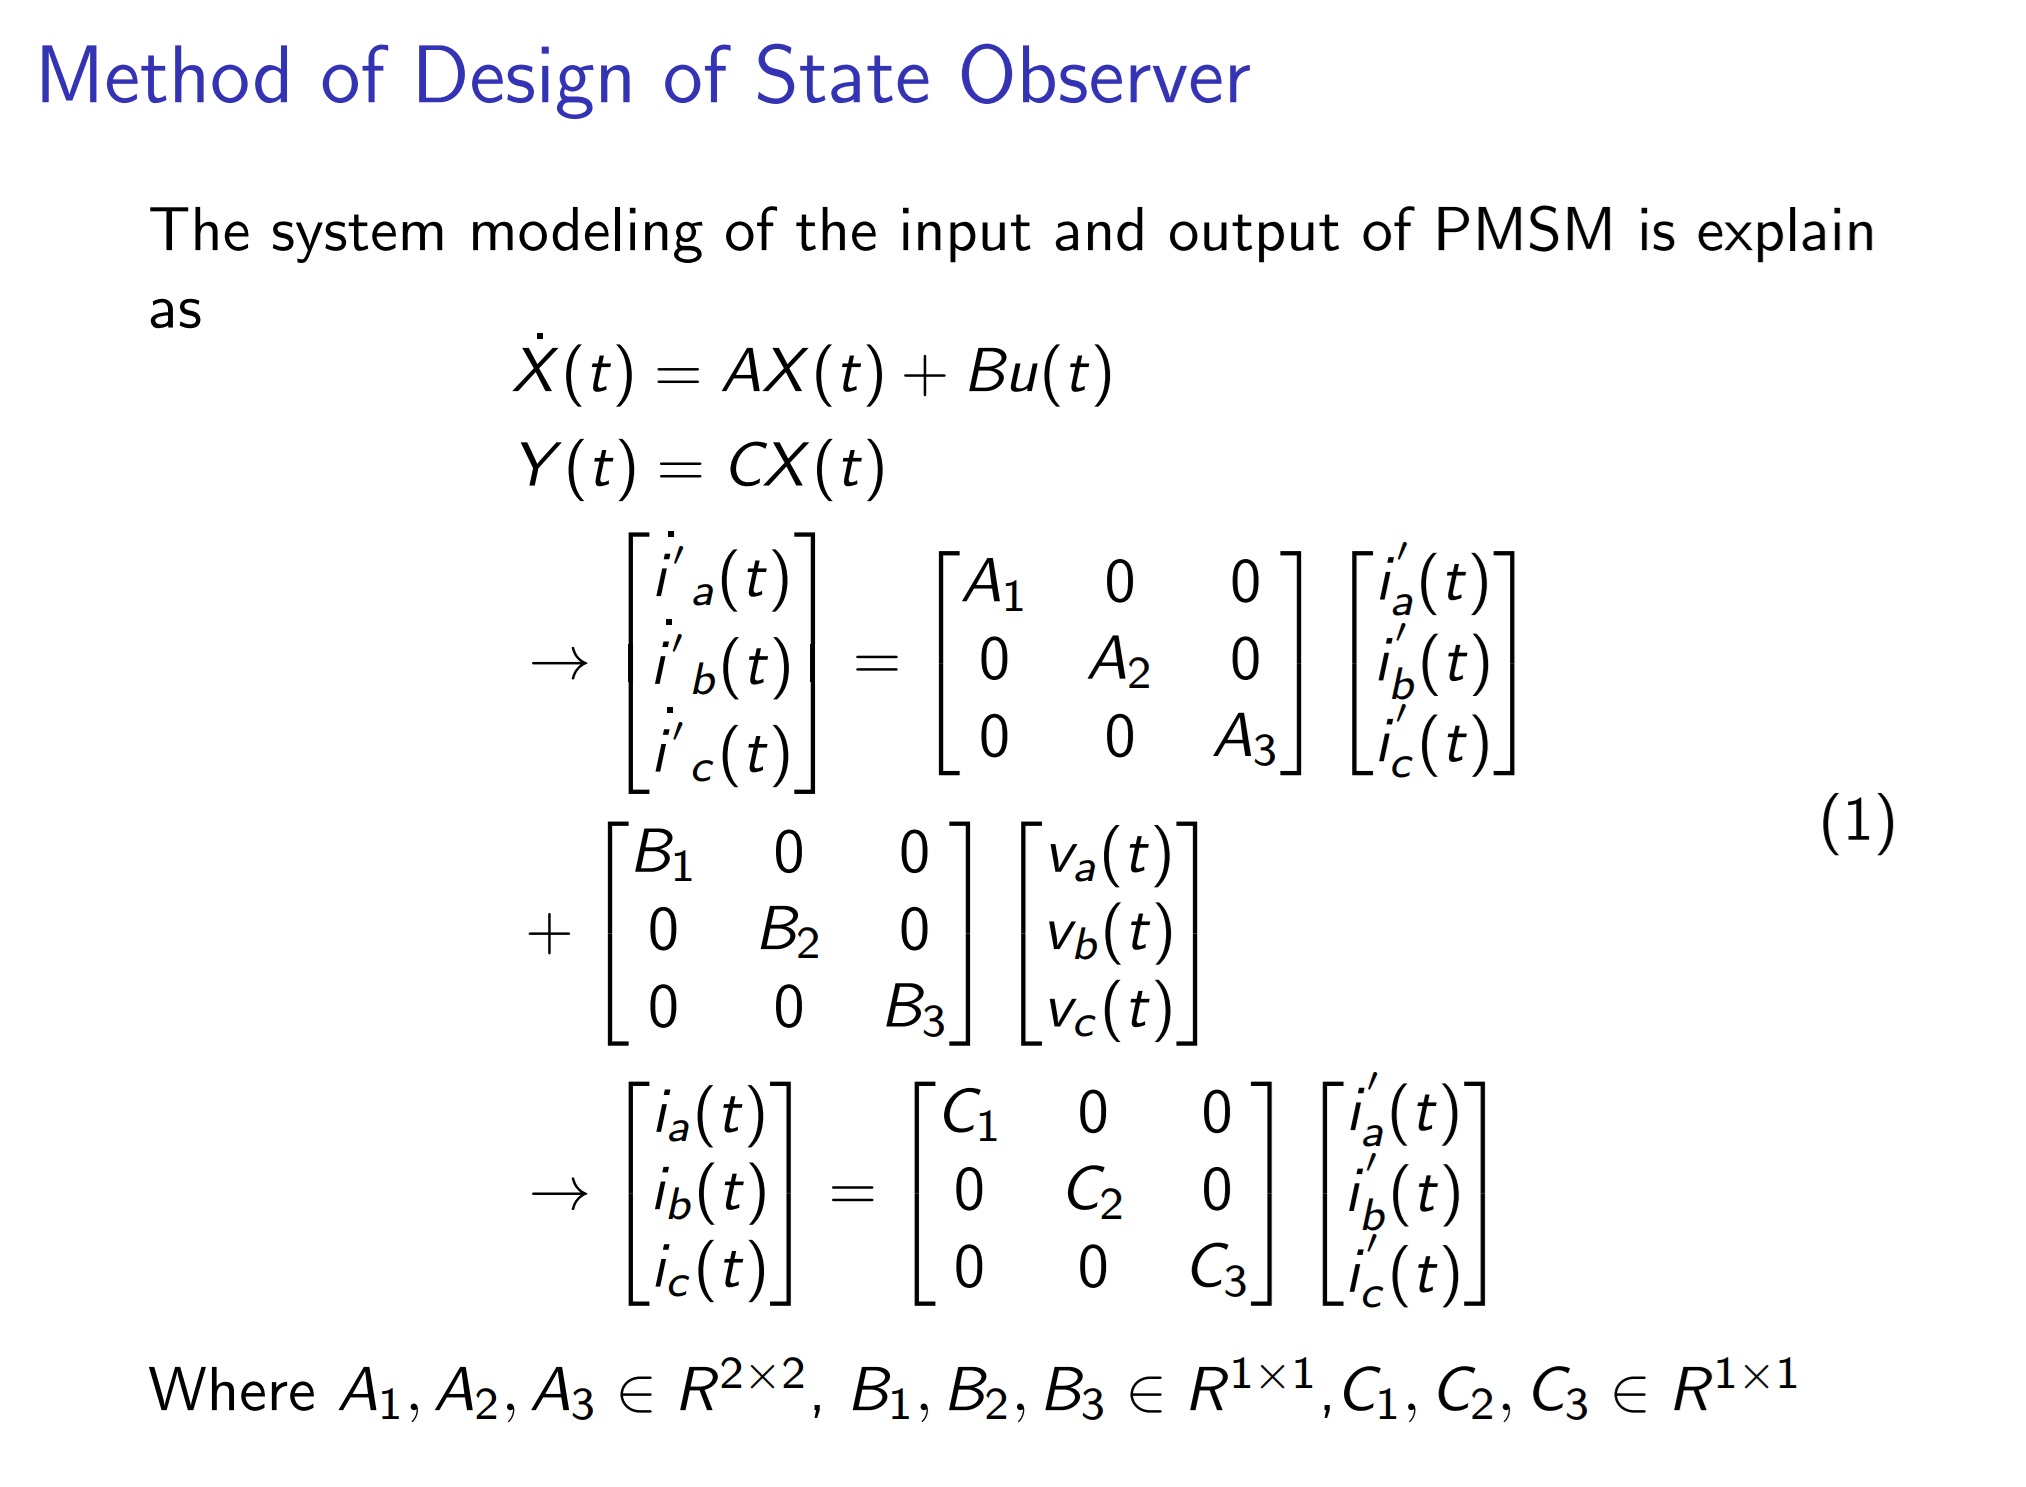 |
The linear time invariant system related to permanent magnet synchronous motors is designed as the following. Furthermore, the system matrices A,B,C,D can be found by matlab transfer function estimation code "tfest". |
| ICACT20250033 Slide.06
[Big Slide]
|
Chrome Click!! |
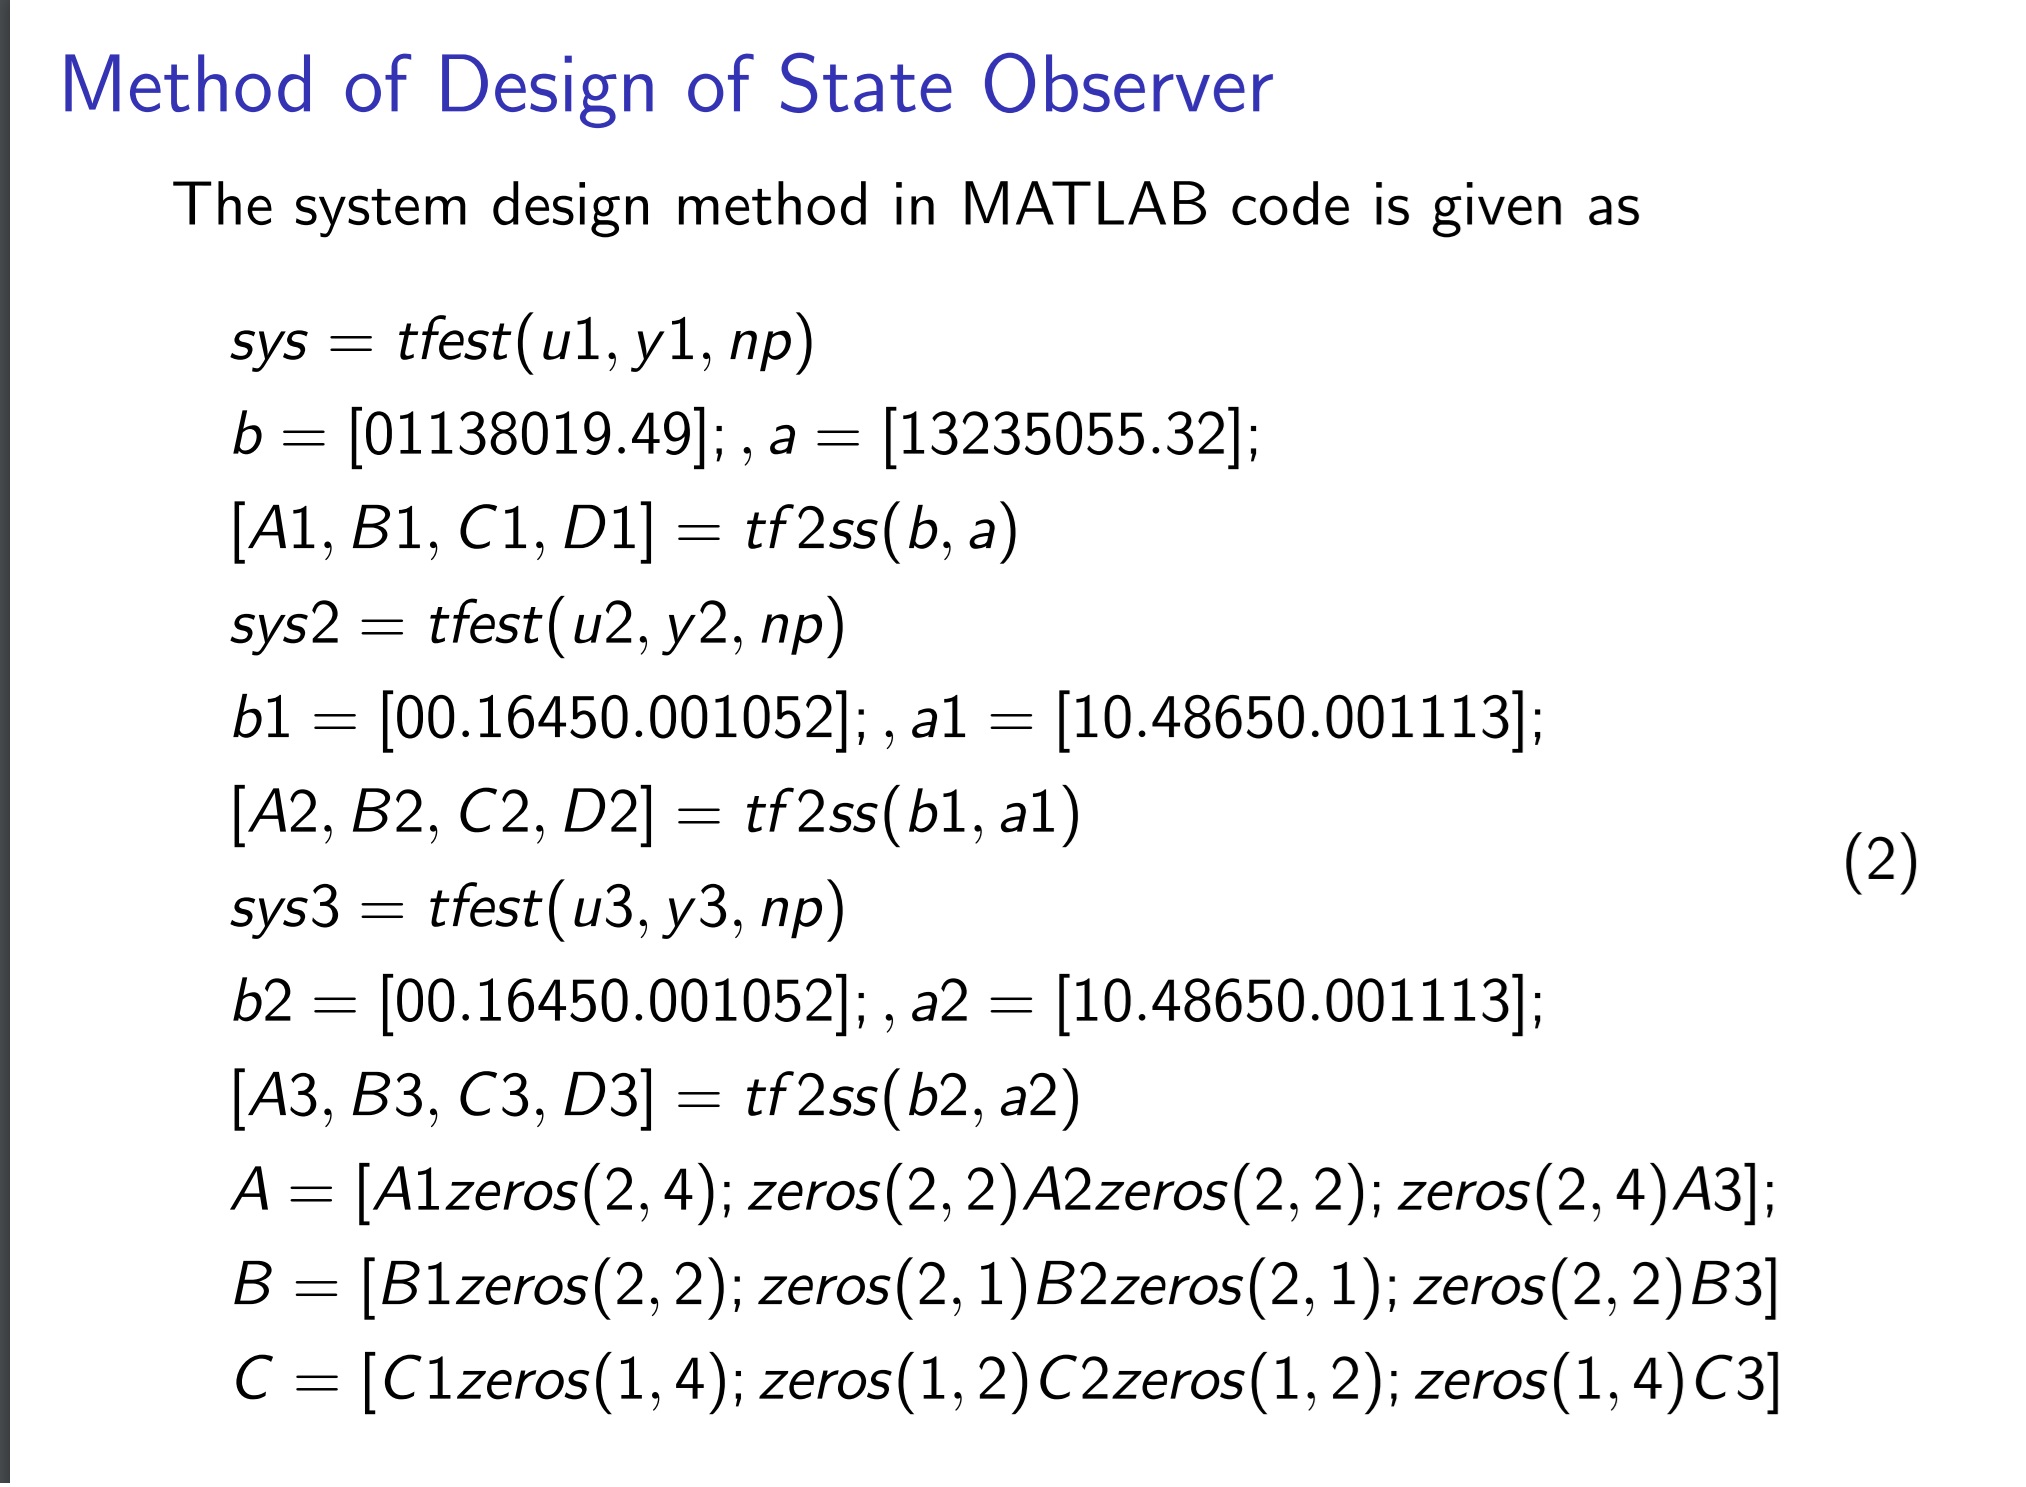 |
This is how we found the system matrices A,B,C,D using tfest code. input u and y implies the PMSM's current and velocities. We found coefficient of each a,b,c phase input and output relations.
|
| ICACT20250033 Slide.07
[Big Slide]
|
Chrome Click!! |
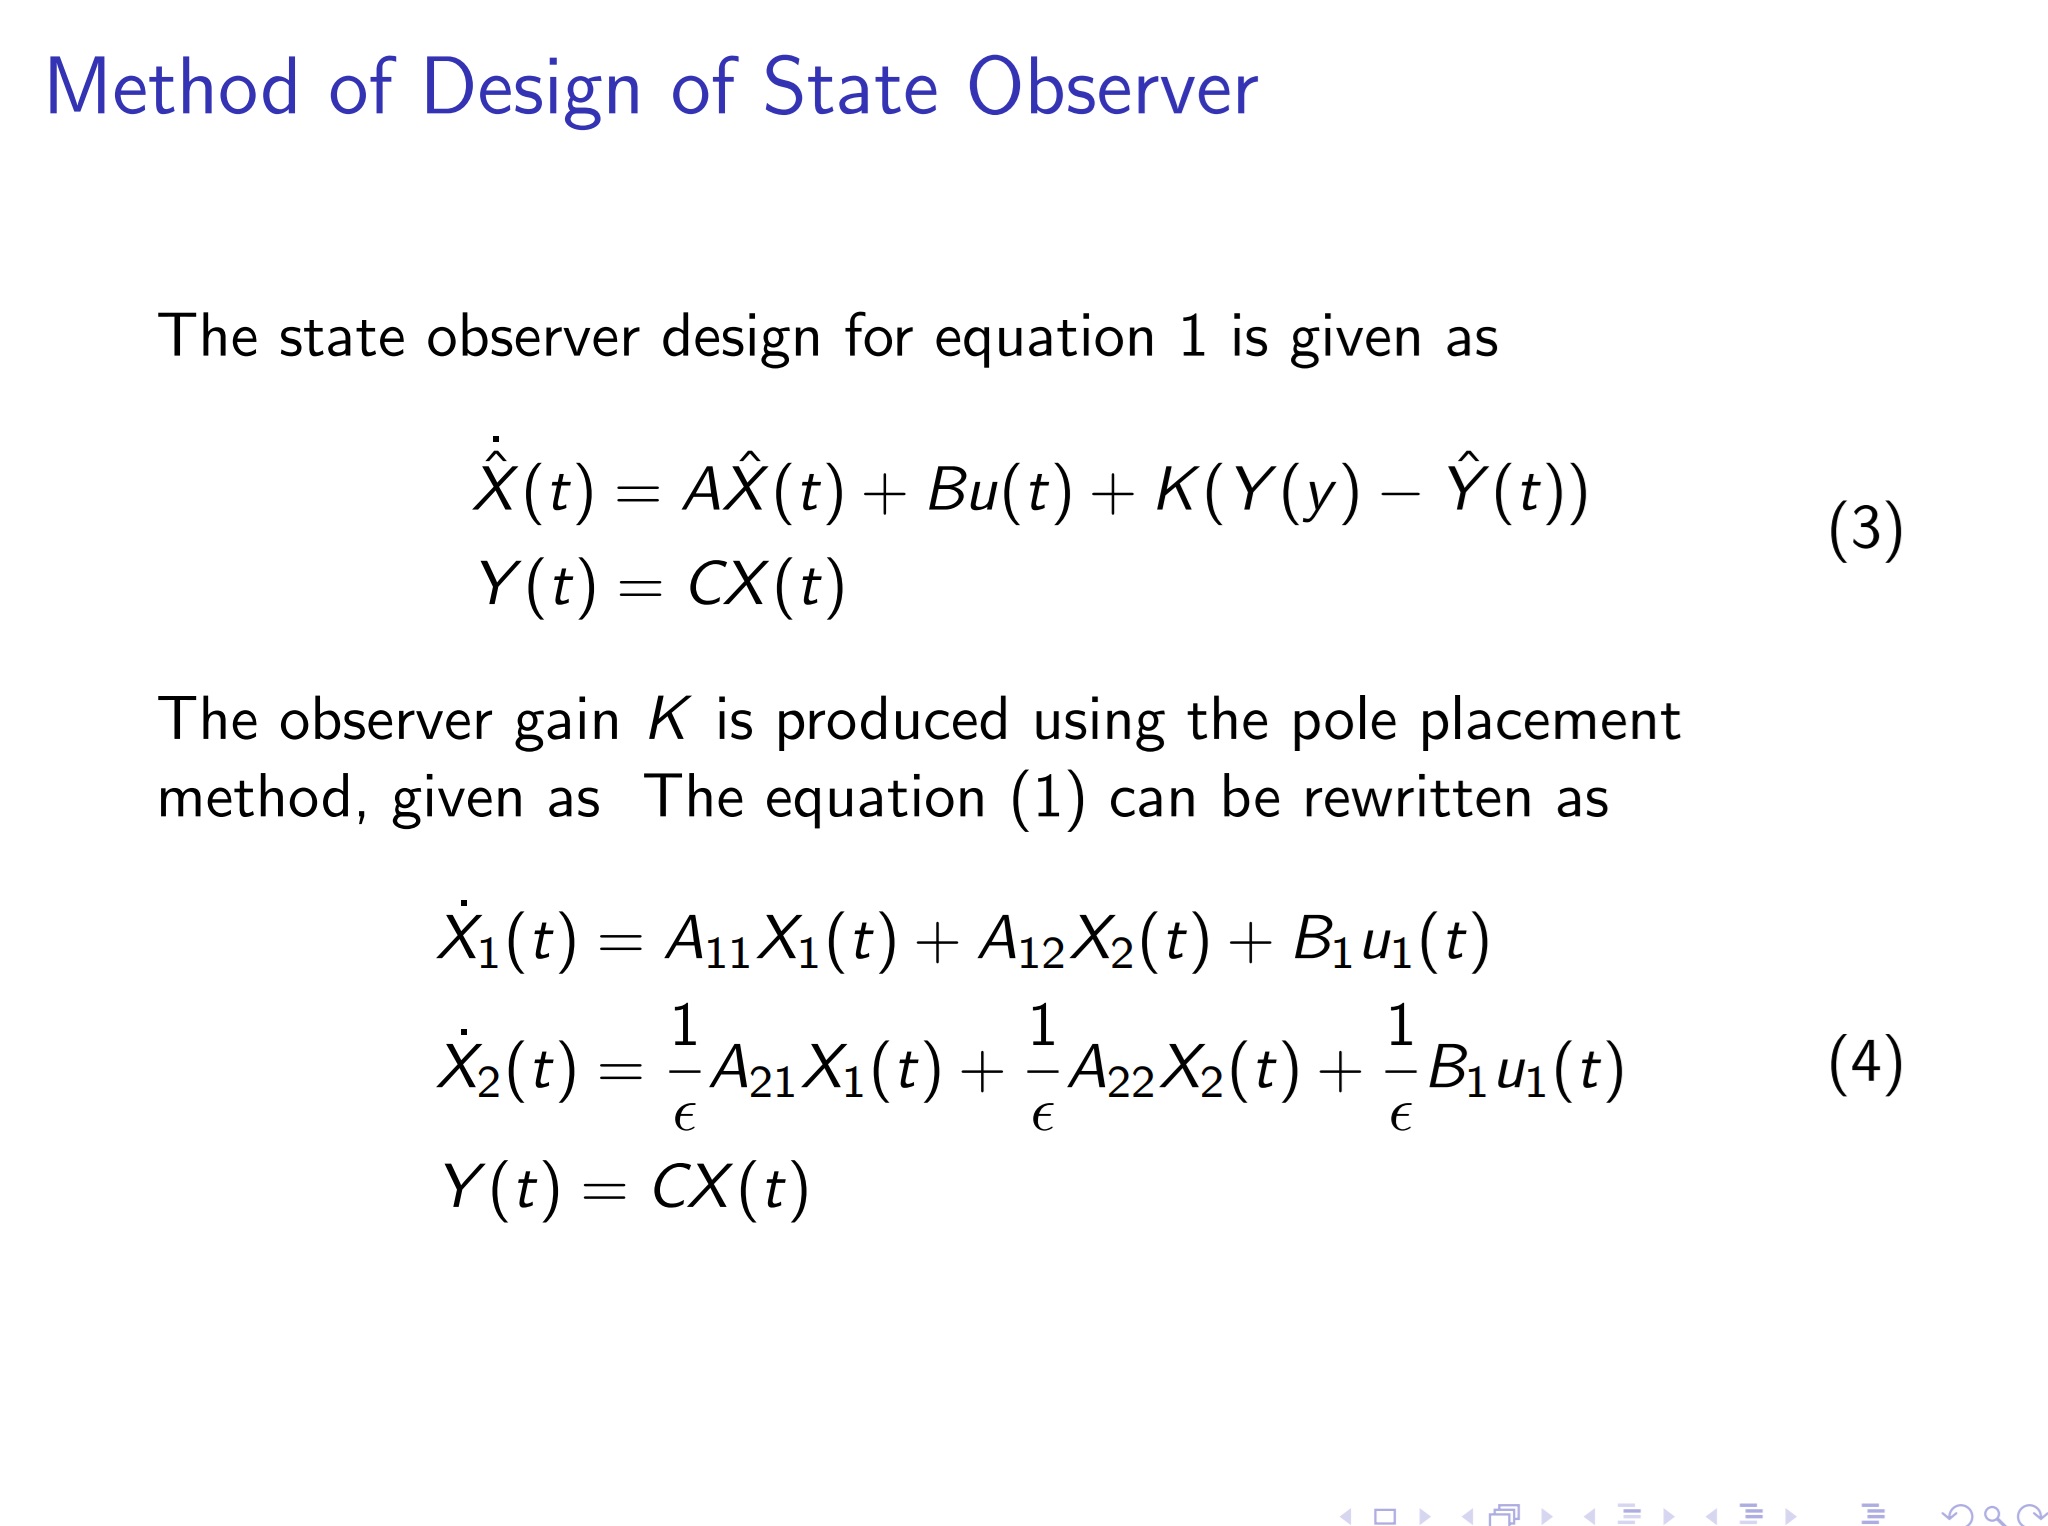 |
This is how we design the state observer, we follow classical Luenberger state observer by choosing observer gain K. The observer gain K can be found by pole placement technique here. |
| ICACT20250033 Slide.08
[Big Slide]
|
Chrome Click!! |
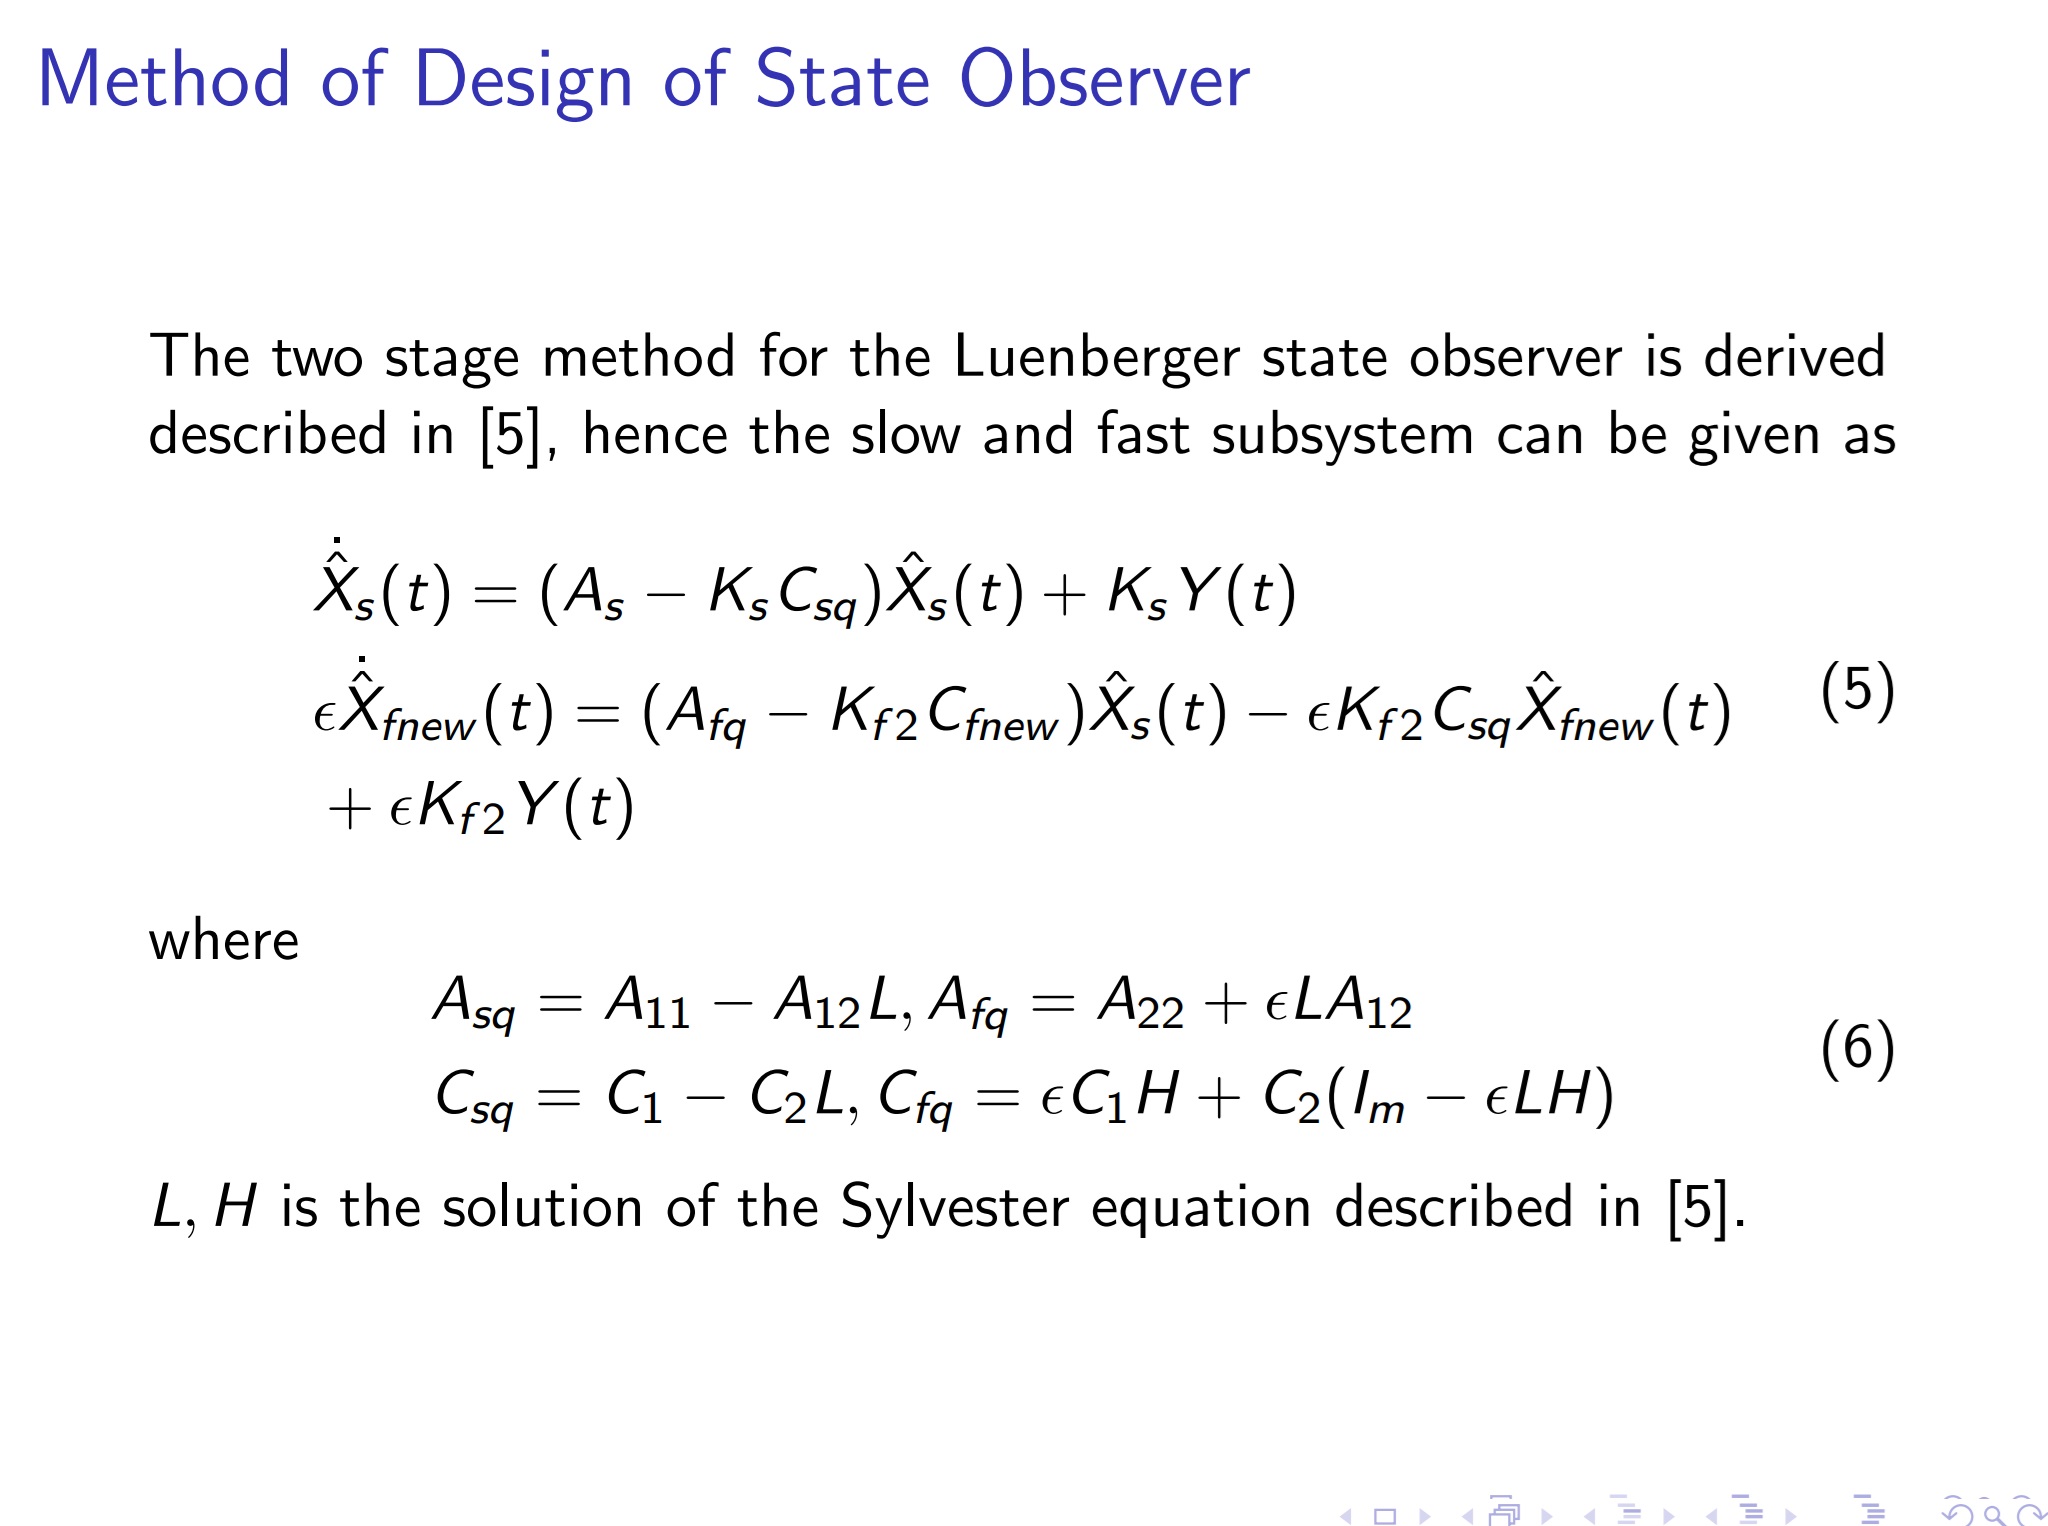 |
By the way, when we found observer gain K matrices, there is a numerical ill-conditioning happening, that is why we applied two stage method at this point. By decomposing slow and fast subsystem, the numerical ill-conditioning problem is overcame, then we can found the observer gain at the subsystem level. |
| ICACT20250033 Slide.09
[Big Slide]
|
Chrome Click!! |
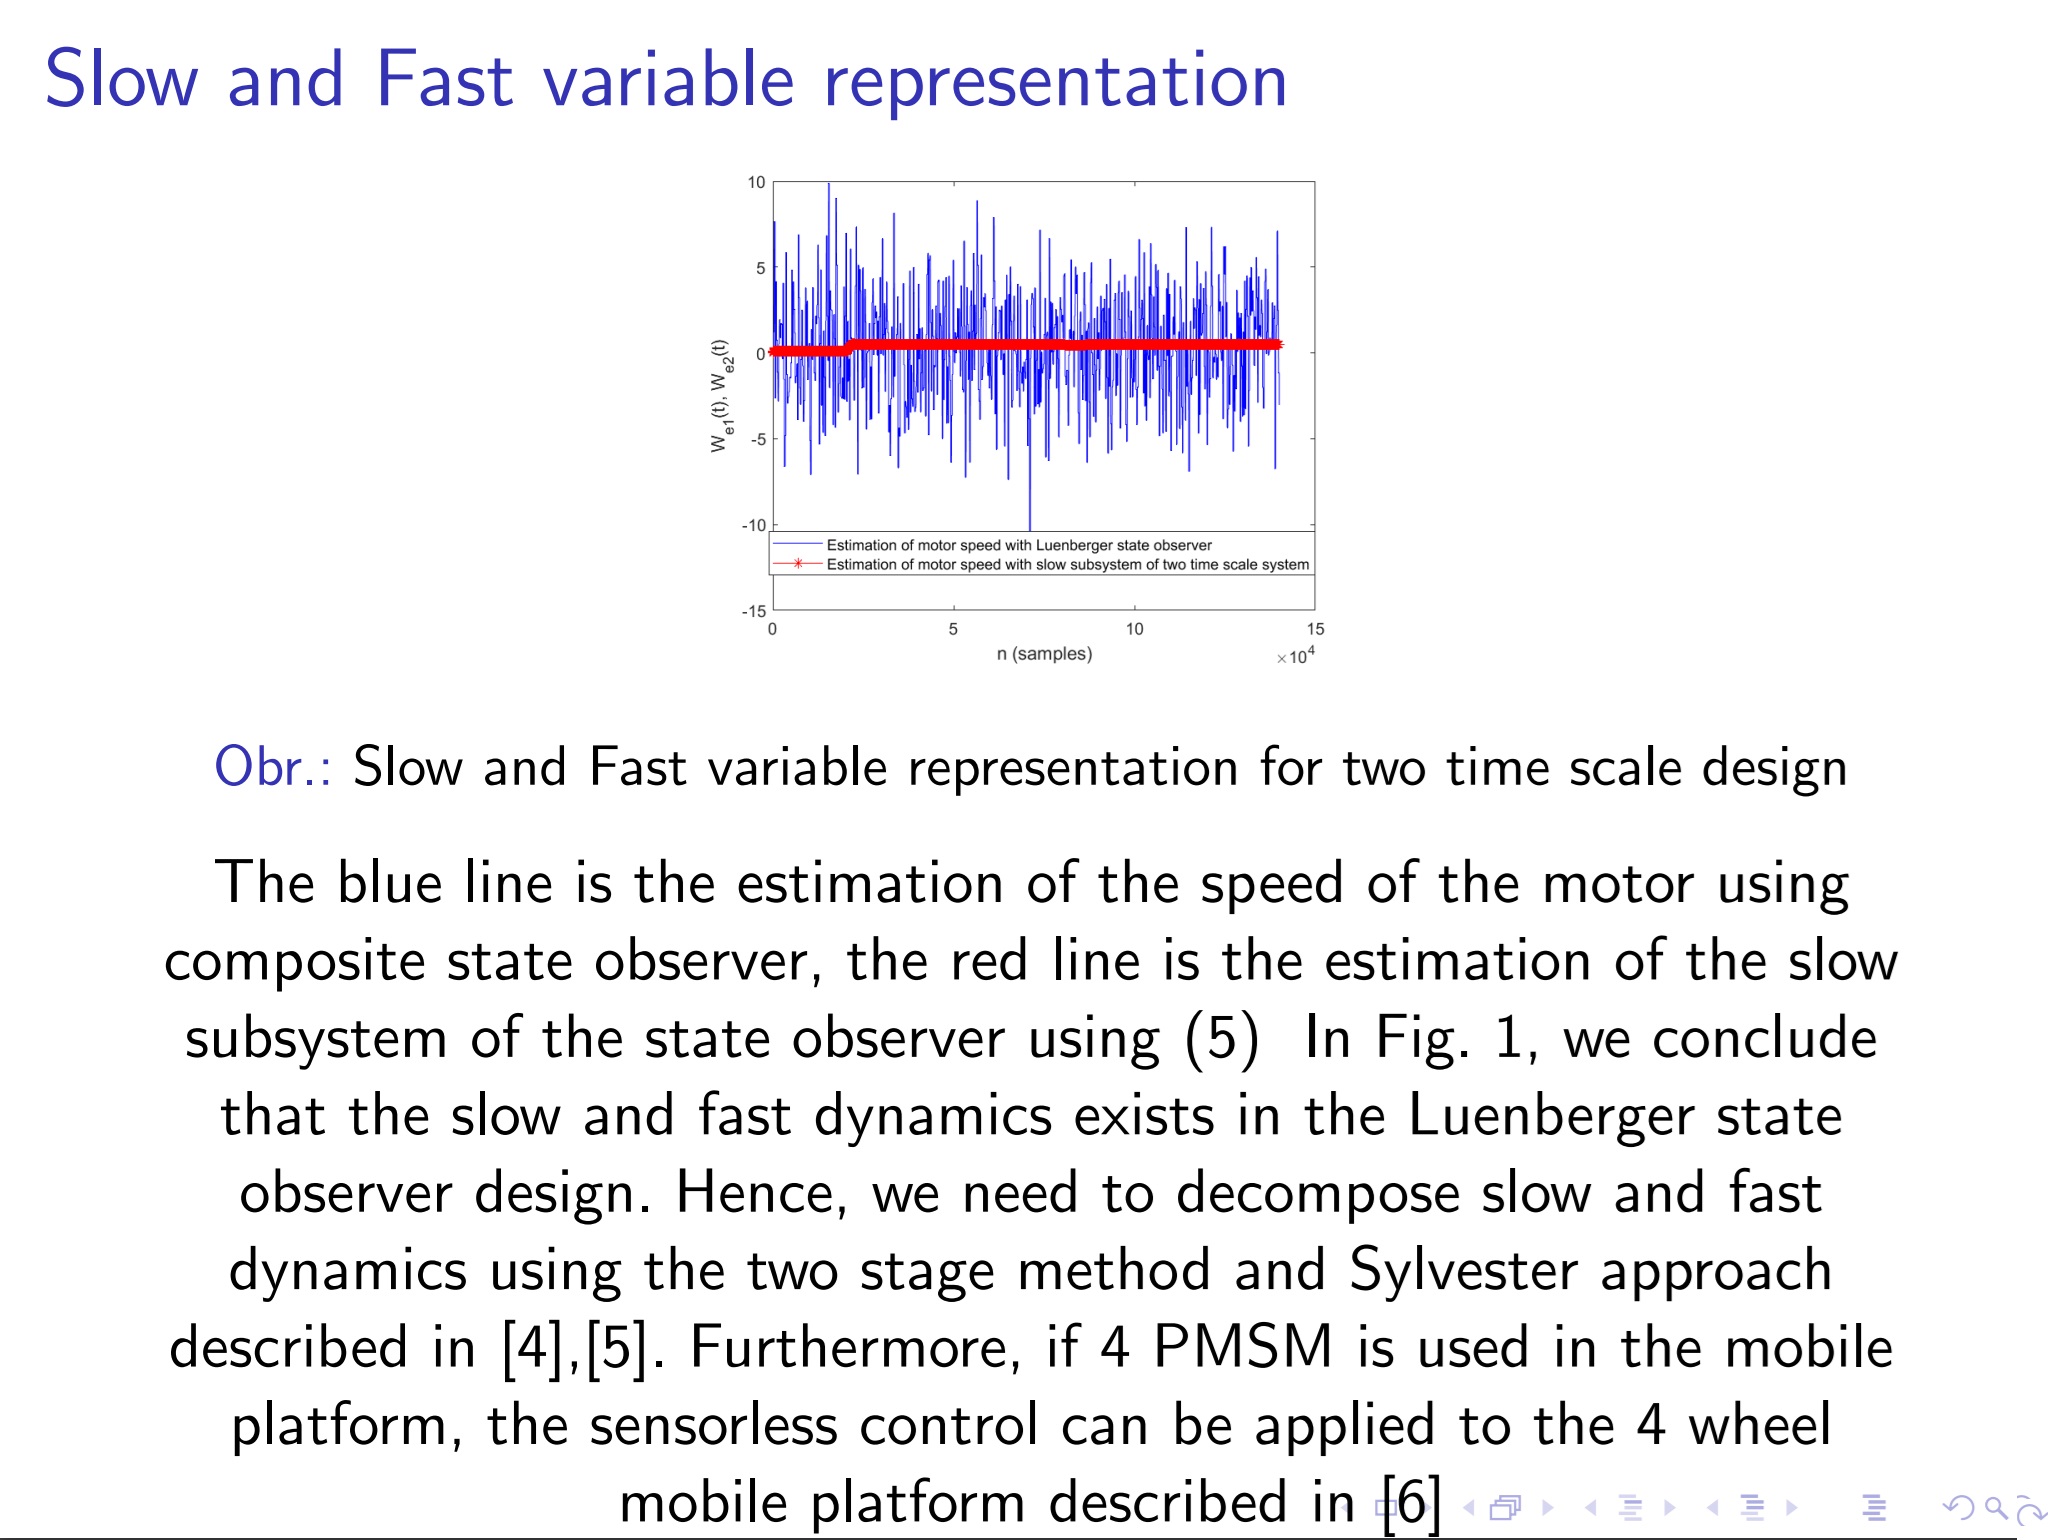 |
The blue line is the estimation of the speed of the motor using
composite state observer, the red line is the estimation of the slow
subsystem of the state observer using (5) In Fig. 1, we conclude
that the slow and fast dynamics exists in the Luenberger state
observer design. Hence, we need to decompose slow and fast
dynamics using the two stage method and Sylvester approach
described in [4],[5]. Furthermore, if 4 PMSM is used in the mobile
platform, the sensorless control can be applied to the 4 wheel
mobile platform described in [6] |
| ICACT20250033 Slide.10
[Big Slide]
|
Chrome Click!! |
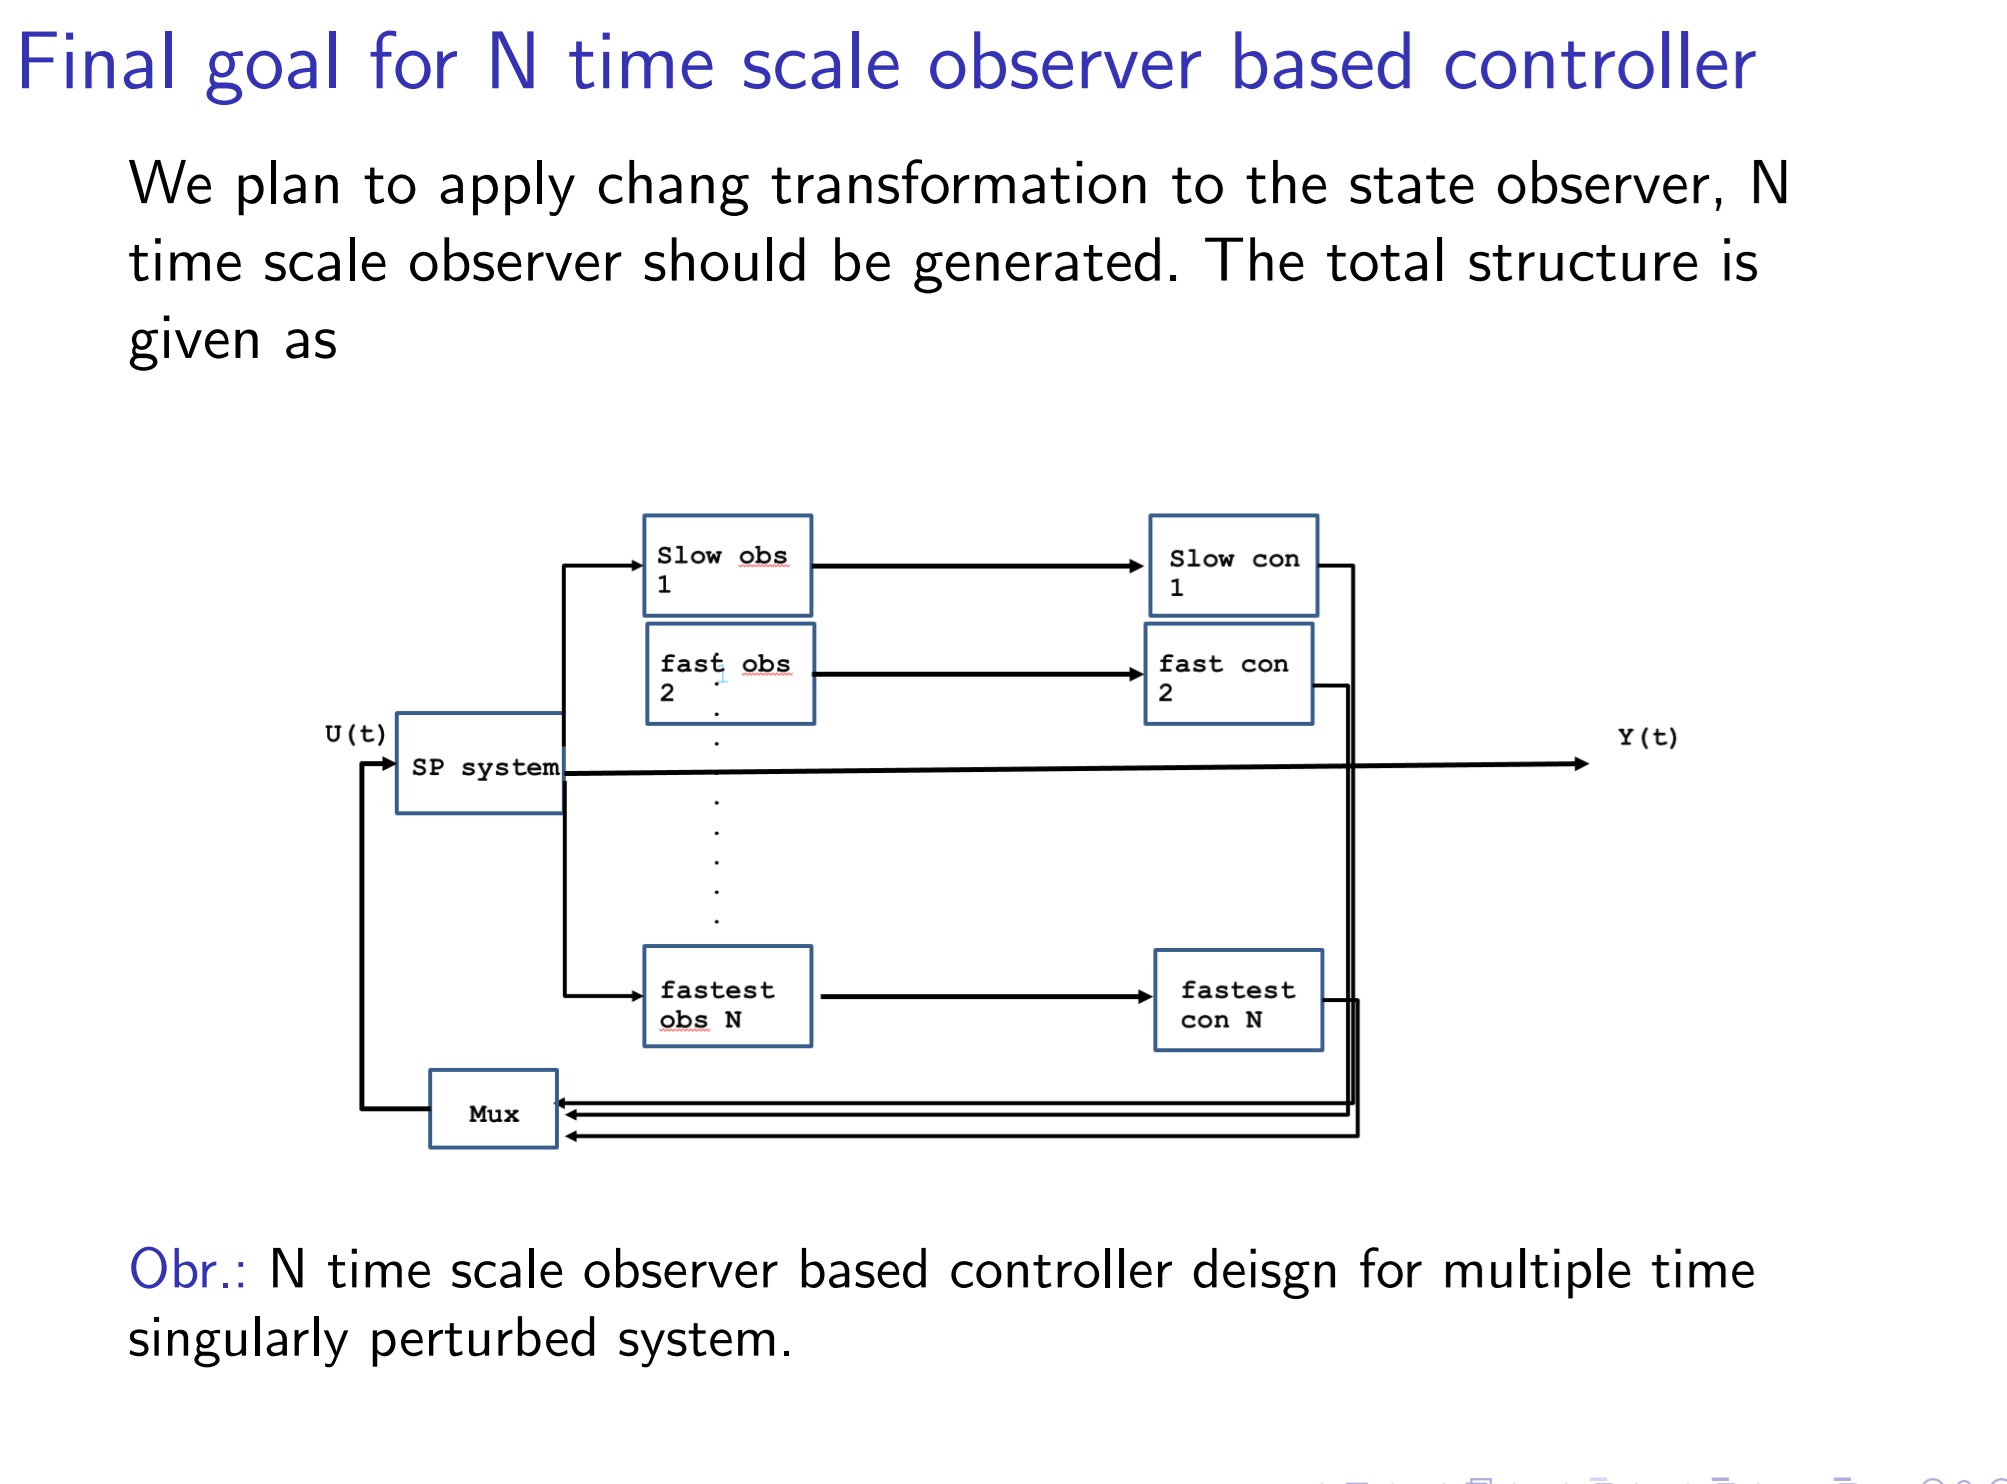 |
This is our future work, if we use 5 or 6 PMSM motors, the system might be more complicated. In that case, SP system mode can explicit multiple time scale behavior. In that case, we can decompose the syetem into N time scale mode. We can extend the result to N time scale observer and controller design. |
| ICACT20250033 Slide.11
[Big Slide]
|
Chrome Click!! |
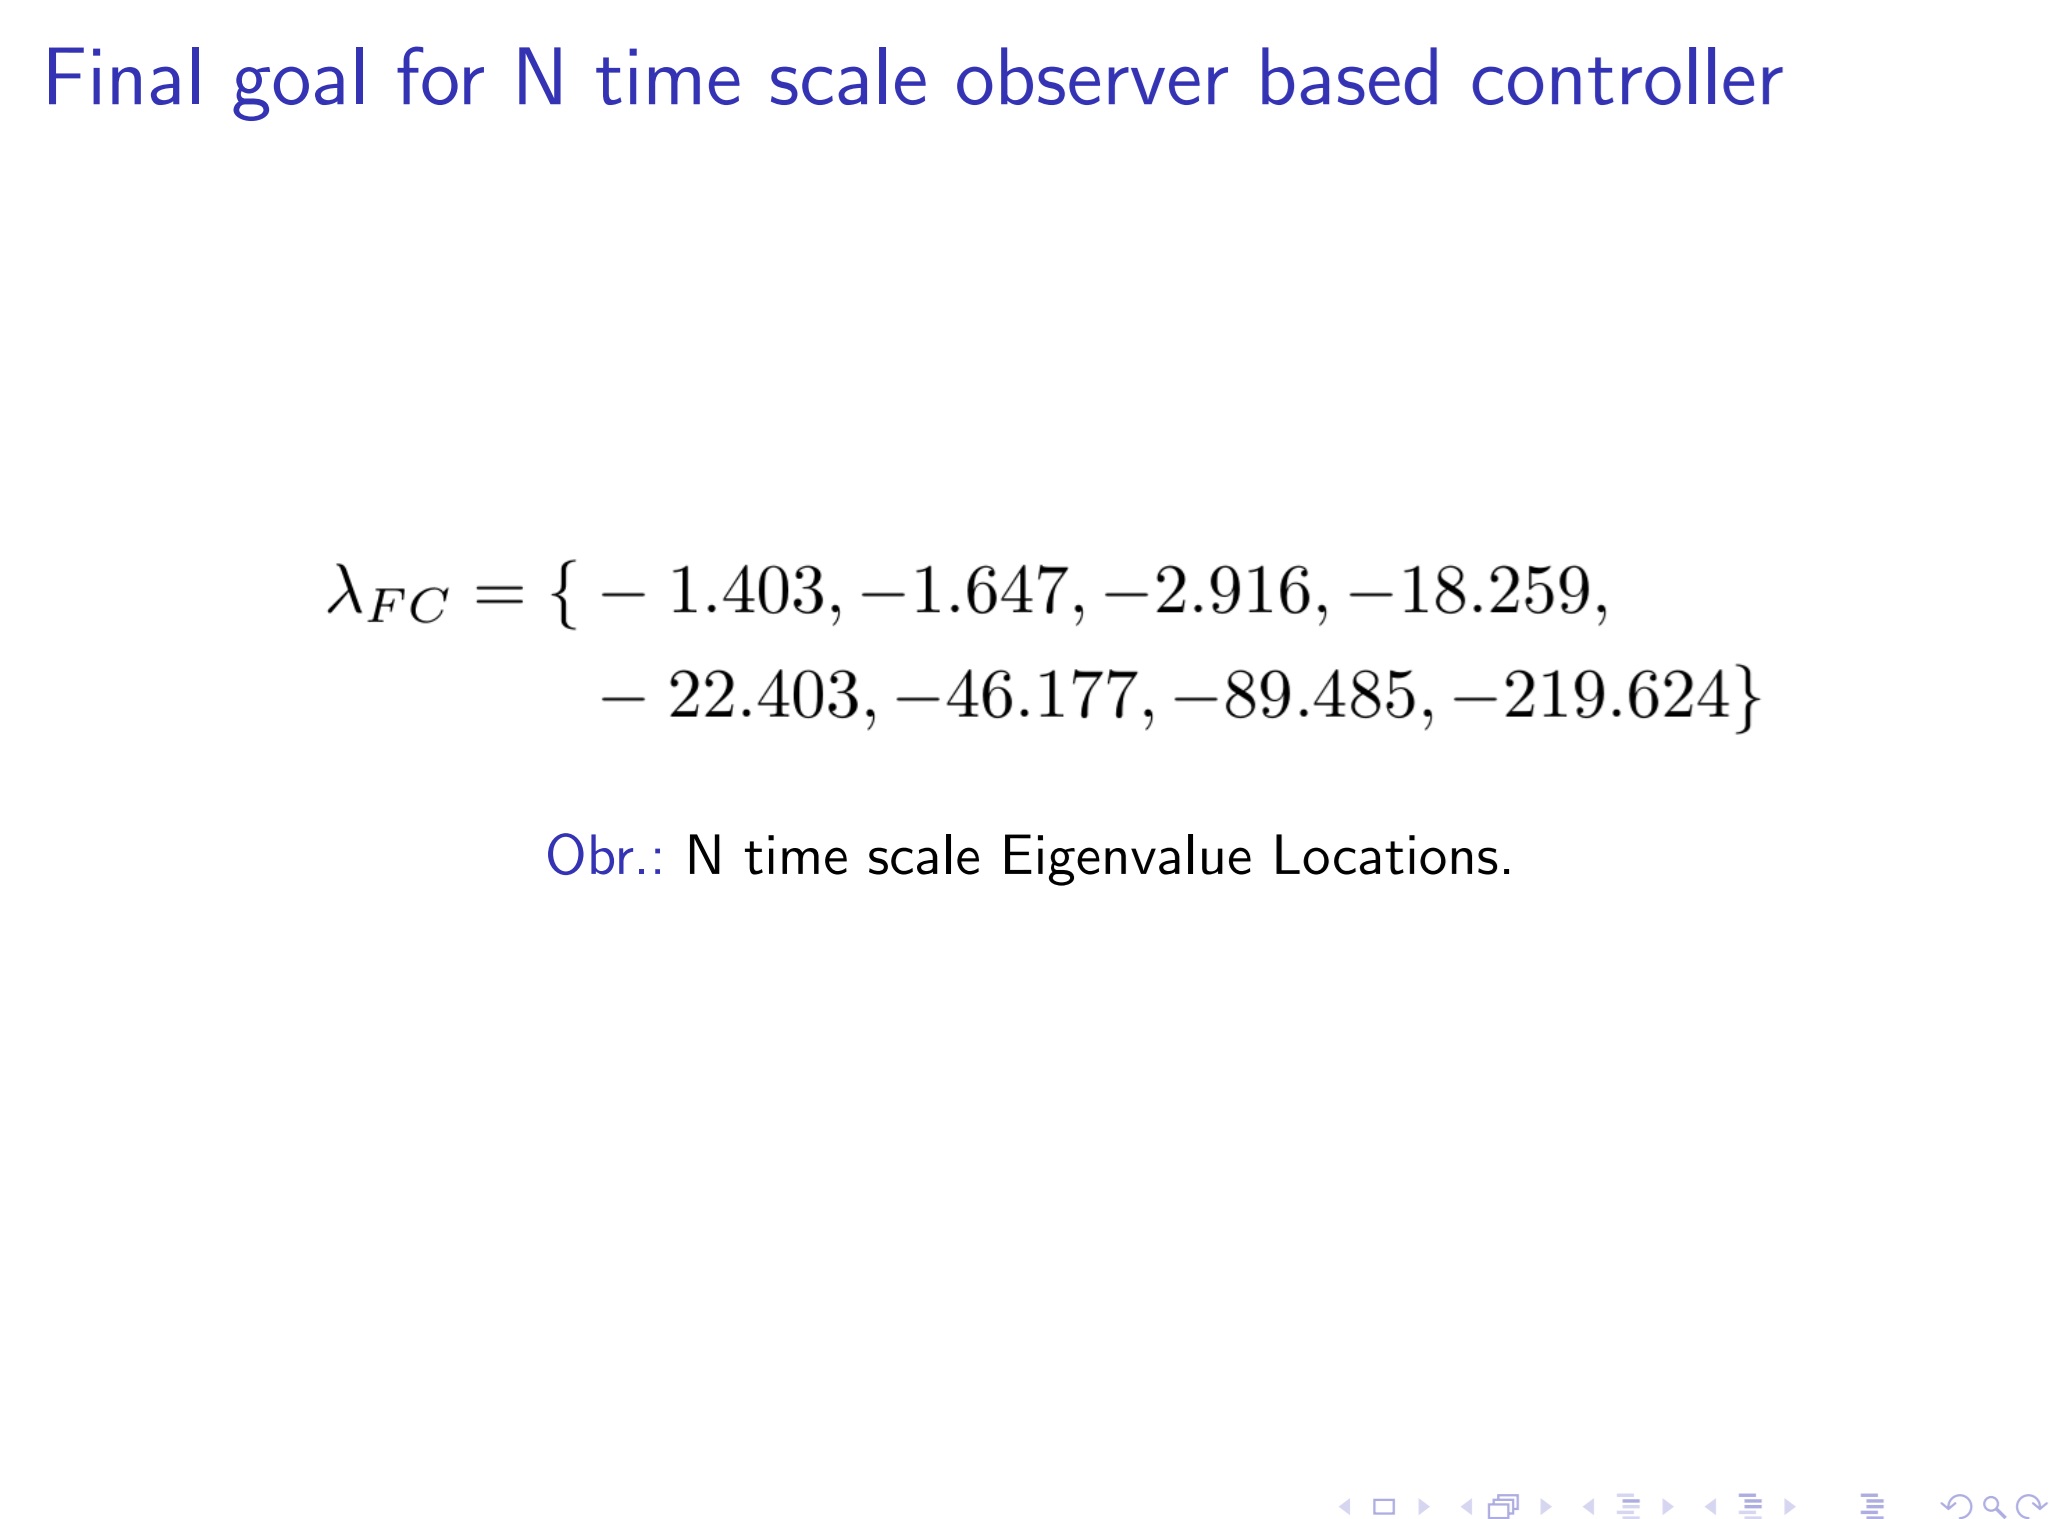 |
The eigenvalues in other word pole can be found many of the sytem, that can be expressed as multiple time scale system |
| ICACT20250033 Slide.12
[Big Slide]
|
Chrome Click!! |
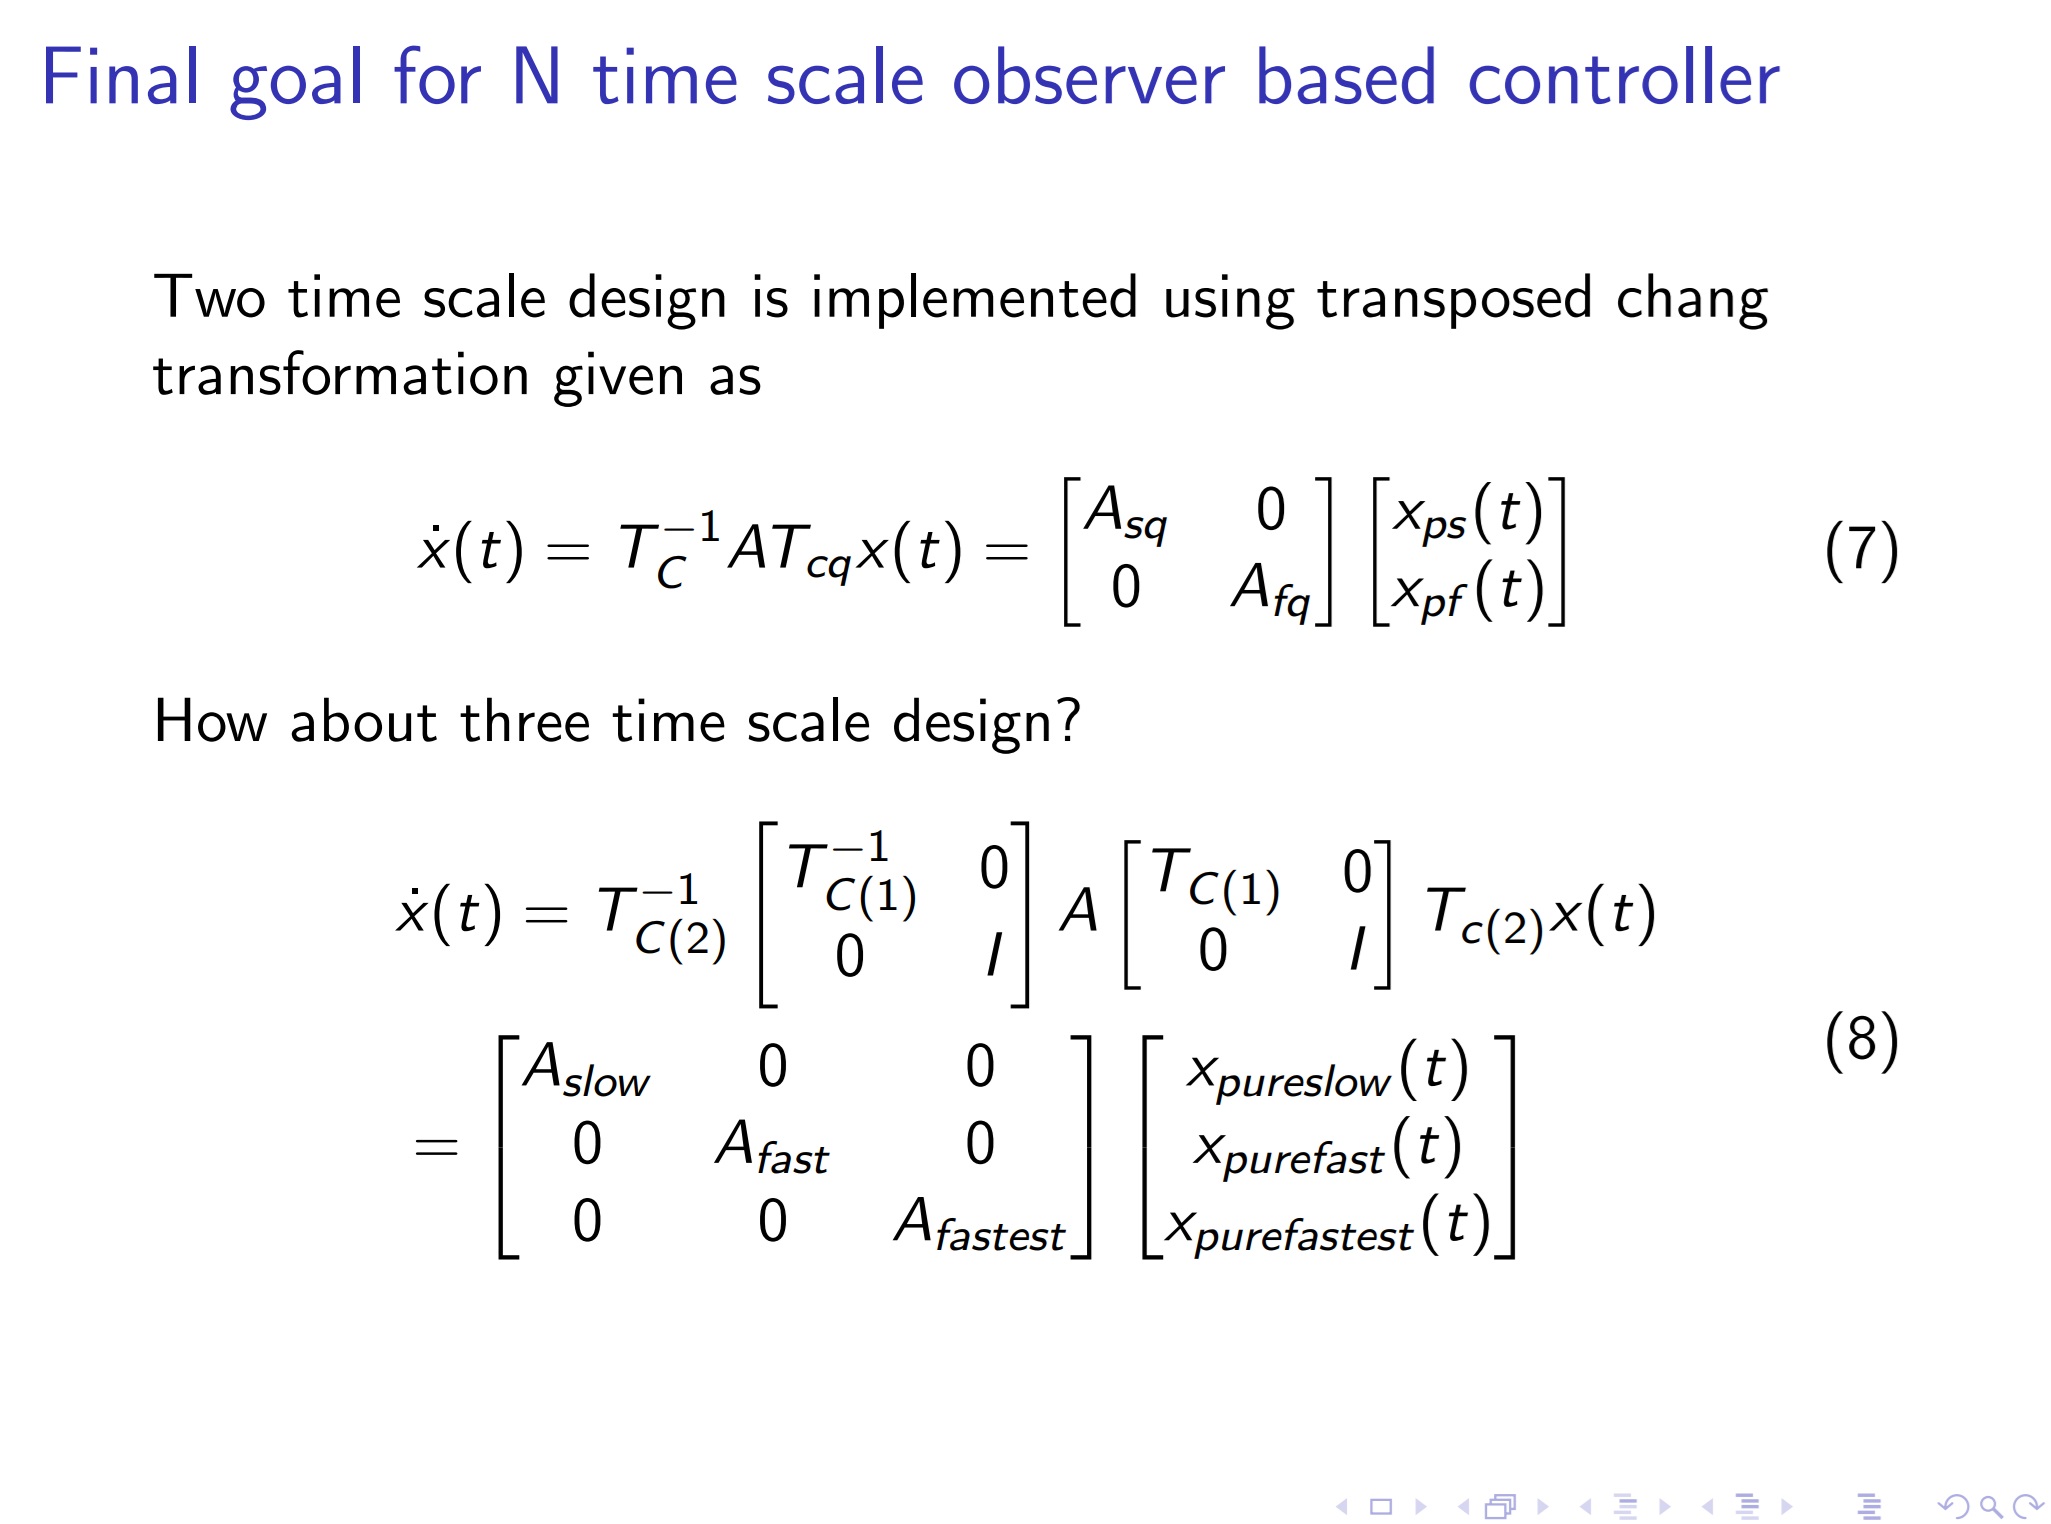 |
Two time scale design is the following. How about three time scale design, we just add one more state transformation to design three time scale design. |
| ICACT20250033 Slide.13
[Big Slide]
|
Chrome Click!! |
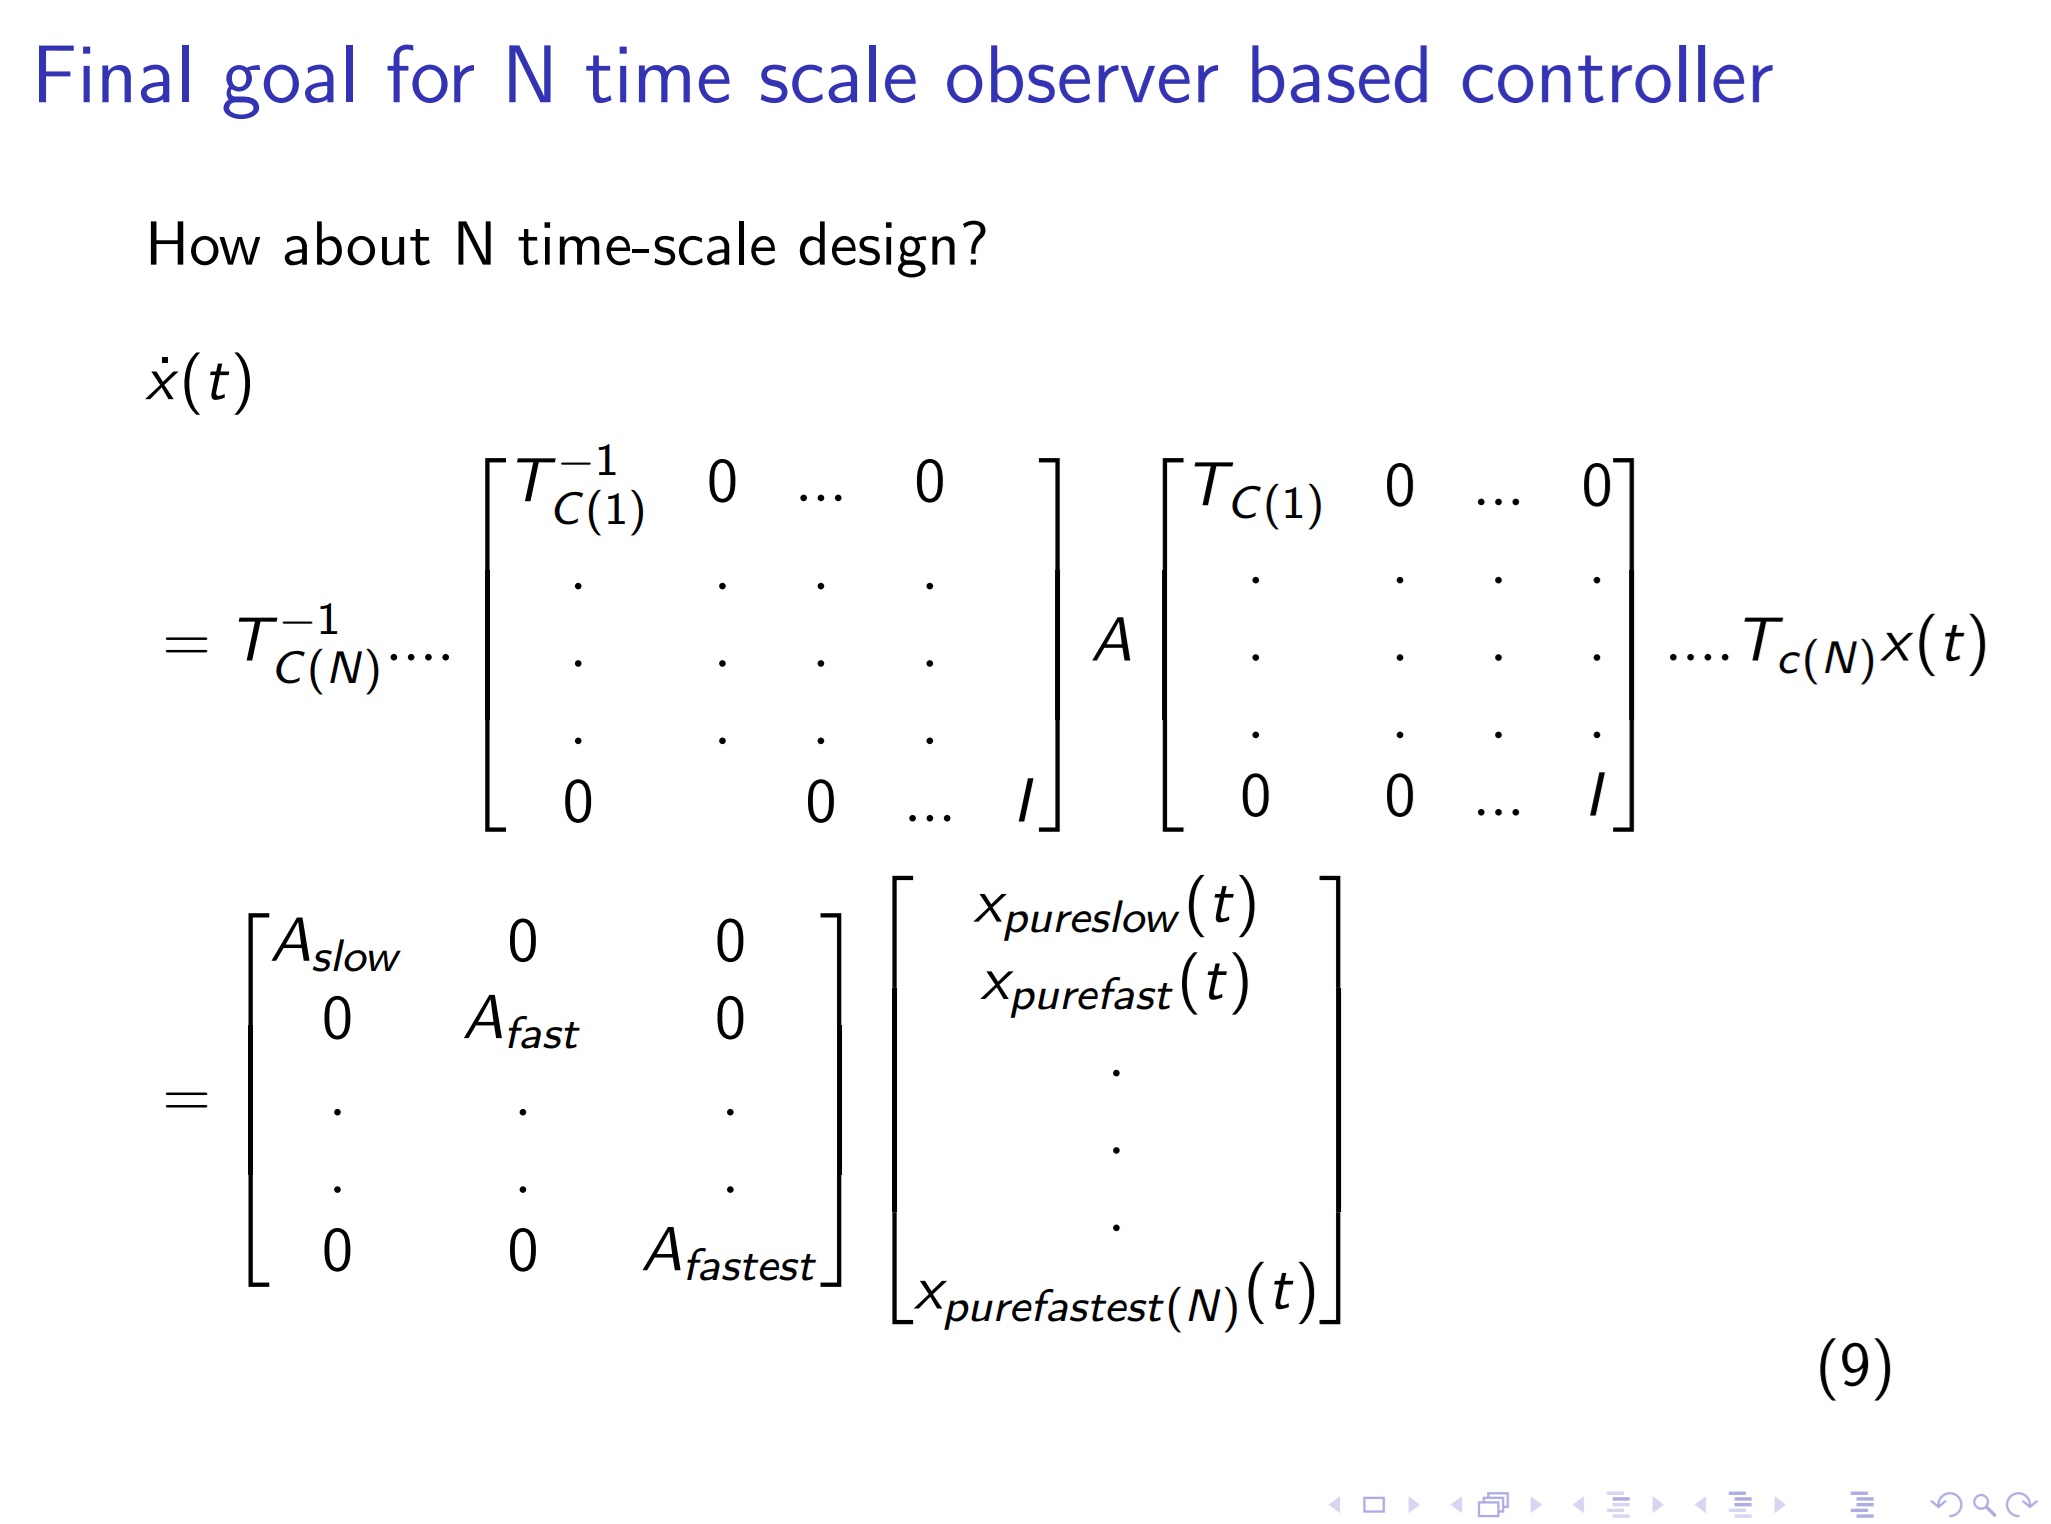 |
How about N time scale design, we just add N steps of state transformation to decompose SP system into N time scale design. This can be applied to the 4 wheel mobile platform, since platform have 8 PMSM motors. 4 is for in-wheel motors, and 4 is for steering motors. |
| ICACT20250033 Slide.14
[Big Slide]
|
Chrome Click!! |
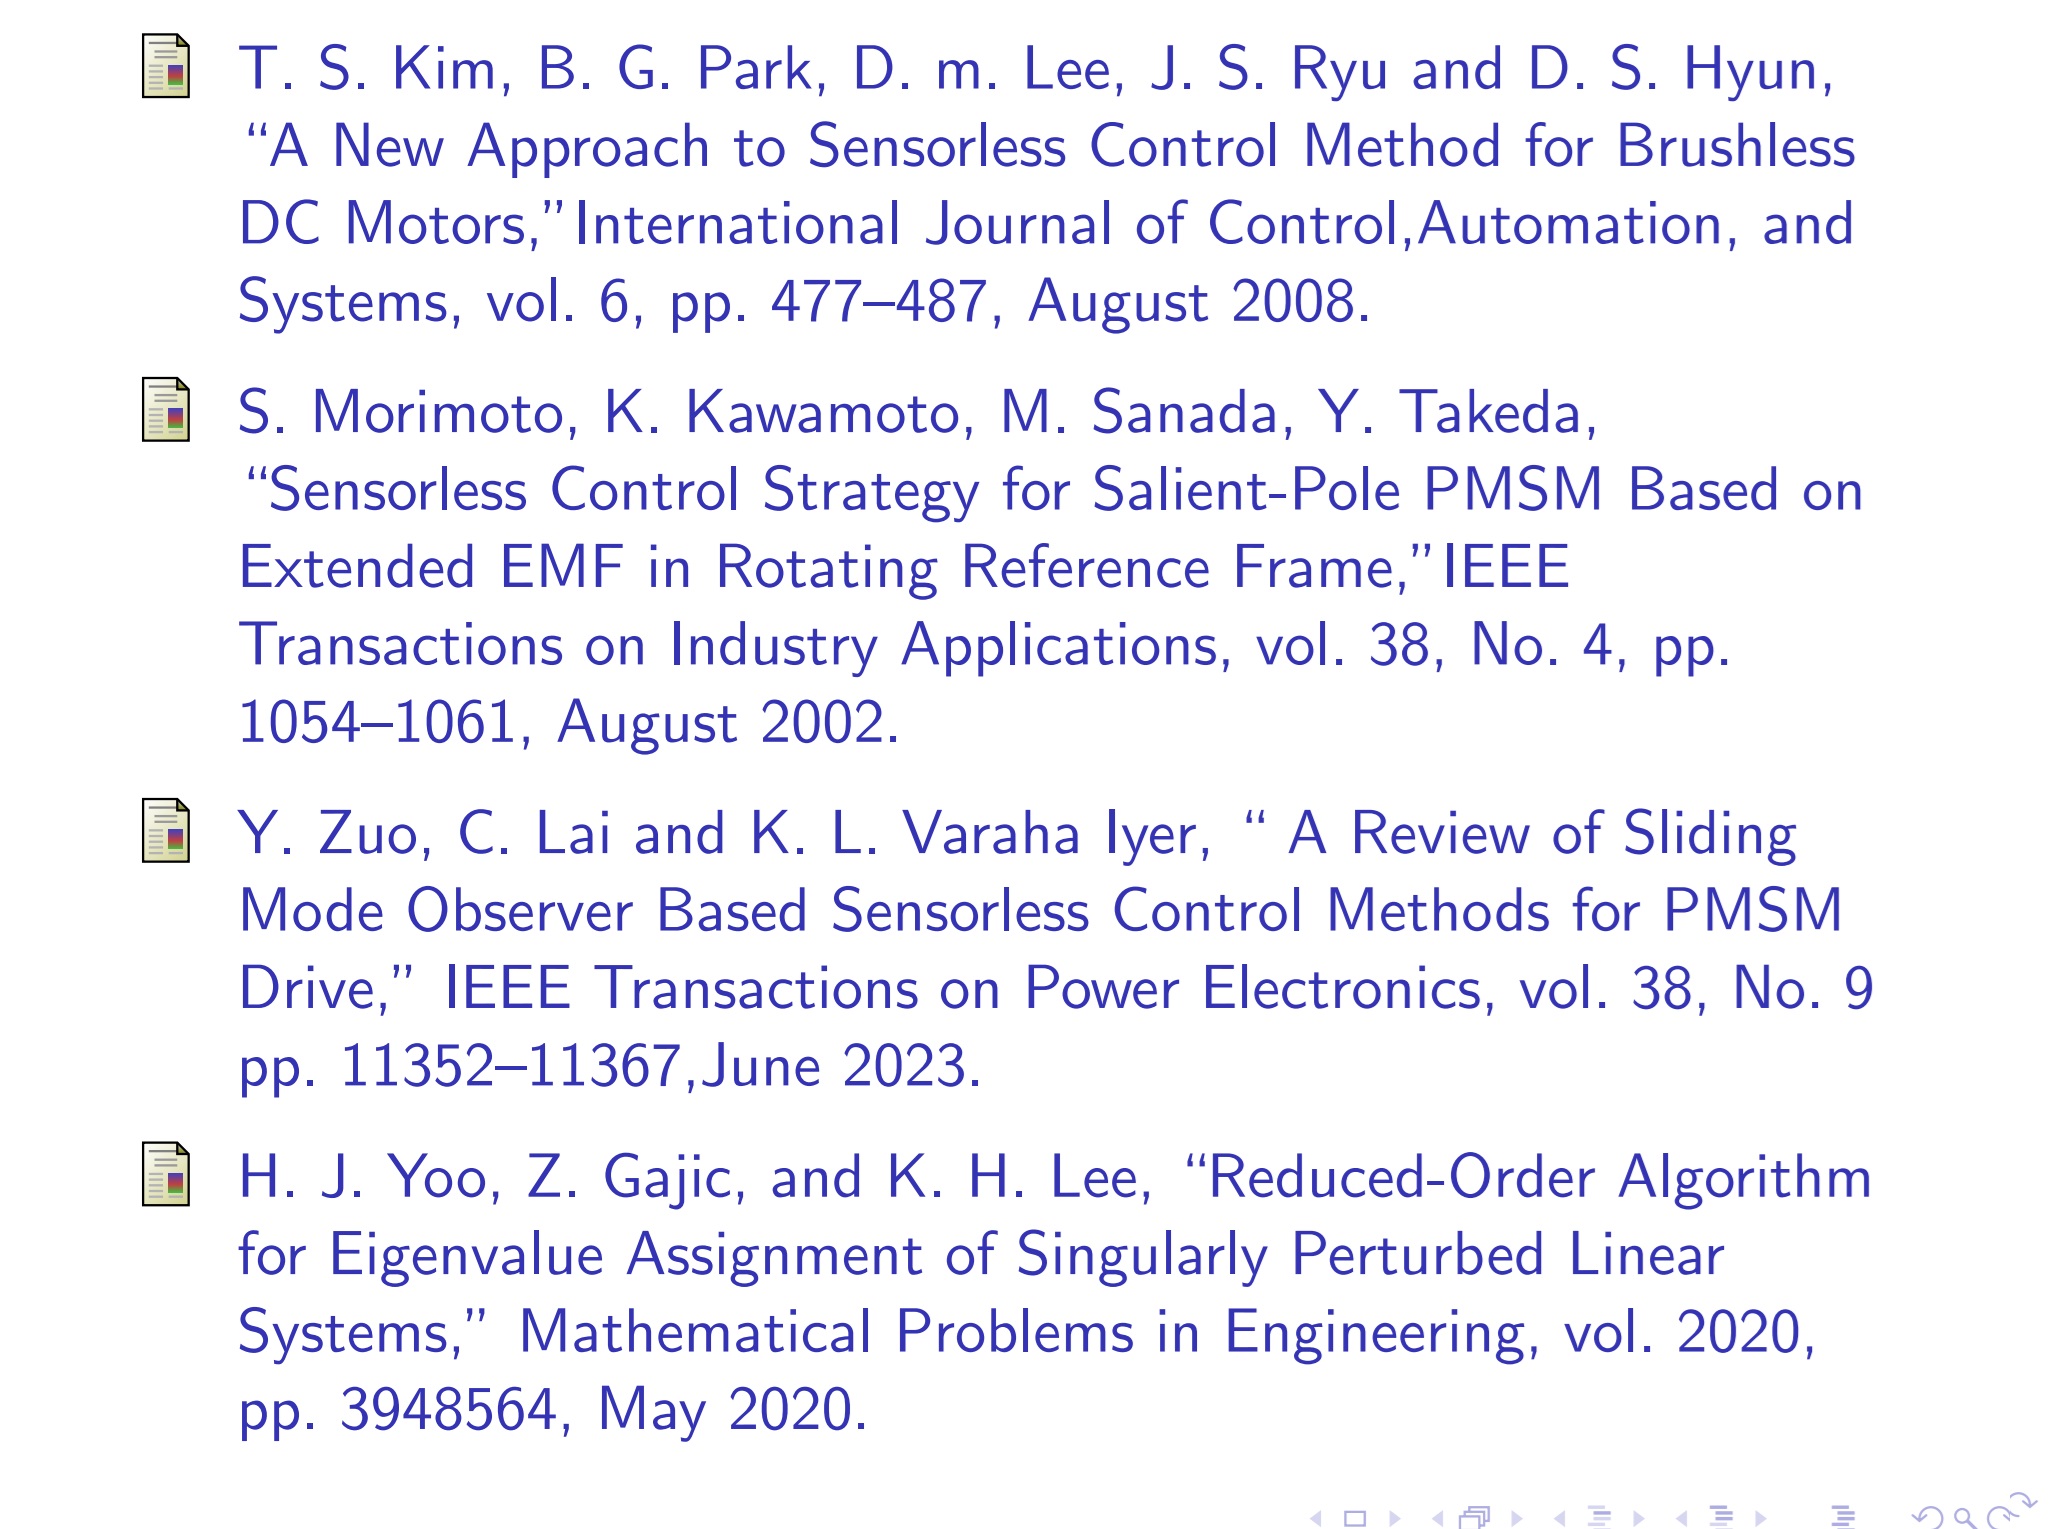 |
These are the references we took. For sensorless control, there is a method published in 2008 and 2002. Also the author himself researched singularly perturbed system in 2020. |
| ICACT20250033 Slide.15
[Big Slide]
|
Chrome Click!! |
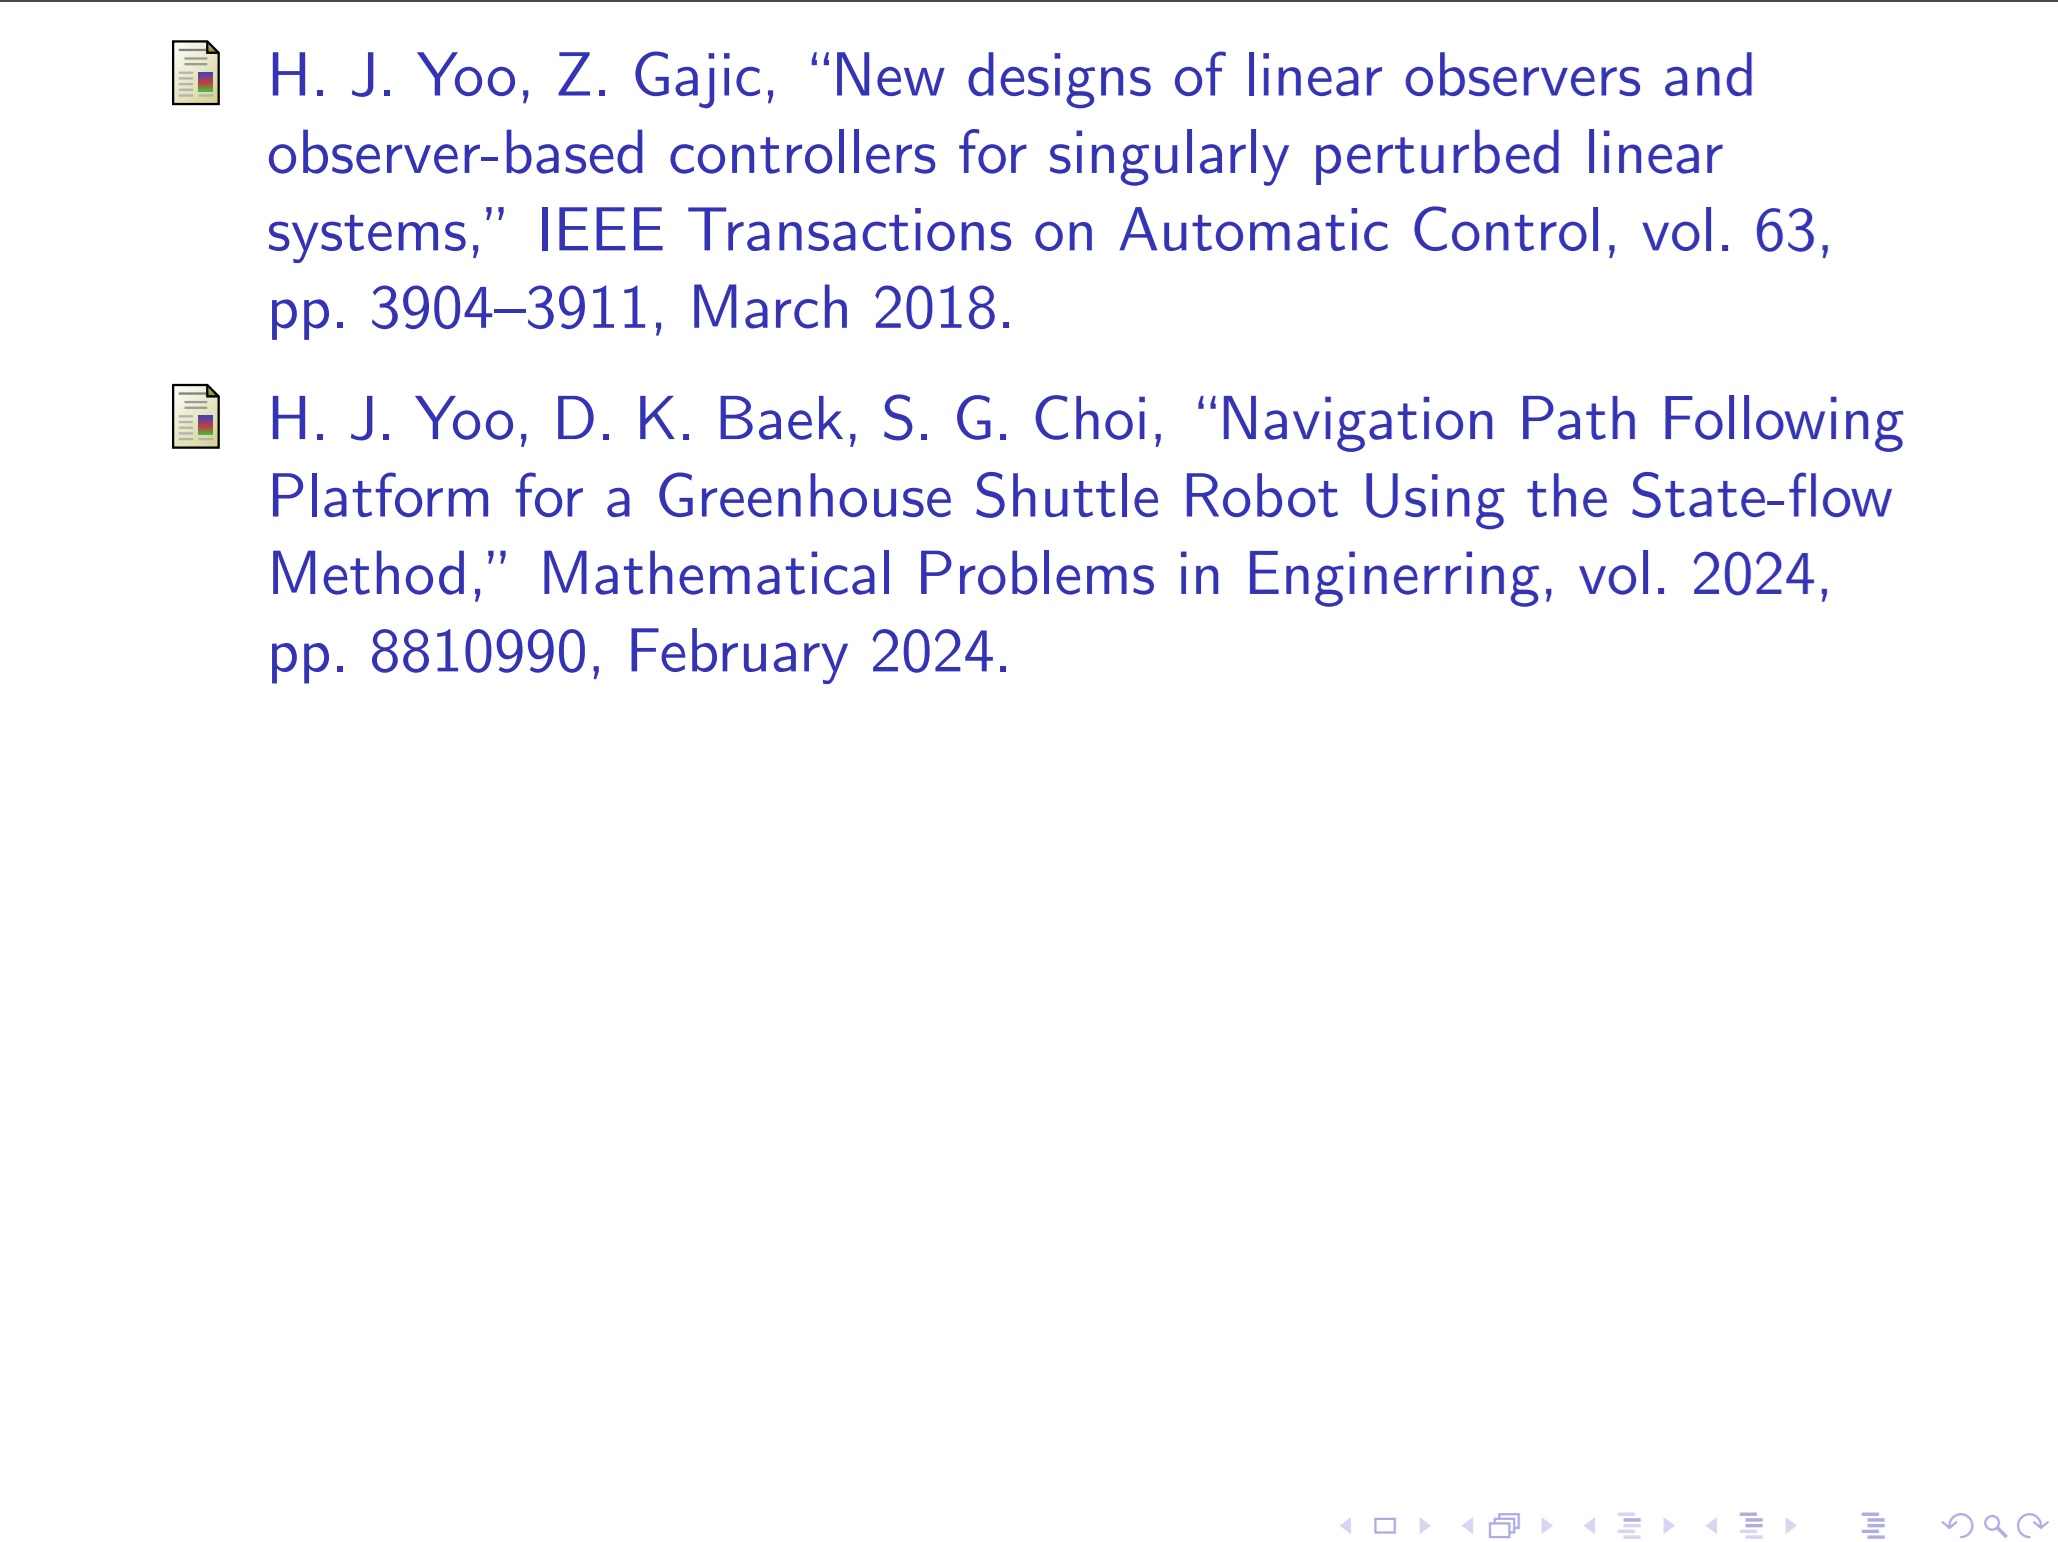 |
Also the author published new method for SP system in 2018. Also, 4 wheel mobile platform is researched in Chungbuk National university published in 2024. Here we use state flow method. By this presenation, we show we can apply different method to 4 wheel mobile platform, using SP system. |















