 ICACT20250169 Slide.01
[Big Slide]
[YouTube] |
Chrome  Click!! |
 |
This page presents the topic of the paper presented |
| ICACT20250169 Slide.02
[Big Slide]
[YouTube] |
Chrome Click!! |
 |
This page presentation presents the table of contents section of the paper |
| ICACT20250169 Slide.03
[Big Slide]
[YouTube] |
Chrome Click!! |
 |
This page presentation introduces the concept of cogging torque |
| ICACT20250169 Slide.04
[Big Slide]
[YouTube] |
Chrome Click!! |
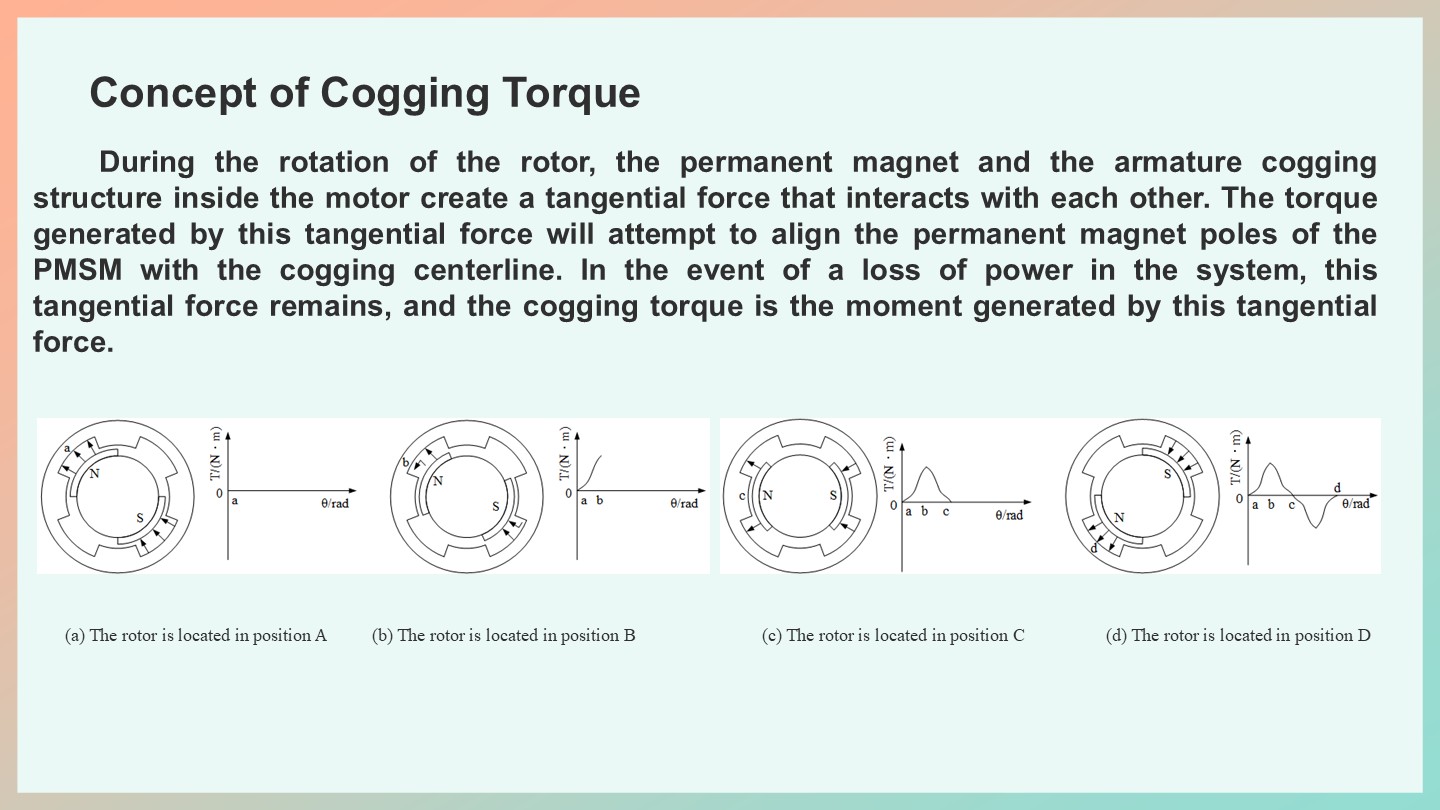 |
During the rotation of the rotor, the permanent magnet and the armature cogging structure inside the motor create a tangential force that interacts with each other. The torque generated by this tangential force will attempt to align the permanent magnet poles of the PMSM with the cogging centerline. In the event of a loss of power in the system, this tangential force remains, and the cogging torque is the moment generated by this tangential force.
|
| ICACT20250169 Slide.05
[Big Slide]
[YouTube] |
Chrome Click!! |
 |
This page presentation introduces the methods for suppressing cogging torque |
| ICACT20250169 Slide.06
[Big Slide]
[YouTube] |
Chrome Click!! |
 |
This page presentation introduces the PI-based Motion Control Strategy |
| ICACT20250169 Slide.07
[Big Slide]
[YouTube] |
Chrome Click!! |
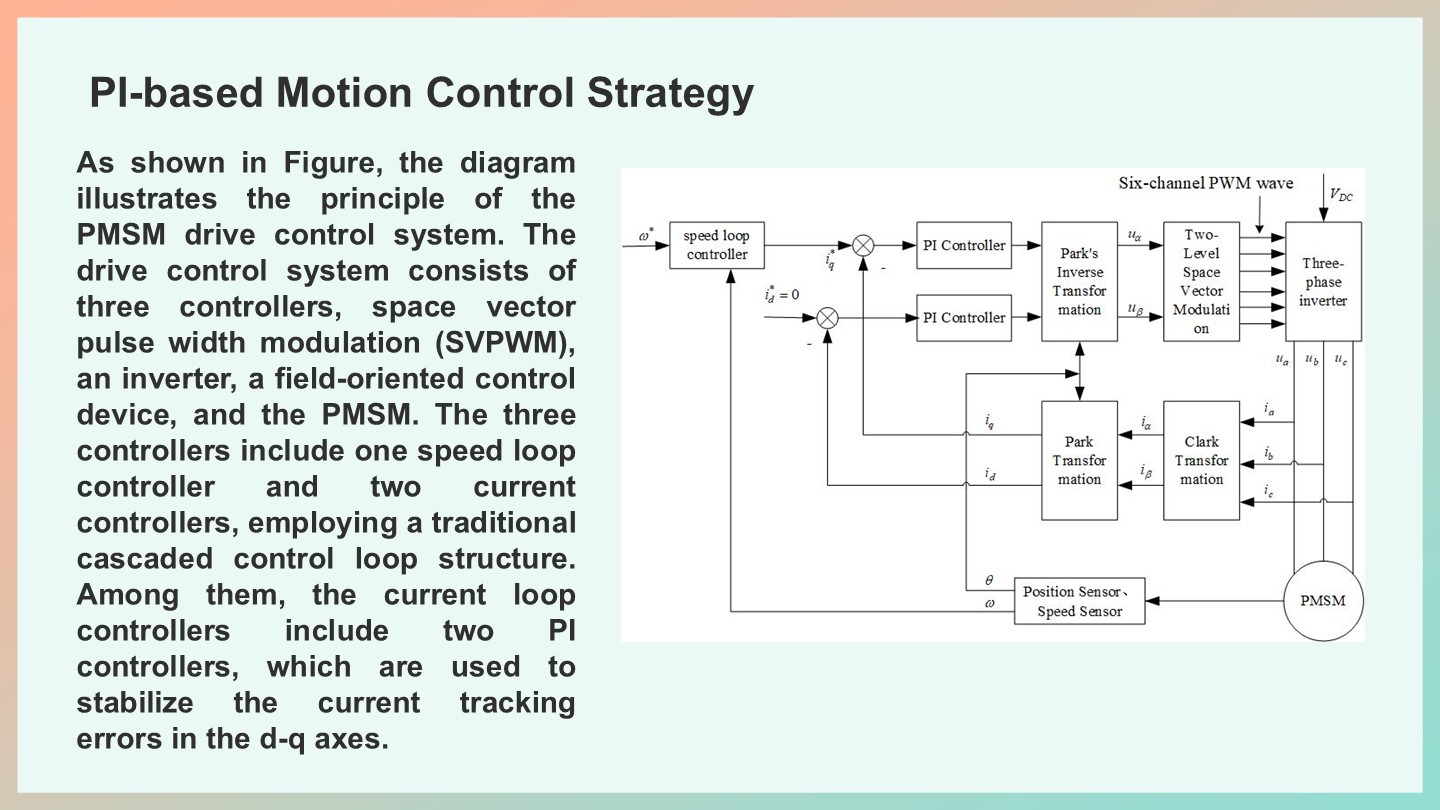 |
the diagram illustrates the principle of the PMSM drive control system. The drive control system consists of three controllers, space vector pulse width modulation (SVPWM), an inverter, a field-oriented control device, and the PMSM. |
| ICACT20250169 Slide.08
[Big Slide]
[YouTube] |
Chrome Click!! |
 |
This page presentation introduces the MPC+ESO-based Motion Control Strategy |
| ICACT20250169 Slide.09
[Big Slide]
[YouTube] |
Chrome Click!! |
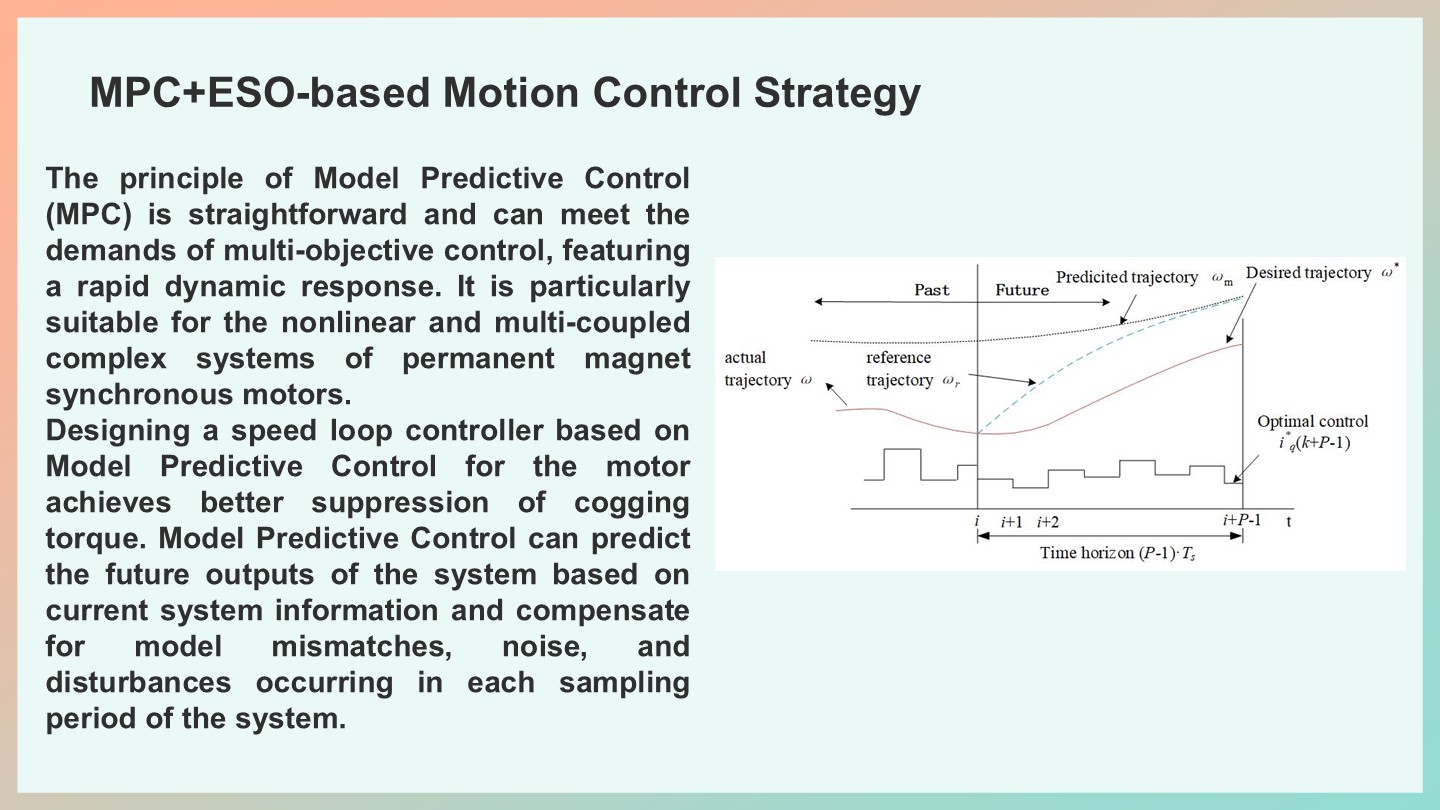 |
The principle of Model Predictive Control (MPC) is straightforward and can meet the demands of multi-objective control, featuring a rapid dynamic response. It is particularly suitable for the nonlinear and multi-coupled complex systems of permanent magnet synchronous motors.
|
| ICACT20250169 Slide.10
[Big Slide]
[YouTube] |
Chrome Click!! |
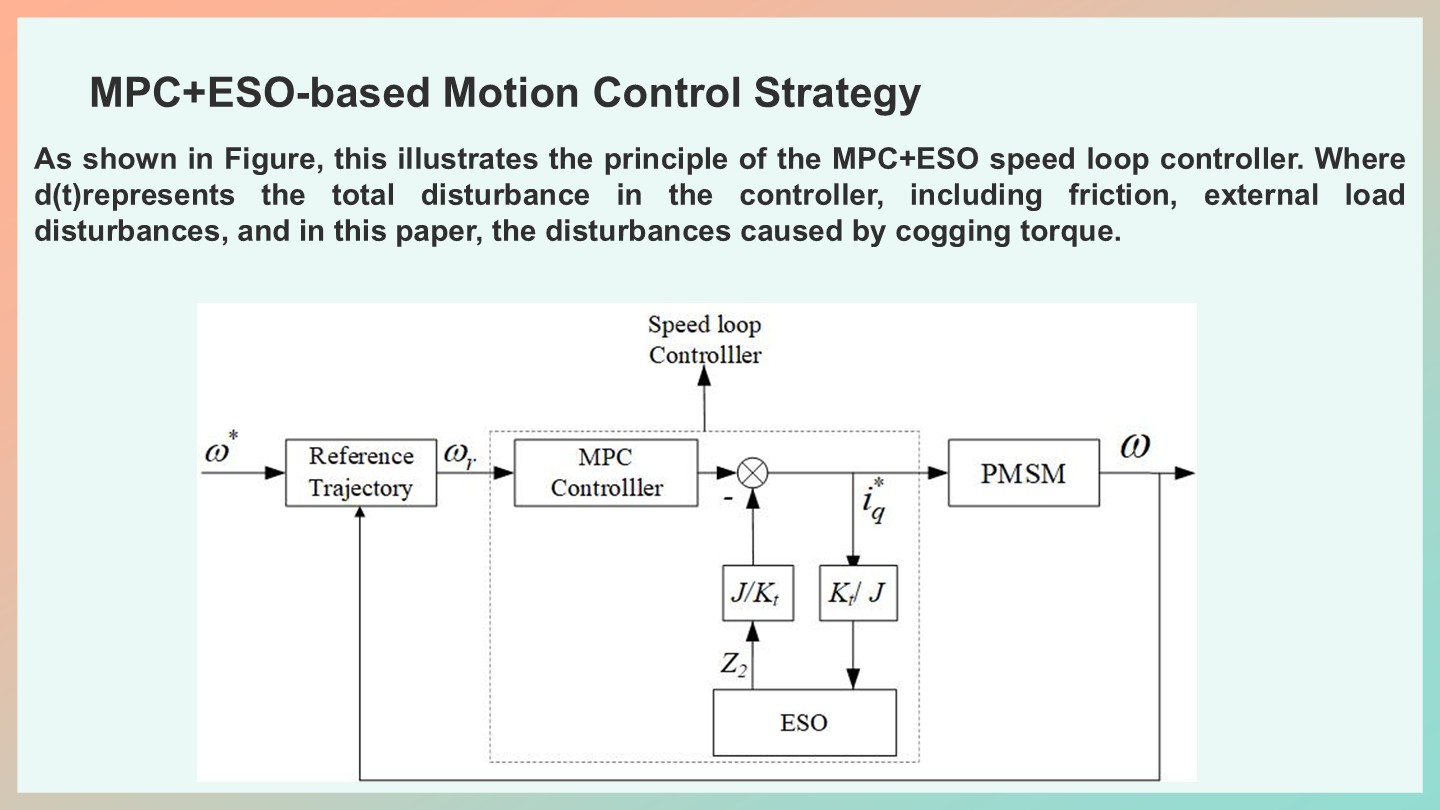 |
this illustrates the principle of the MPC+ESO speed loop controller. Where d(t)represents the total disturbance in the controller, including friction, external load disturbances, and in this paper, the disturbances caused by cogging torque. |
| ICACT20250169 Slide.11
[Big Slide]
[YouTube] |
Chrome Click!! |
 |
This page presentation introduces the simulation validation |
| ICACT20250169 Slide.12
[Big Slide]
[YouTube] |
Chrome Click!! |
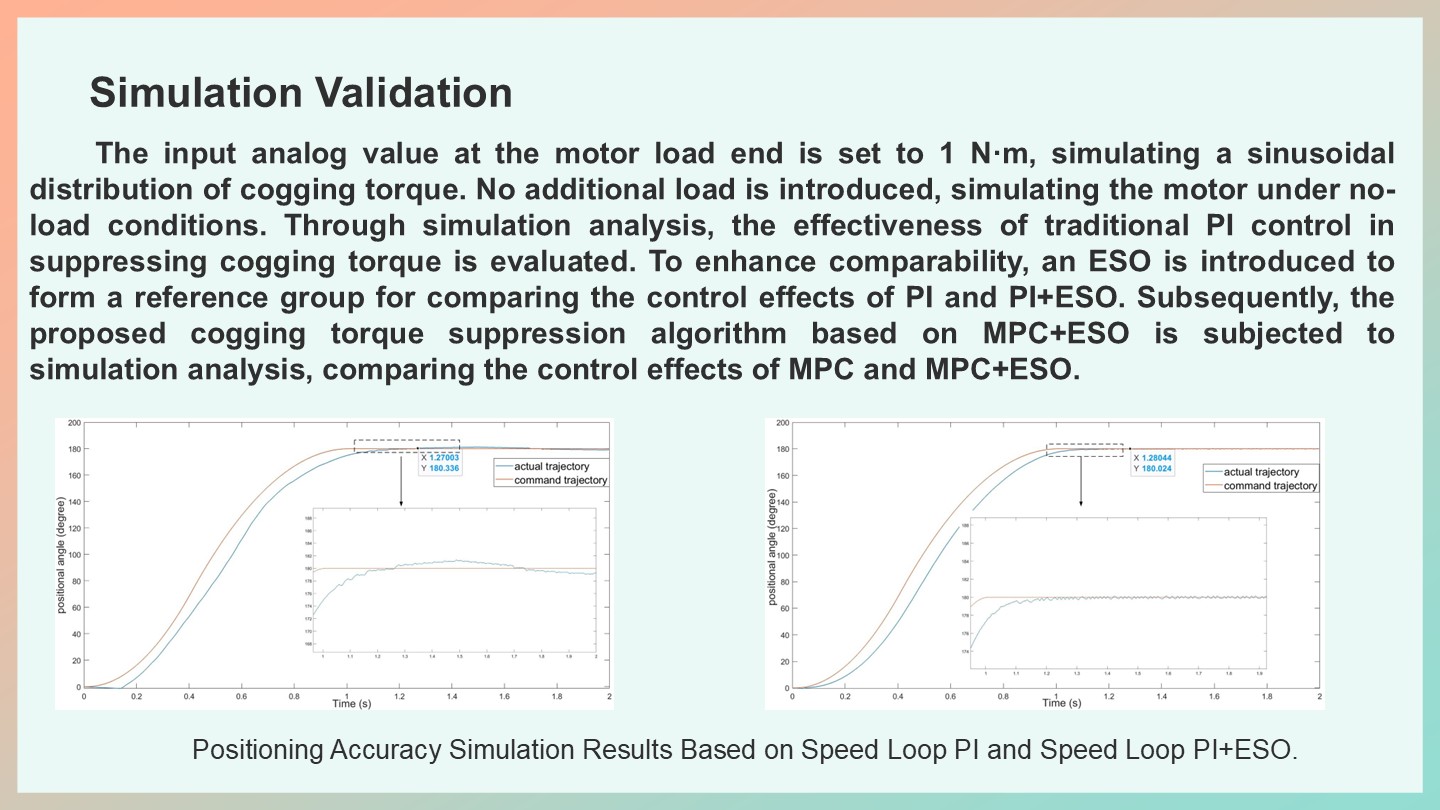 |
The input analog value at the motor load end is set to 1 N·m, simulating a sinusoidal distribution of cogging torque. No additional load is introduced, simulating the motor under no-load conditions. Through simulation analysis, the effectiveness of traditional PI control in suppressing cogging torque is evaluated. To enhance comparability, an ESO is introduced to form a reference group for comparing the control effects of PI and PI+ESO. Subsequently, the proposed cogging torque suppression algorithm based on MPC+ESO is subjected to simulation analysis, comparing the control effects of MPC and MPC+ESO. |
| ICACT20250169 Slide.13
[Big Slide]
[YouTube] |
Chrome Click!! |
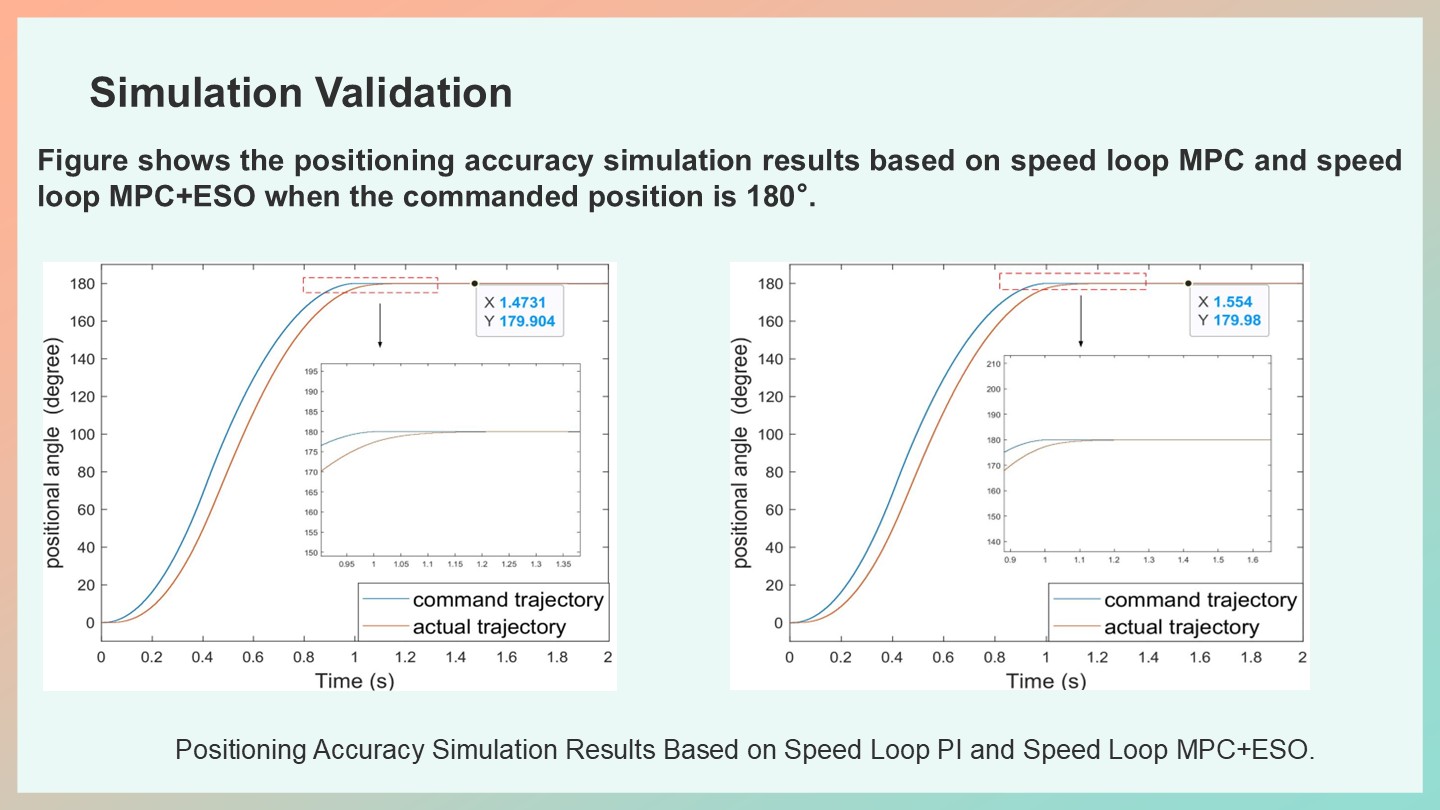 |
Figure shows the positioning accuracy simulation results based on speed loop MPC and speed loop MPC+ESO when the commanded position is 180°.
|
| ICACT20250169 Slide.14
[Big Slide]
[YouTube] |
Chrome Click!! |
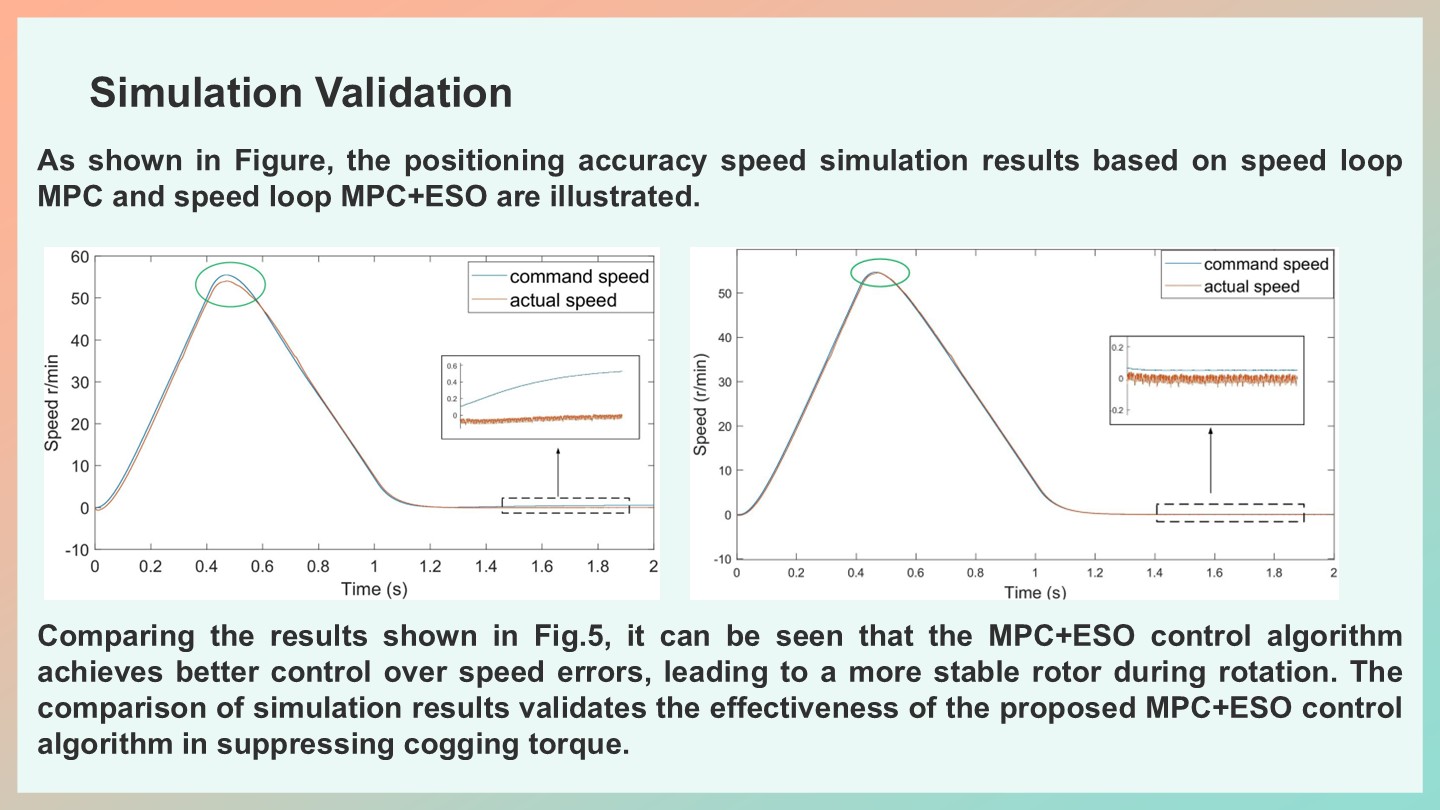 |
As shown in Figure, the positioning accuracy speed simulation results based on speed loop MPC and speed loop MPC+ESO are illustrated.
|
| ICACT20250169 Slide.15
[Big Slide]
[YouTube] |
Chrome Click!! |
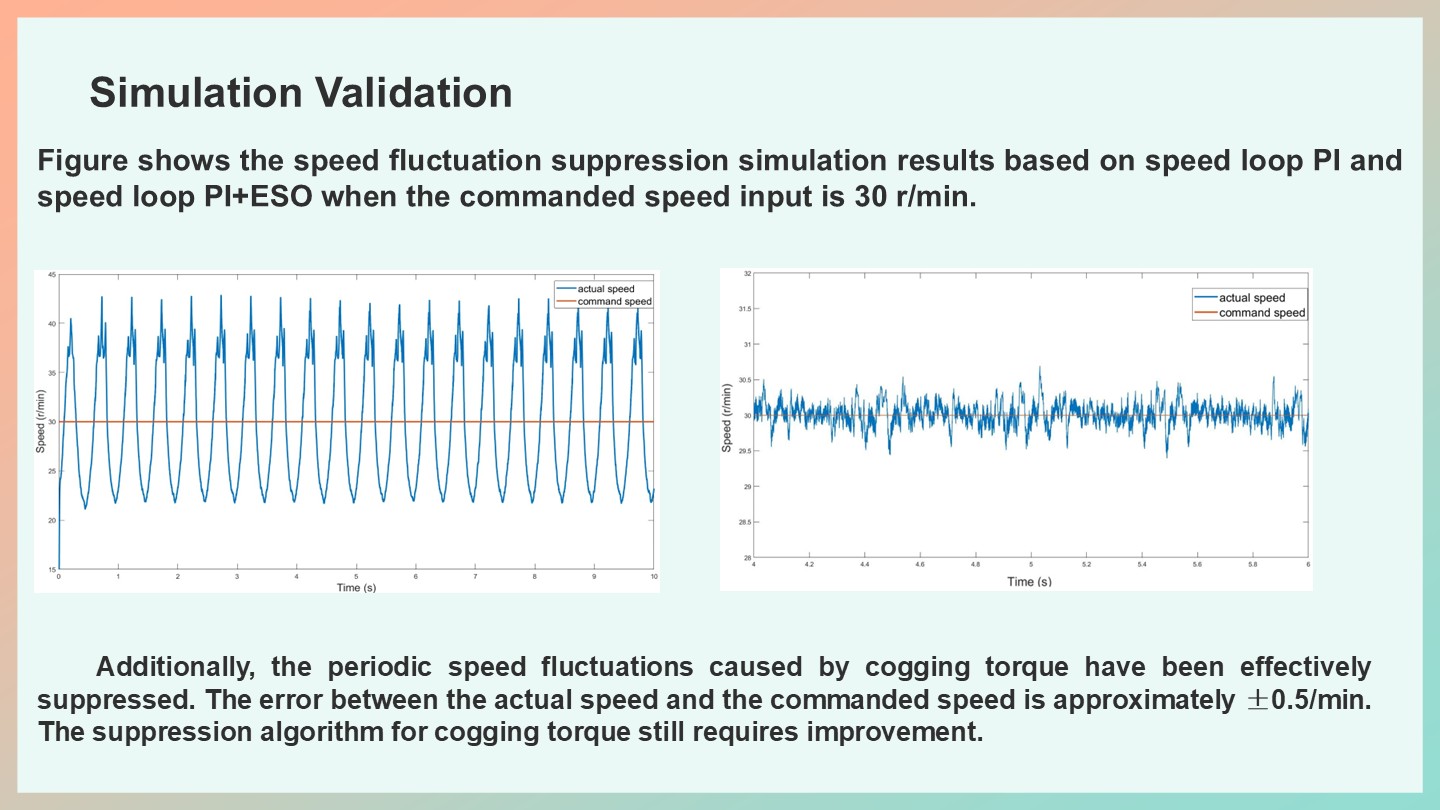 |
Figure shows the speed fluctuation suppression simulation results based on speed loop PI and speed loop PI+ESO when the commanded speed input is 30 r/min.
|
| ICACT20250169 Slide.16
[Big Slide]
[YouTube] |
Chrome Click!! |
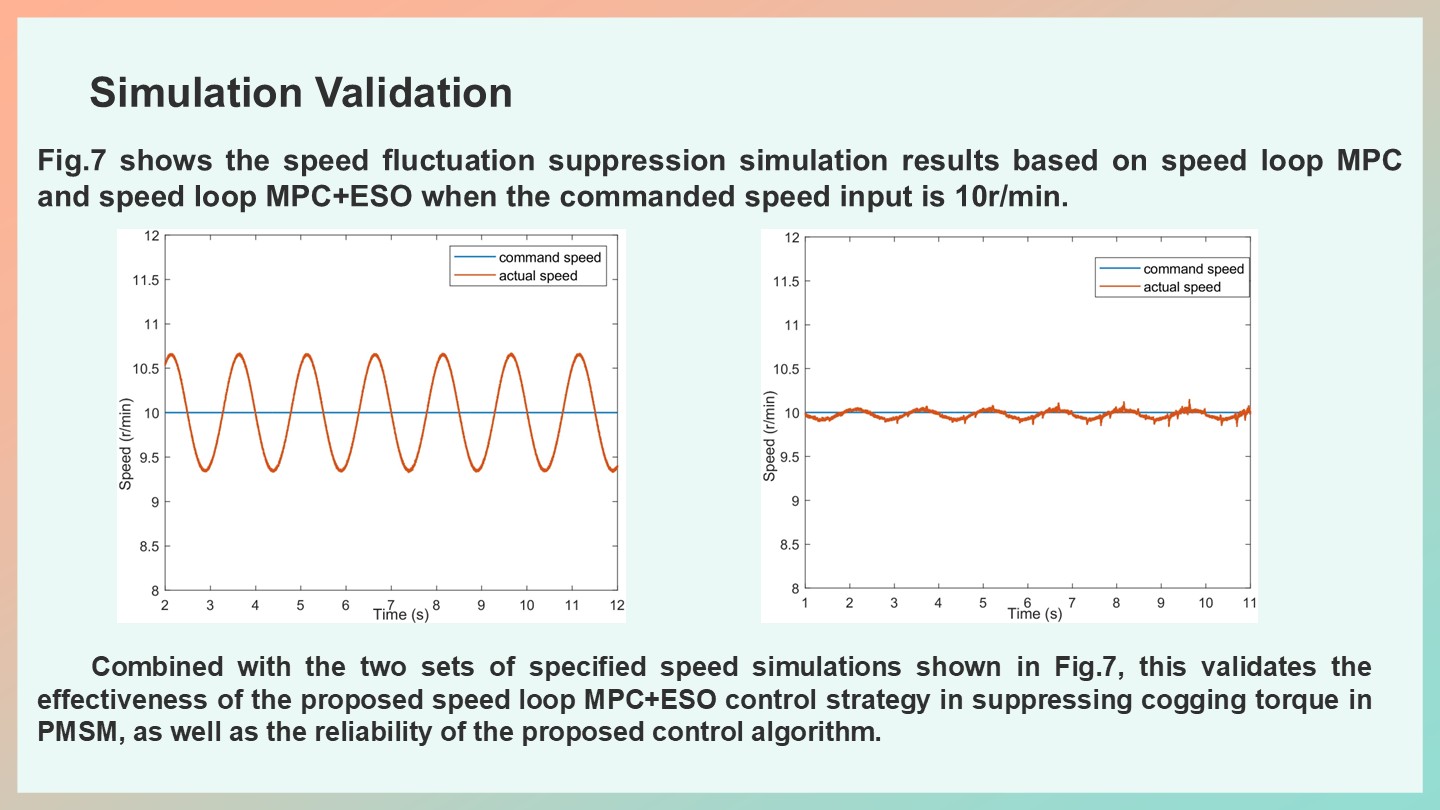 |
Figure shows the speed fluctuation suppression simulation results based on speed loop MPC and speed loop MPC+ESO when the commanded speed input is 10r/min.
|
| ICACT20250169 Slide.17
[Big Slide]
[YouTube] |
Chrome Click!! |
 |
This page presentation introduces the conclusion of this paper.
|
| ICACT20250169 Slide.18
[Big Slide]
[YouTube] |
Chrome Click!! |
 |
This paper addresses the issues of speed fluctuations caused by cogging torque and the positioning accuracy of the motor when operating under low-speed conditions. A control method utilizing speed loop MPC+ESO is proposed to suppress the effects of cogging torque.
|
| ICACT20250169 Slide.19
[Big Slide]
[YouTube] |
Chrome Click!! |
 |
The effectiveness of the proposed control algorithm in suppressing cogging torque is validated through simulation experiments on positioning accuracy and speed ripple suppression on the simulation platform, providing a theoretical basis for subsequent experiments.
|
| ICACT20250169 Slide.20
[Big Slide]
[YouTube] |
Chrome Click!! |
 |
Thank you for listening! |















